Related Experiment Video
Updated: Nov 10, 2025
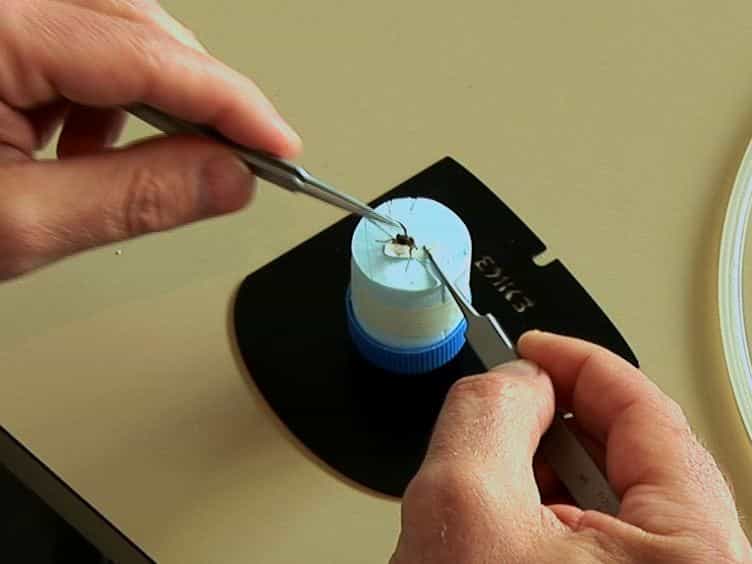

Using Insect Electroantennogram Sensors on Autonomous Robots for Olfactory Searches
Published on: August 4, 2014
A Simulation Framework for the Integration of Artificial Olfaction into Multi-Sensor Mobile Robots
Pepe Ojeda1, Javier Monroy1, Javier Gonzalez-Jimenez1
1Machine Perception and Intelligent Robotics Group, System Engineering and Automation Department, Biomedical Research Institute of Málaga (IBIMA), Campus de Teatinos, University of Málaga, 29071 Málaga, Spain.

Abstract:
The simulation of how a gas disperses in a environment is a necessary asset for the development of olfaction-based autonomous agents. A variety of simulators already exist for this purpose, but none of them allows for a sufficiently convenient integration with other types of sensing (such as vision), which hinders the development of advanced, multi-sensor olfactory robotics applications. In this work, we present a framework for the simulation of gas dispersal and sensing alongside vision by integrating GADEN, a state-of-the-art Gas Dispersion Simulator, with the Unity 3D, a video game development engine that is used in many different areas of research and helps with the creation of visually realistic, complex environments. We discuss the motivation for the development of this tool, describe its characteristics, and present some potential use cases that are based on cutting-edge research in the field of olfactory robotics.
More Related Videos

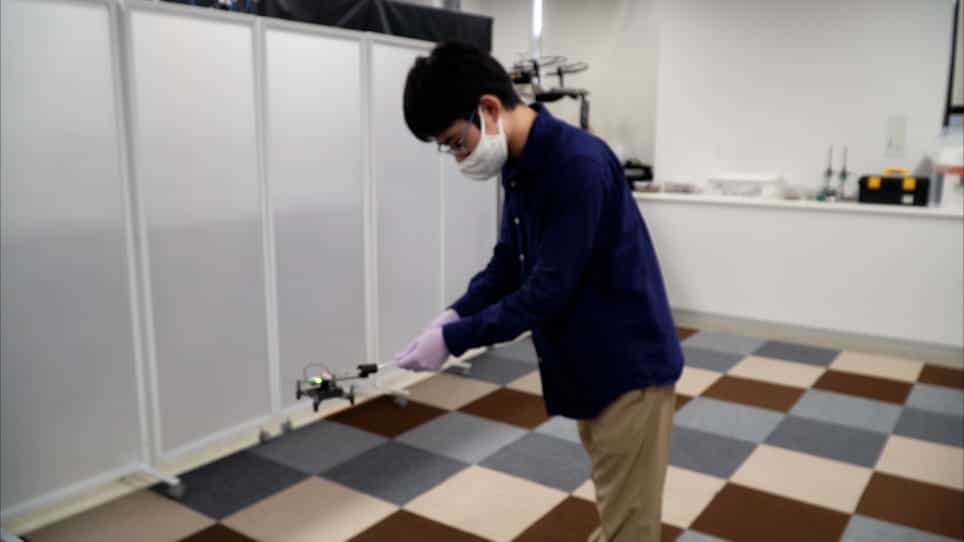
Related Concept Videos
 01:25
Olfaction
The olfactory receptors are embedded in the cilia of the...
 01:20
Physiology of Smell and Olfactory Pathway
The olfactory...