IPR-based distributed interval observers design for uncertain LTI systems
Related Experiment Video
Updated: Nov 9, 2025
Image-based Lagrangian Particle Tracking in Bed-load Experiments
Published on: July 20, 2017
Danxia Li1, Jing Chang1, Weisheng Chen1
1School of Aerospace Science and Technology, Xidian University, Xi'an 710071, China.

Abstract:
This paper designs a novel distributed interval observer for Linear Time Invariant (LTI) systems with additive disturbances. The technique of observer construction relies on the Internal Positive Representations (IPRs) of systems and synchronizing region approach, which ensures that the error system is stably and positive. Each observer estimates the upper and lower bounds (ULBs) of the system states by only using part of the output information and the information interaction with their neighbors. Numerical examples are simulated to demonstrate the effectiveness of the proposed approach.
More Related Videos
Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:03
Prediction Intervals
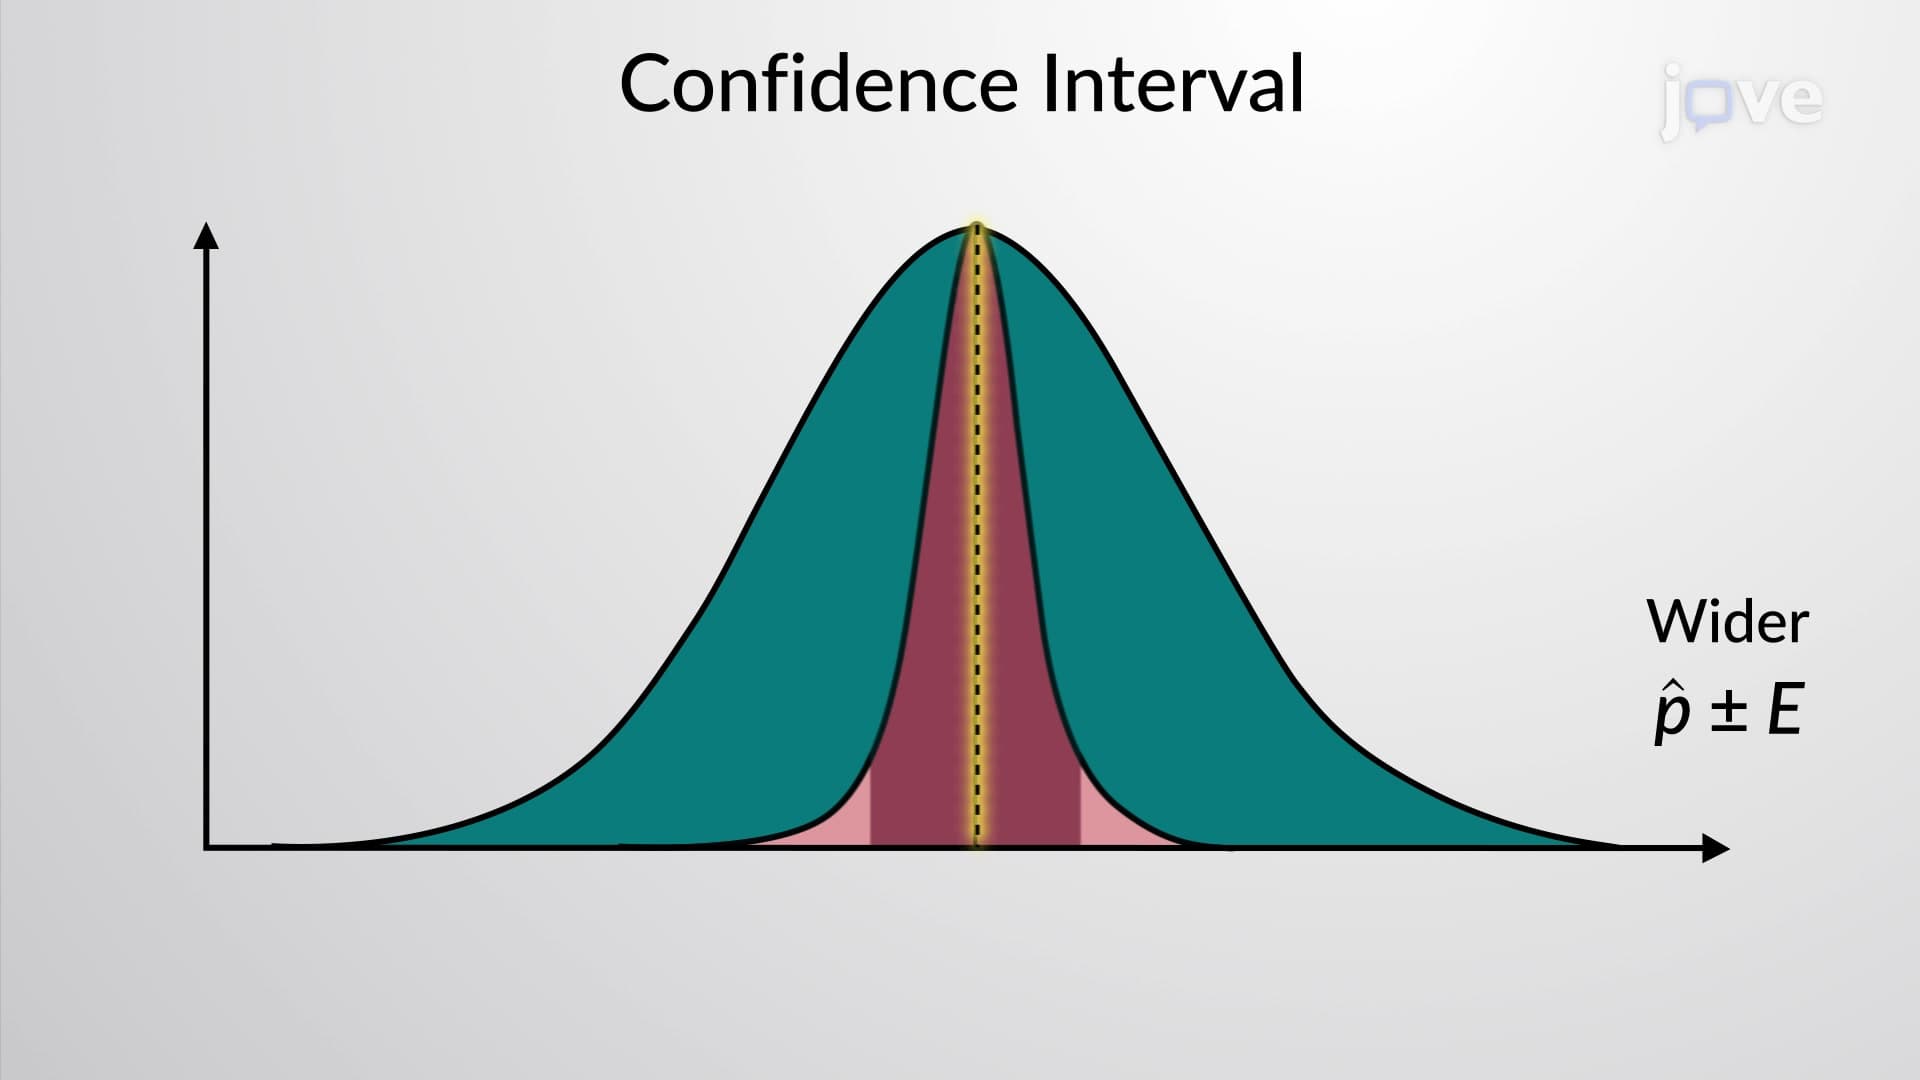
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
 01:21
Confidence Intervals
A...
 01:28
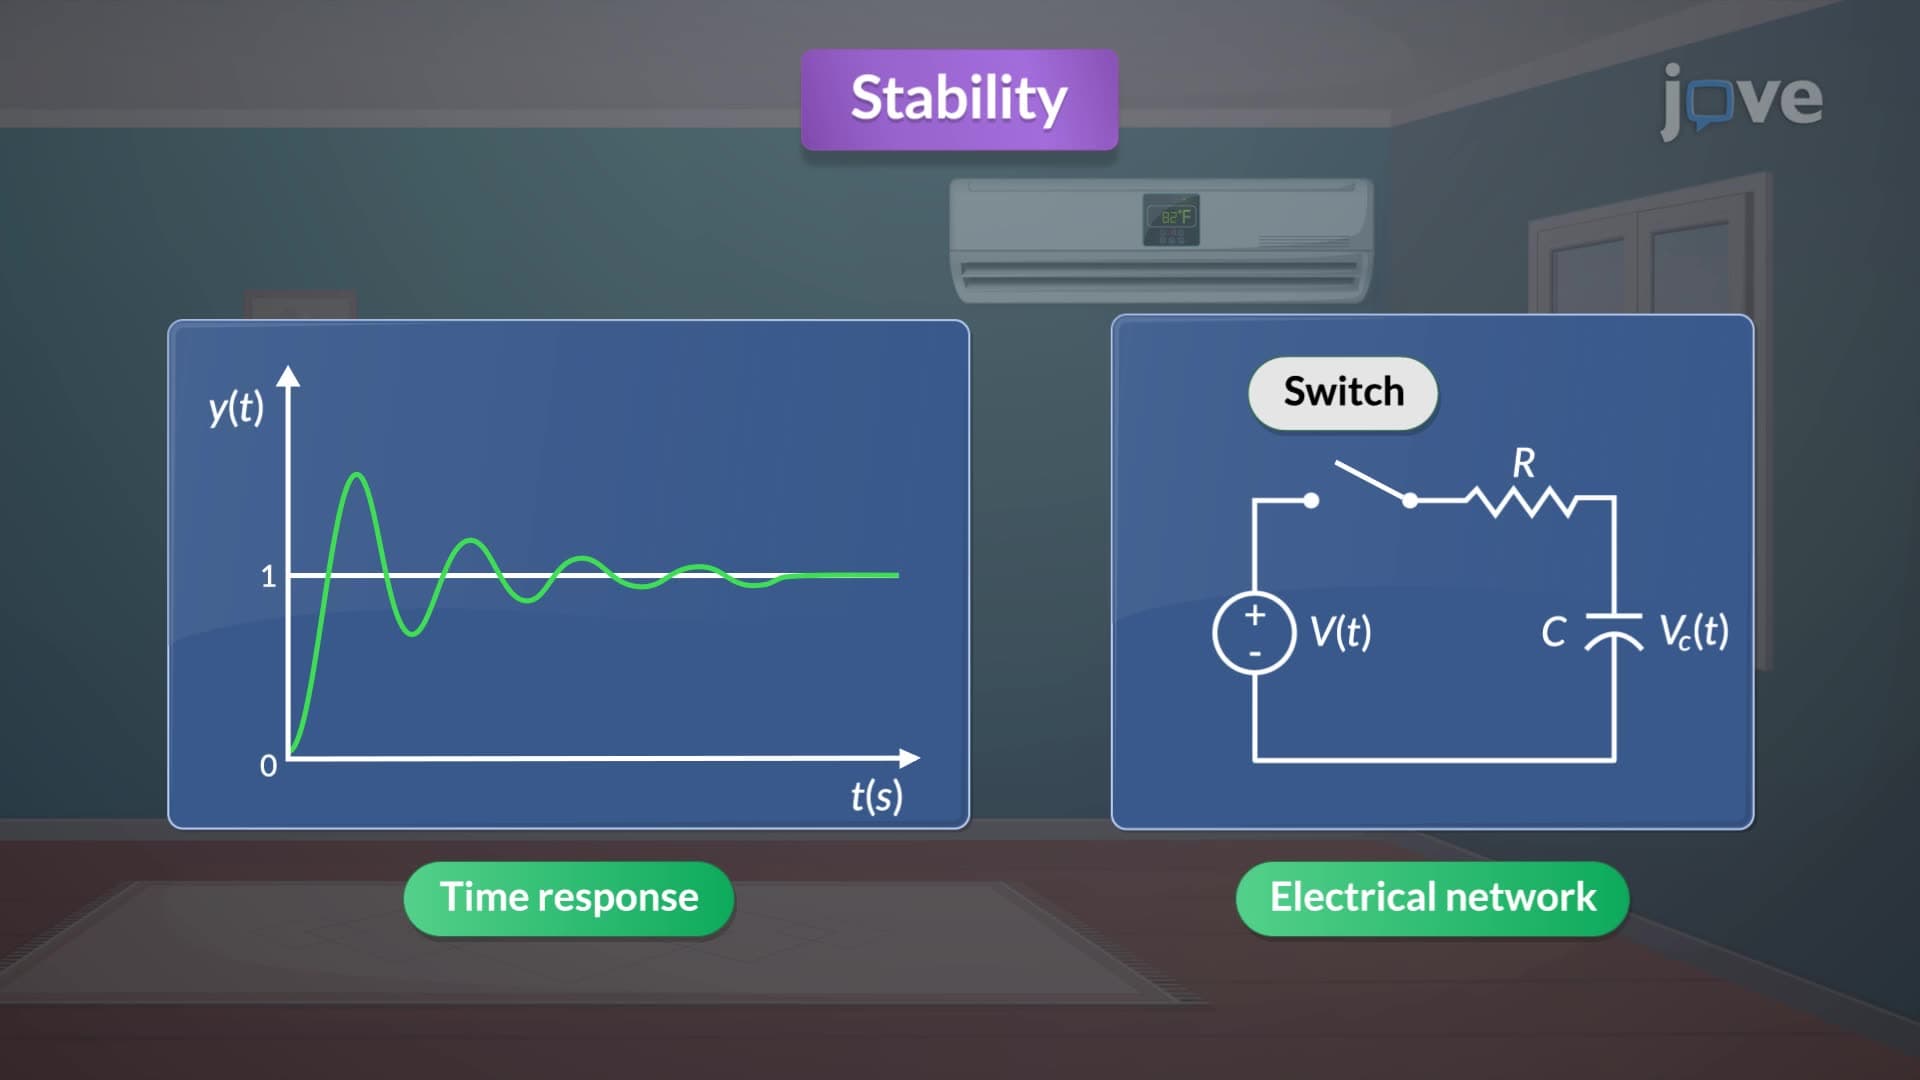
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:21
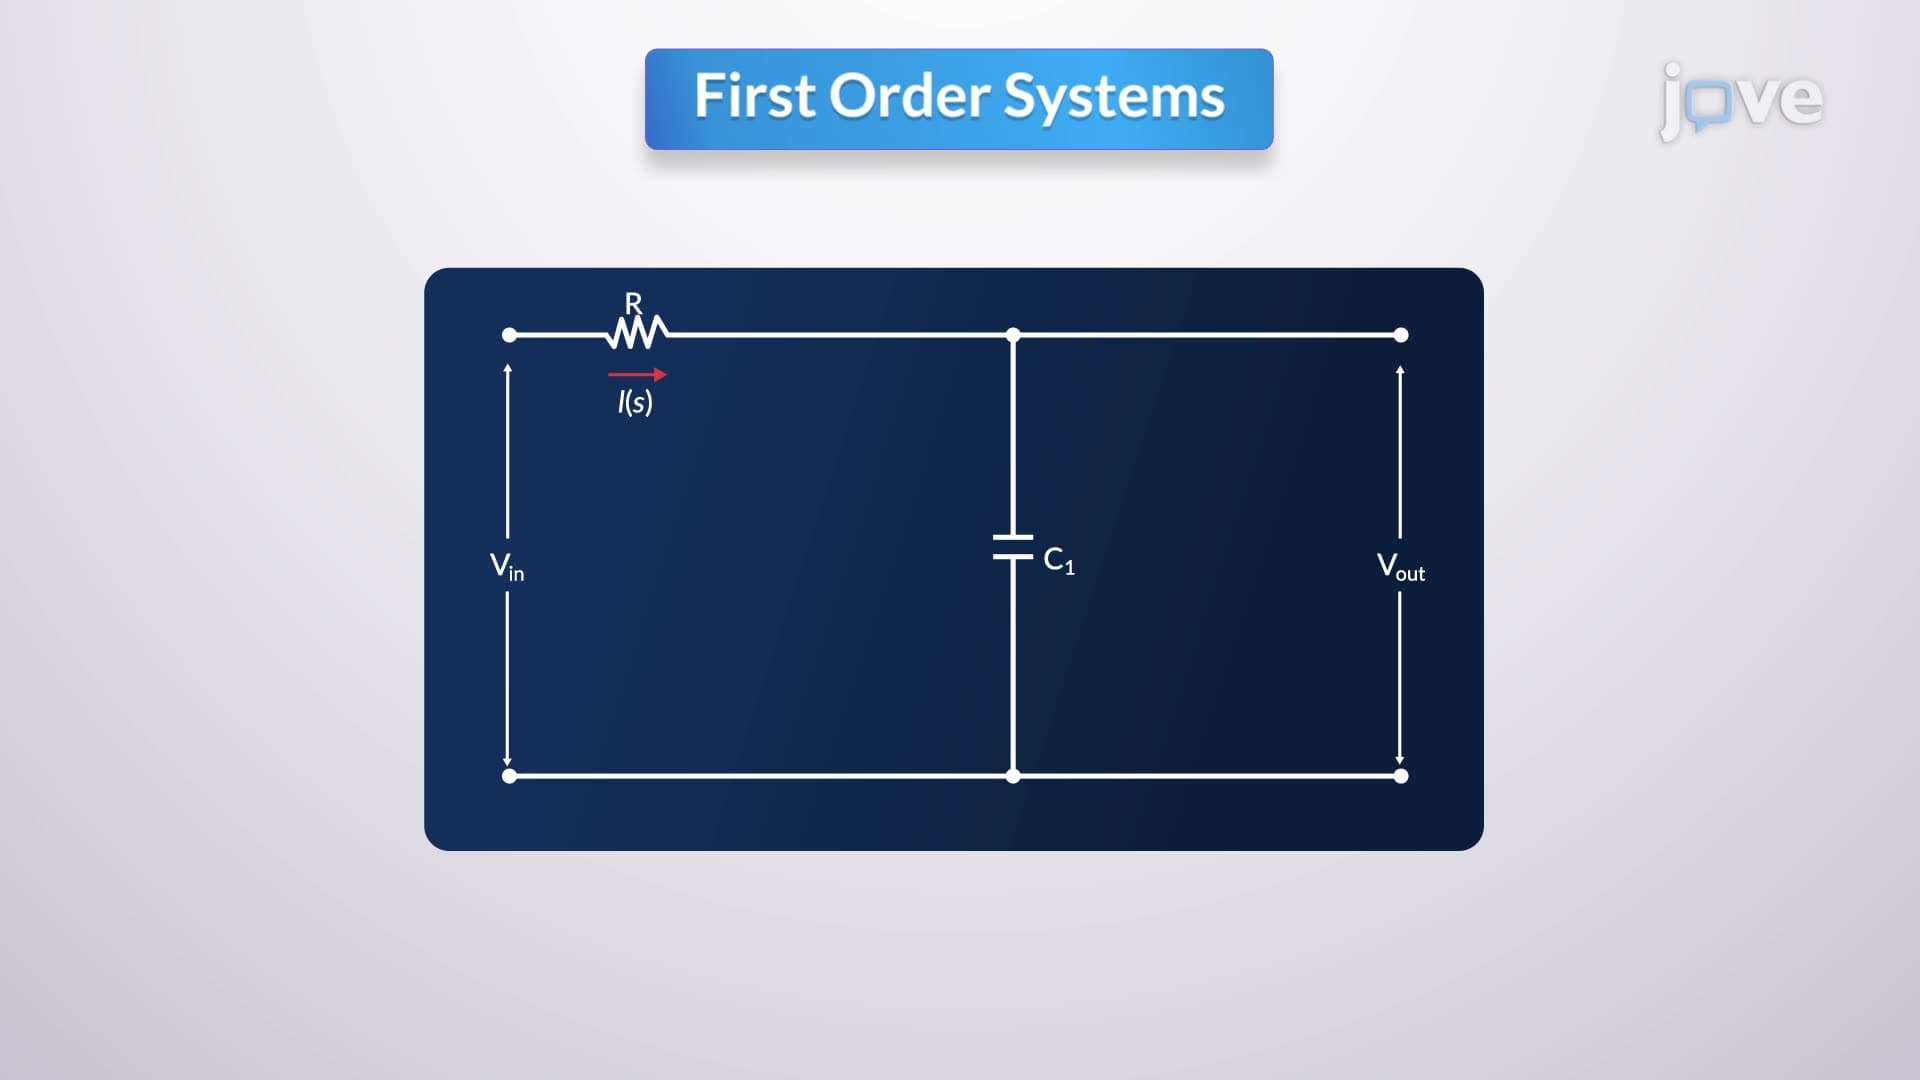
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...