A Recurrent Neural-Network-Based Real-Time Dynamic Model for Soft Continuum Manipulators
Related Experiment Video
Updated: Nov 8, 2025
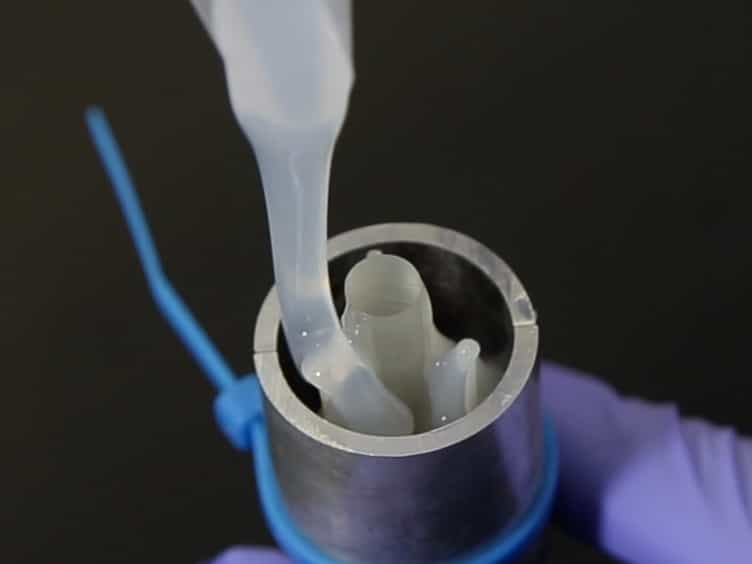
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Abbas Tariverdi1, Venkatasubramanian Kalpathy Venkiteswaran2, Michiel Richter2
1Department of Physics, University of Oslo, Oslo, Norway.

Abstract:
This paper introduces and validates a real-time dynamic predictive model based on a neural network approach for soft continuum manipulators. The presented model provides a real-time prediction framework using neural-network-based strategies and continuum mechanics principles. A time-space integration scheme is employed to discretize the continuous dynamics and decouple the dynamic equations for translation and rotation for each node of a soft continuum manipulator. Then the resulting architecture is used to develop distributed prediction algorithms using recurrent neural networks. The proposed RNN-based parallel predictive scheme does not rely on computationally intensive algorithms; therefore, it is useful in real-time applications. Furthermore, simulations are shown to illustrate the approach performance on soft continuum elastica, and the approach is also validated through an experiment on a magnetically-actuated soft continuum manipulator. The results demonstrate that the presented model can outperform classical modeling approaches such as the Cosserat rod model while also shows possibilities for being used in practice.
Related Concept Videos
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:18
Neural Control of Respiration
Respiratory Centers in the Brainstem
Two primary areas comprise the respiratory center: the medullary respiratory center in the medulla oblongata and the pontine respiratory group in the pons. The...