Optimal sliding mode control for cutting tasks of quick-return mechanisms
Related Experiment Video
Updated: Nov 7, 2025
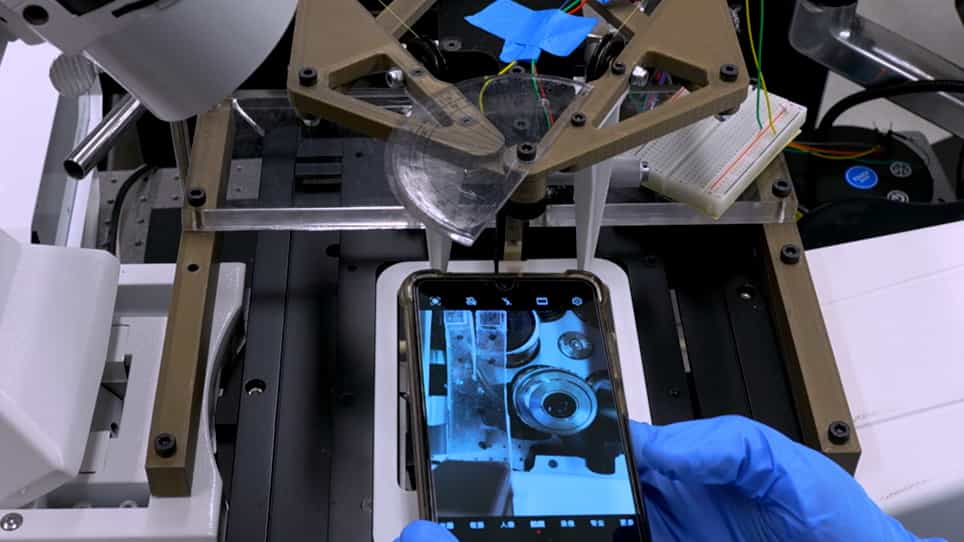
Performing Microscope-Mounted Y-Shaped Cutting Tests
Published on: January 20, 2023
Adolfo Perrusquía1, Juan Alejandro Flores-Campos2, Wen Yu3
1School of Aerospace, Transport and Manufacturing, Cranfield University, Bedford MK43 0AL, UK.

Abstract:
A solution of the constant cutting velocity problem of quick-return mechanisms is the main concern of this paper. An optimal sliding mode control in the task space is used to achieve uniform and accurate cuts throughout the workpiece. The switching hyperplane is designed to minimize the position error of the slider-dynamics in an infinite horizon. A Jacobian compensator is used to exploit the mechanical advantage and ensure controllability. The velocity profile is constructed in terms of the mechanism and workpiece geometric properties. Stability of the closed-loop dynamics is verified with the Lyapunov stability theory. Experiments are carried out in a quick-return mechanism prototype to validate the proposal.


Related Concept Videos
 01:14
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
 01:10
Relative Motion Analysis - Acceleration
 01:24
Wedges
Consider using a wedge to lift a heavy slab. Here, the wedge functions by converting the applied force into a much larger force directed almost perpendicular to the initial force. This...
 01:05
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:11
Design Example: Forces in Sluice Gate
Key variables in...
 01:21
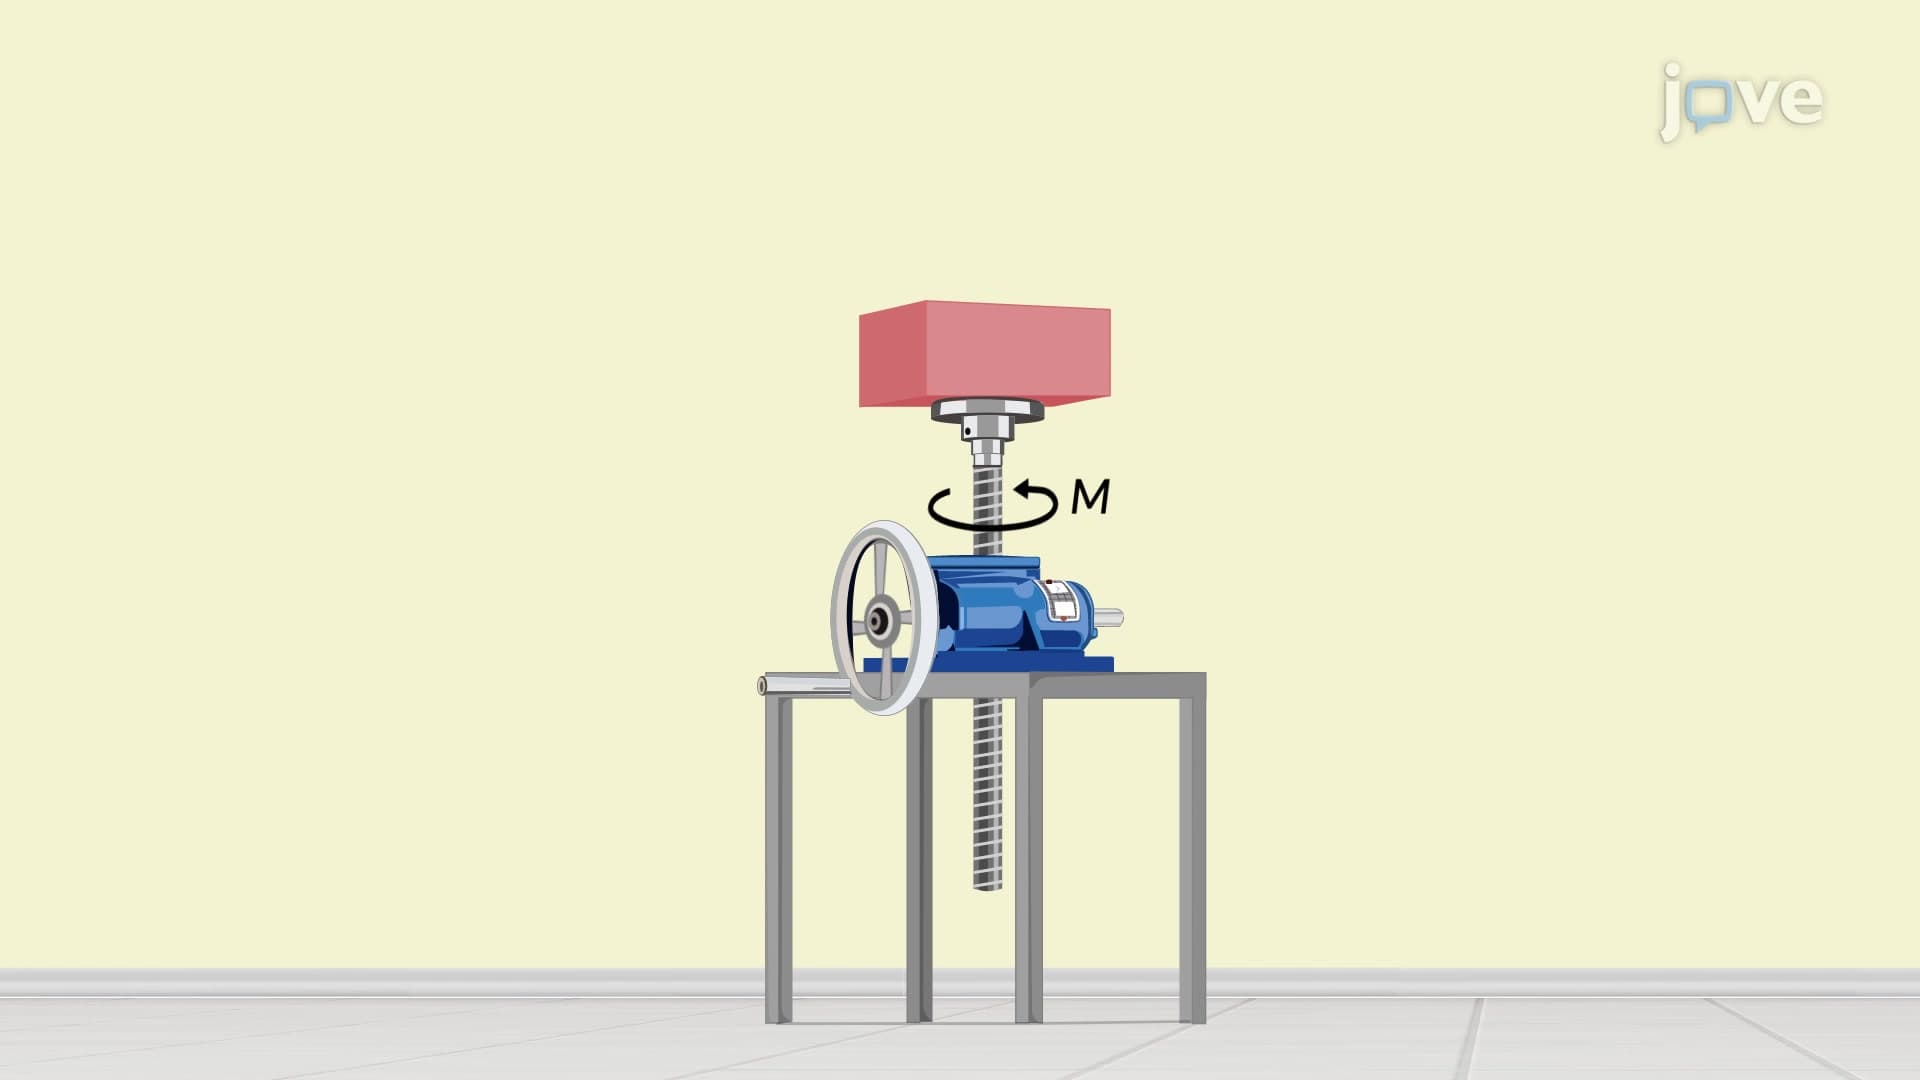
Upward Impending Motion
To better comprehend how a screw jack functions, consider the completely unraveled thread as a block in contact with the...