Related Experiment Video
Updated: Oct 29, 2025

Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Active disturbance rejection control design for high-order integral systems
Zhenlong Wu1, Gengjin Shi2, Donghai Li2
1School of Electrical Engineering, Zhengzhou University, Zhengzhou 450001, China.

Abstract:
Active disturbance rejection control (ADRC) is designed for regular processes frequently, due to its strong ability to reject disturbances and handle system uncertainties. However, ADRC design for high-order integral systems existing in many natural systems is always ignored. The controller design for high-order integral systems is different from the regular systems due to no pole in the left and right half s-planes. The ADRC design for high-order integral systems is studied to explain this question theoretically in this paper. Based on the equivalent form of ADRC, a theorem about the necessary condition of ADRC is proven which can guarantee the closed-loop system's stability. Additionally, the advantages of ADRC over proportional-integral-derivative (PID) controller in sensor noise rejection and control signal variation are analyzed theoretically. In order to achieve expected control performance for high-order integral systems, a practical design procedure of ADRC is summarized by the single variable method. Several comparative simulations and an experiment based on a ball and beam system are carried out. Running data verify that ADRC can obtain better control performance with strong robustness than PID controller. Eventually, a 100th order ADRC is designed for a 100th order integral system, and simulation results show that ADRC can be designed for high-order integral systems conveniently. Based on theoretical analyses and experimental verifications, ADRC shows some advantages for high-order integral systems.
More Related Videos
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:24
PI Controller: Design
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:21
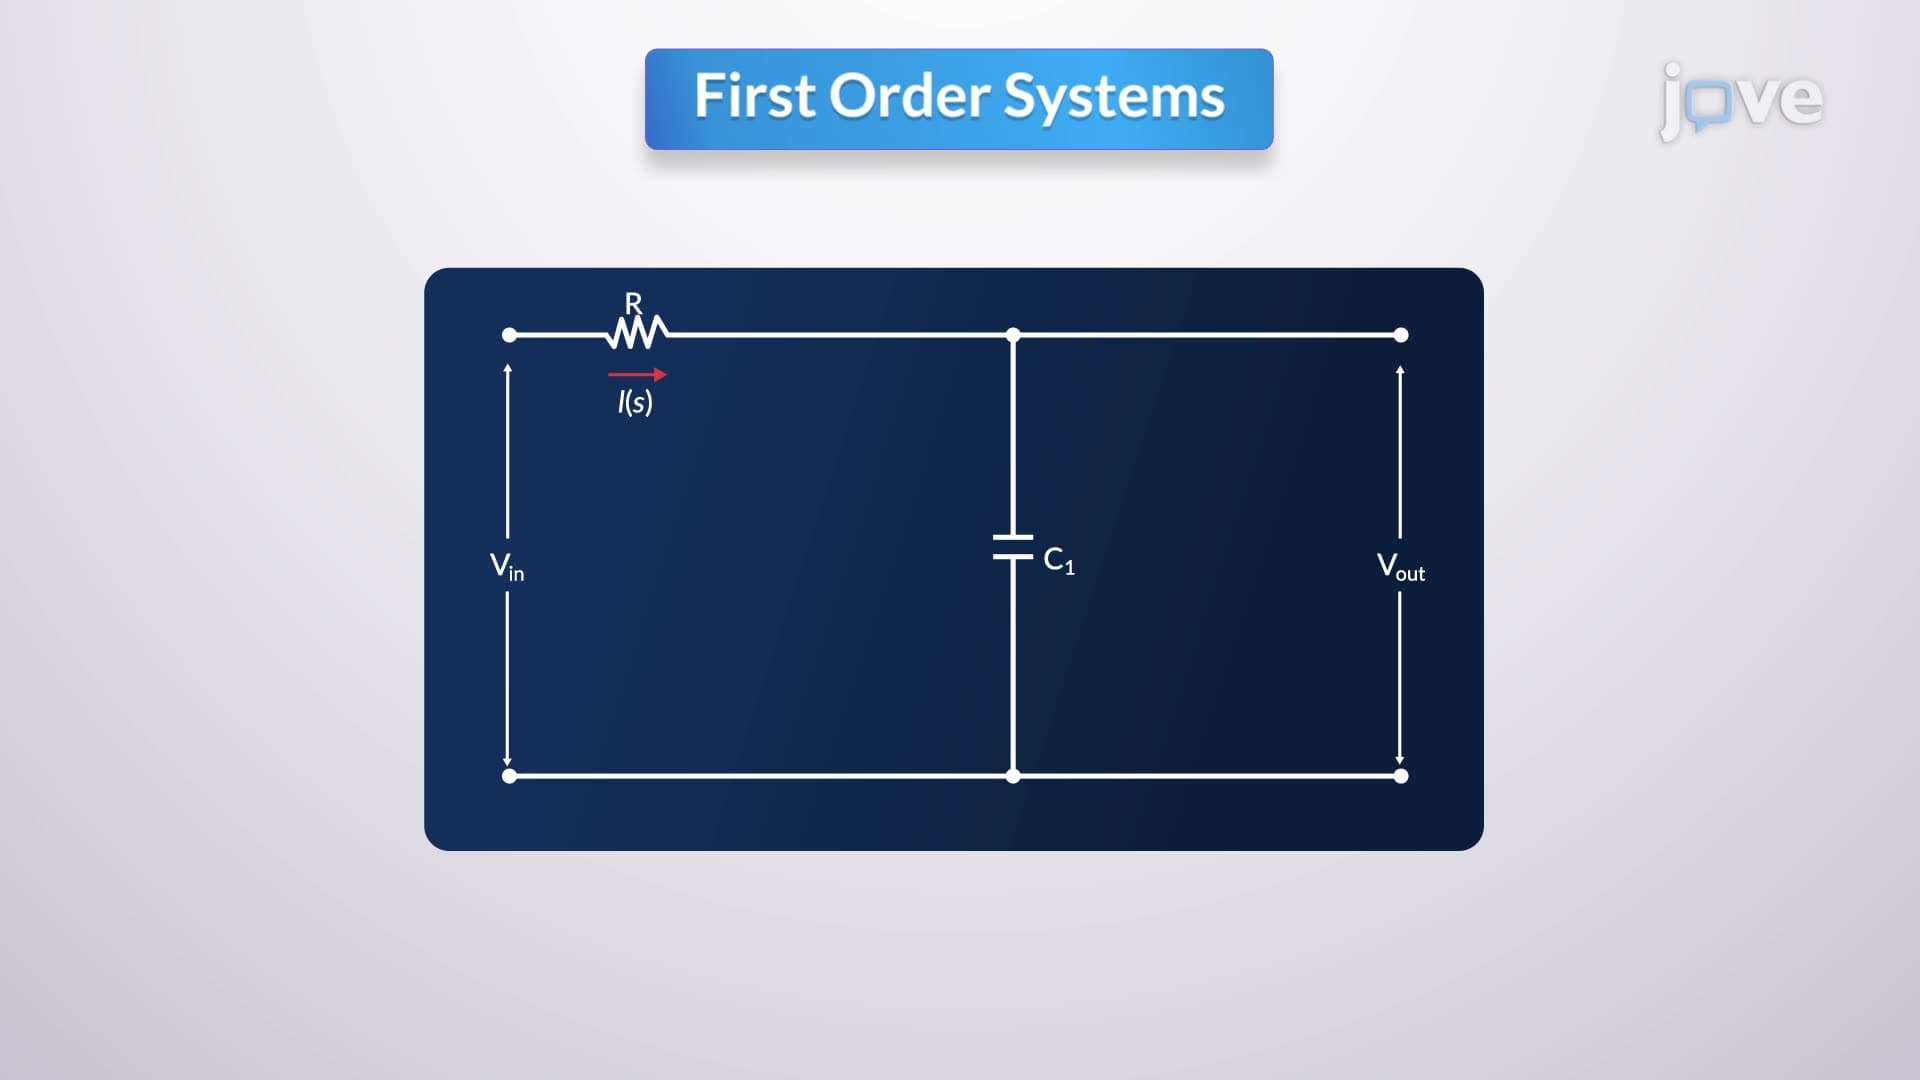
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:18
Second Order systems II
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...