Related Experiment Video
Updated: Oct 22, 2025
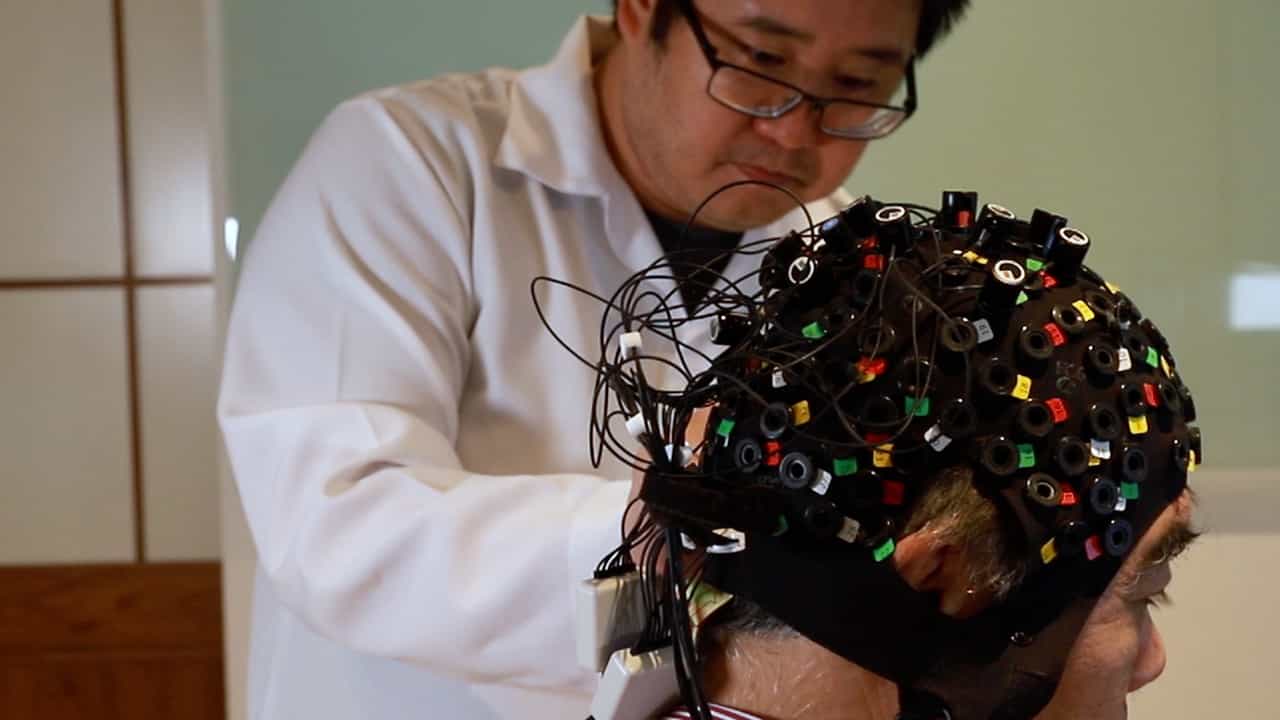

Author Spotlight: Assessing Brain Activity in Robotic-Assisted Lower Limb Rehabilitation Using fNIRS
Published on: June 7, 2024
A Flexible Multimodal Sole Sensor for Legged Robot Sensing Complex Ground Information during Locomotion
Yingtian Xu1, Ziya Wang1, Wanjun Hao1
1Shenzhen Institute of Artificial Intelligence and Robotics for Society (AIRS), Shenzhen 518129, China.

Abstract:
Recent achievements in the field of computer vision, reinforcement learning, and locomotion control have largely extended legged robots' maneuverability in complex natural environments. However, little research focuses on sensing and analyzing the physical properties of the ground, which is crucial to robots' locomotion during their interaction with highly irregular profiles, deformable terrains, and slippery surfaces. A biomimetic, flexible, multimodal sole sensor (FMSS) designed for legged robots to identify the ontological status and ground information, such as reaction force mapping, contact situation, terrain, and texture information, to achieve agile maneuvers was innovatively presented in this paper. The FMSS is flexible and large-loaded (20 Pa-800 kPa), designed by integrating a triboelectric sensing coat, embedded piezoelectric sensor, and piezoresistive sensor array. To evaluate the effectiveness and adaptability in different environments, the multimodal sensor was mounted on one of the quadruped robot's feet and one of the human feet then traversed through different environments in real-world tests. The experiment's results demonstrated that the FMSS could recognize terrain, texture, hardness, and contact conditions during locomotion effectively and retrain its sensitivity (0.66 kPa-1), robustness, and compliance. The presented work indicates the FMSS's potential to extend the feasibility and dexterity of tactile perception for state estimation and complex scenario detection.


Related Concept Videos
 01:28
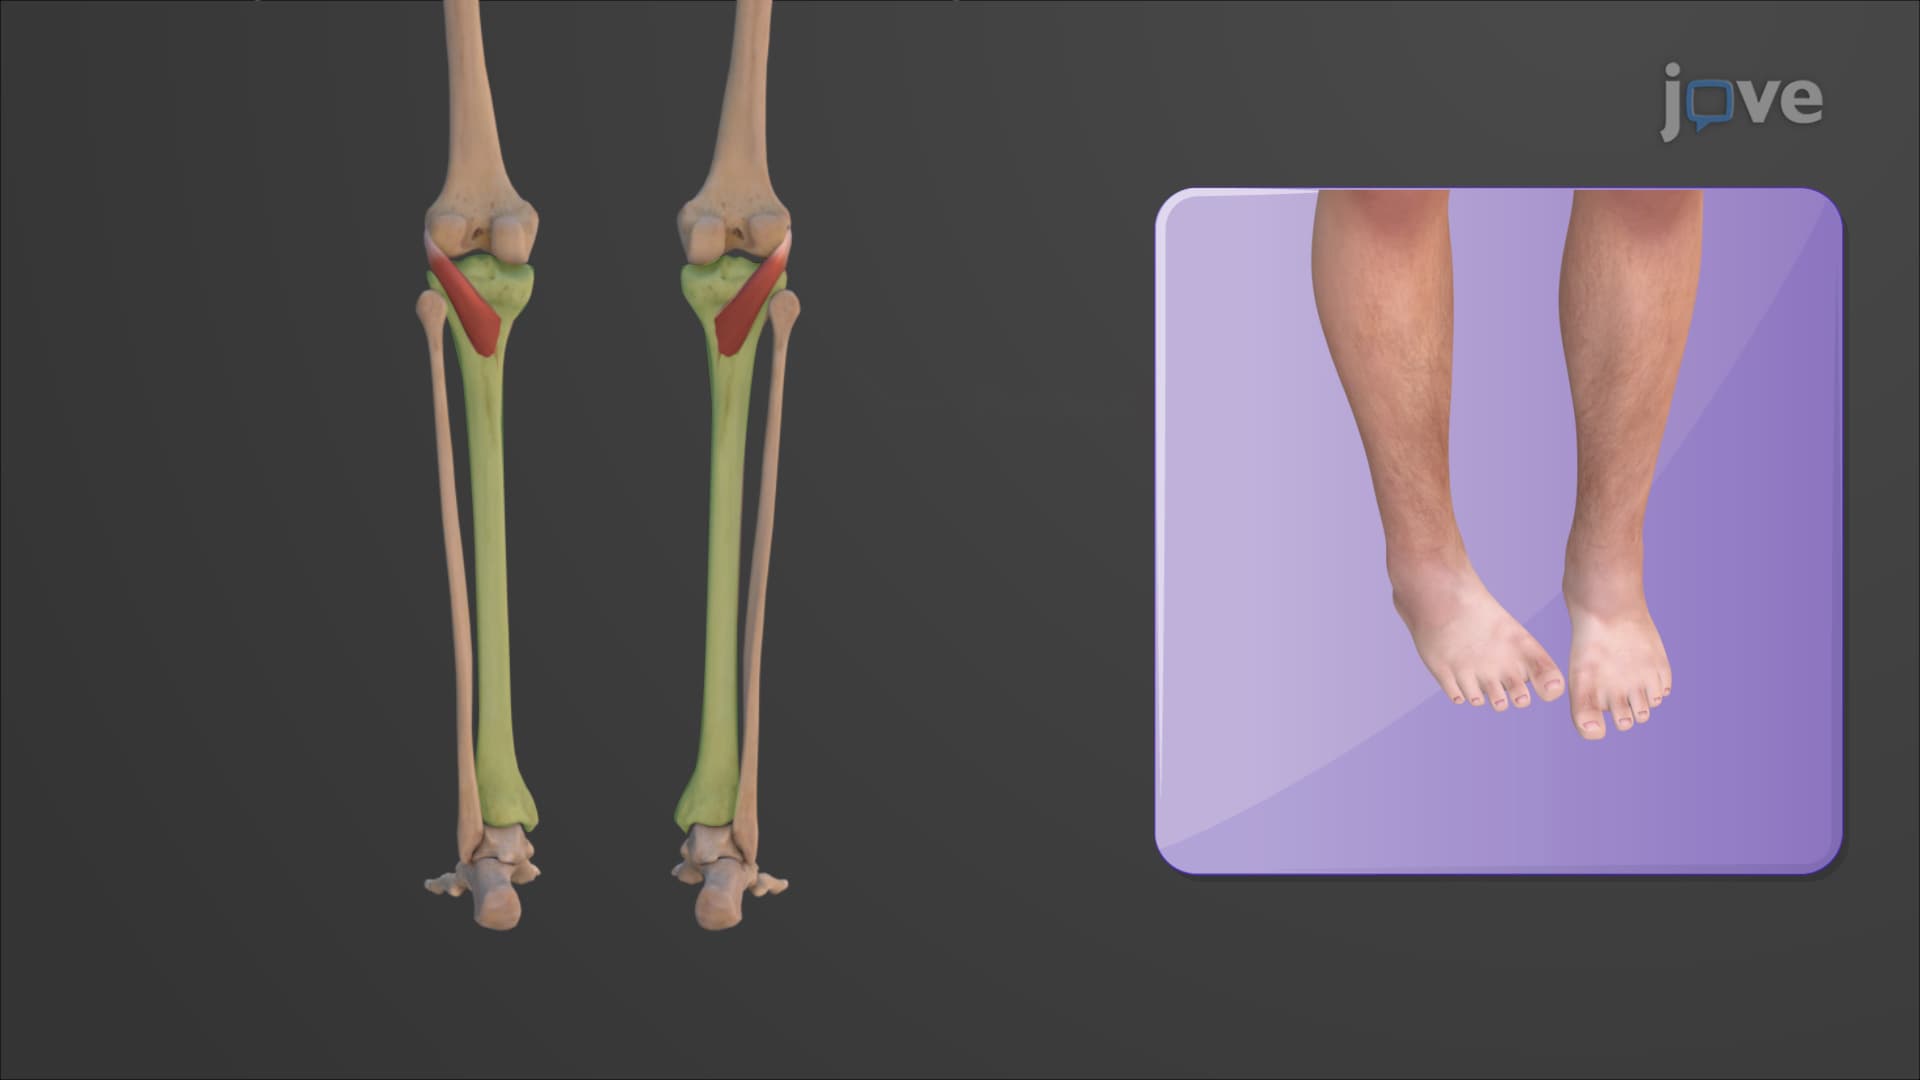
Muscles of the Leg that Move the Foot and Toes
Anterior Compartment
The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles....
 01:23
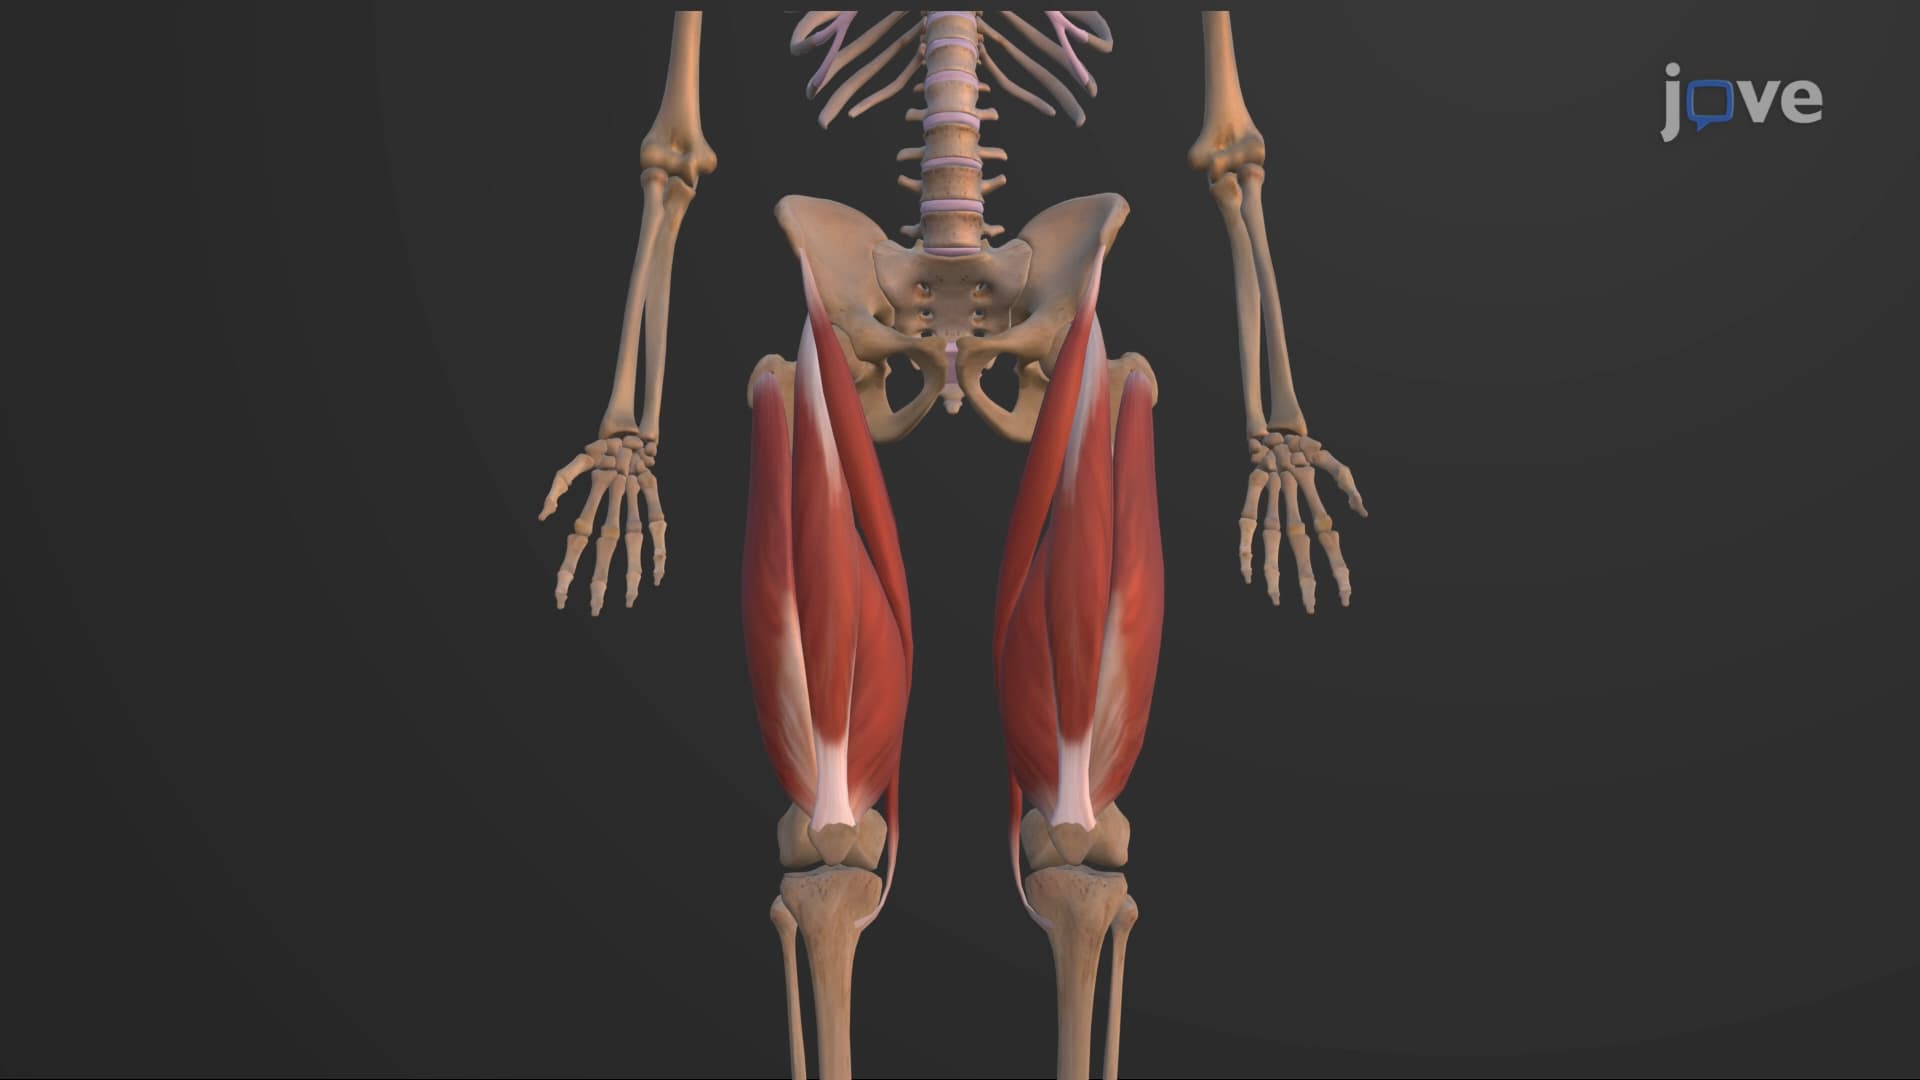
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...