Related Experiment Video
Updated: Oct 21, 2025
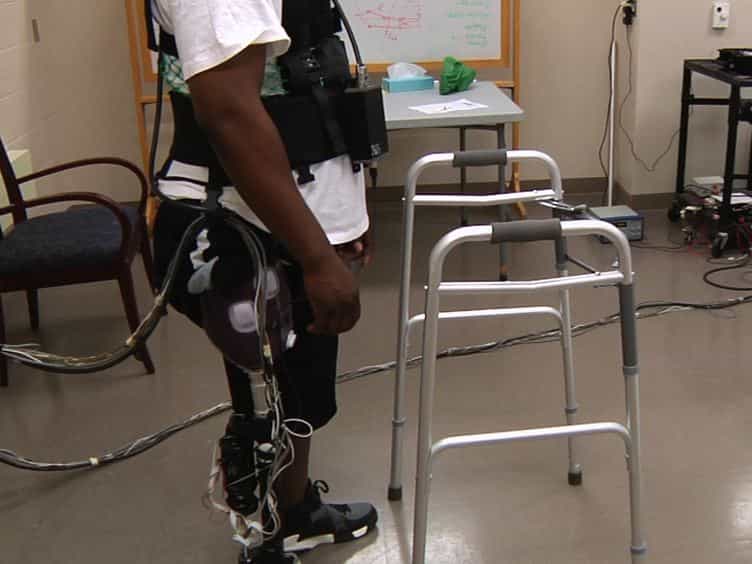
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Designing a robust controller for a lower limb exoskeleton to treat an individual with crouch gait pattern in the
Maryam Khamar1, Mehdi Edrisi1, Saeed Forghany2
1Electrical Department, Faculty of Engineering, University of Isfahan, Iran.

Abstract:
Crouch gait is a gait anomaly observed in youngsters with cerebral palsy (CP). Rehabilitation robots are useful for treating individuals with crouch gait. Multiple factors have impact on crouch, including contracture, spasticity, weak motor control, and muscle feebleness, which make the designing and controlling of these exoskeletons for this population a challenging job. A harsh kinematic trajectory enforced by an exoskeleton control strategy may place individuals with spasticity at a high risk of muscle tissue injury. Therefore, in this article, a multi-input multi-output (MIMO) control method is proposed to reduce this risk and improve crouch gait pattern. A constrained control law is used in the model since high power demands may threaten the wearer. In addition, the controller needs to be robust enough against external disturbances and uncertainties. Thus, a nonlinear disturbance observer (NDO) is presented to compute the wearer-generated muscular torque and the uncertainties in the modeling. In addition, a robust constrained MIMO backstepping sliding controller (CMBSC) based on NDO is used to deal with the effect of actuator saturation and uncertainties. A simulation test was used to validate the proposed model and controller. The results of Simulation confirmed the efficiency of the proposed control method when applied to crouch gait with subject specific gait reference. Then, some experimental tests were undertaken to validate the efficiency of the proposed controller.

Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...