Linear-based gain-determining method for adaptive backstepping controller
Related Experiment Video
Updated: Oct 21, 2025

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Zhengqi Wang1, Xiaoping Liu1, Wilson Wang2
1Department of Electrical and Computer Engineering, Lakehead University, 955 Oliver Rd, Thunder Bay, Ontario, Canada, P7B 5E1.

Abstract:
This paper presents a linear-based gain-determining method for nonlinear adaptive backstepping controllers. Usually, the gains for nonlinear controllers are tuned by the trial and error method. This method becomes more difficult as the number of gains increases. A user-friendly method is proposed in this work to deal with the problem. Firstly, a linear auxiliary system is formed by separating the linear parts from the nonlinear system. Then, linear state-space techniques are used to determine the gains for state-feedback by the linear auxiliary system. After that, by converting the state-feedback gains to backstepping gains, the gains of the nonlinear backstepping controller can be determined. The proficiency of the gain-determining method is proved by simulations with two linear techniques.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:24
PI Controller: Design
 01:19
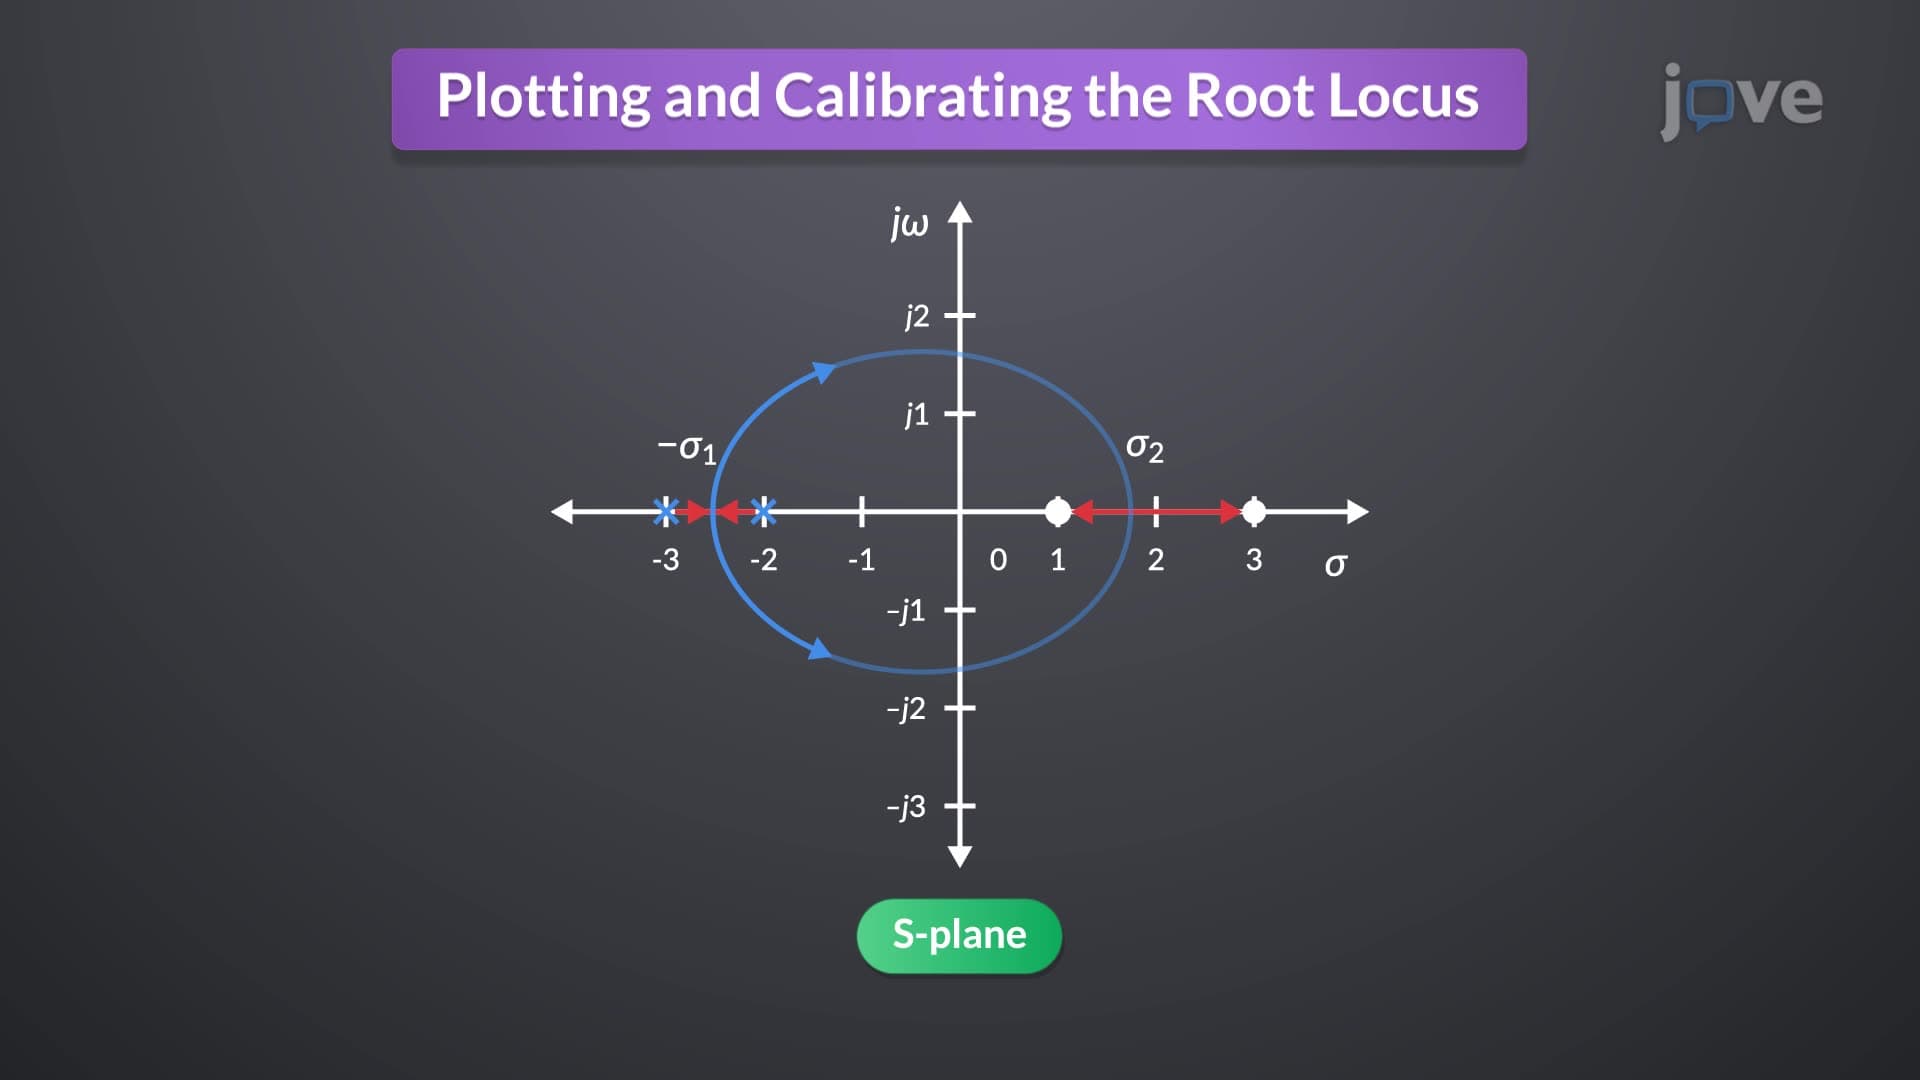
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
 01:22
Phase-lead and Phase-lag Controllers
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...