Related Experiment Video
Updated: Oct 19, 2025
Design and Optimization Strategies of a High-Performance Vented Box
Published on: June 9, 2023
Analysis of Acceleration Structure Parameters and Hybrid Autotuning for Ray Tracing

Abstract:
Finding optimal parameters for acceleration structures for raytracing is key to improved performance. Previous research has shown that a speedup of over 10% of rendering time is possible. Some parameters are interdependent which complicates the process of finding an optimal configuration. It is hence interesting to find them efficiently. Autotuning is an automatic optimization scheme able to search for optimal configurations and has been applied successfully to kD-trees in the past, which we apply today on BVHs. The more parameters to optimize, the more difficult it is to find optimal solutions. In this article, we analyze in detail the behavior of the parameters and their impact on acceleration structure building and rendering time. We show the interdependence and context sensitivity (i.e., scene, viewpoint) of the parameters. Based on the use case, this allows to target only crucial parameters. Convergence speed towards an optimal configuration is essential. To find better parameters, the autotuner needs to build the acceleration structure over and over, changing parameters every time. We introduce a hybrid model-based prediction and online autotuning method to address this issue. The prediction model allows for both instantaneous near-optimal configurations when inputs are known or similar, and efficient search of the configuration space when inputs are completely new. Online autotuning outperforms configurations recommended in literature by up to 11% median. The prediction model achieves 95% of the maximum speedup of the autotuner while reducing 90% of its overhead. Thus, hybrid online autonuning enables always-on tuning in ray tracing.
Related Concept Videos
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:10
Relative Motion Analysis - Acceleration
 01:27
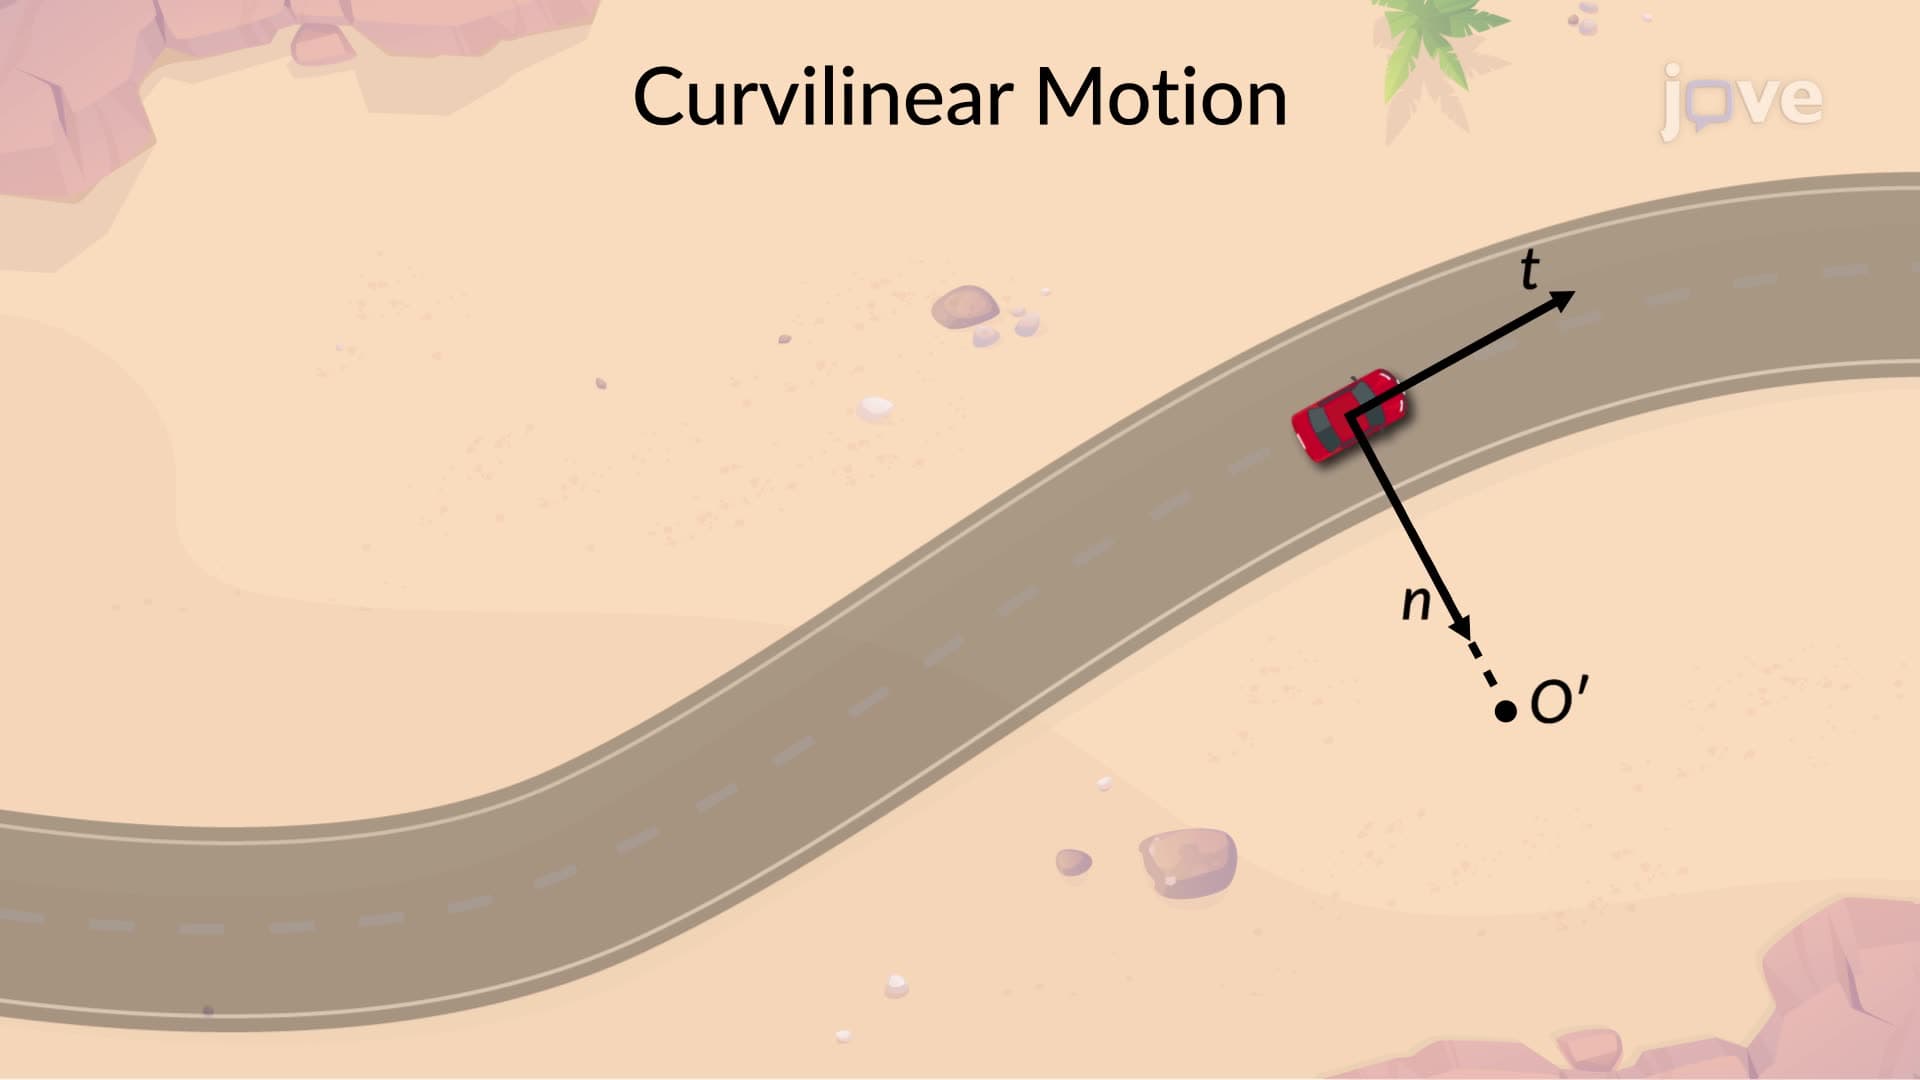
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
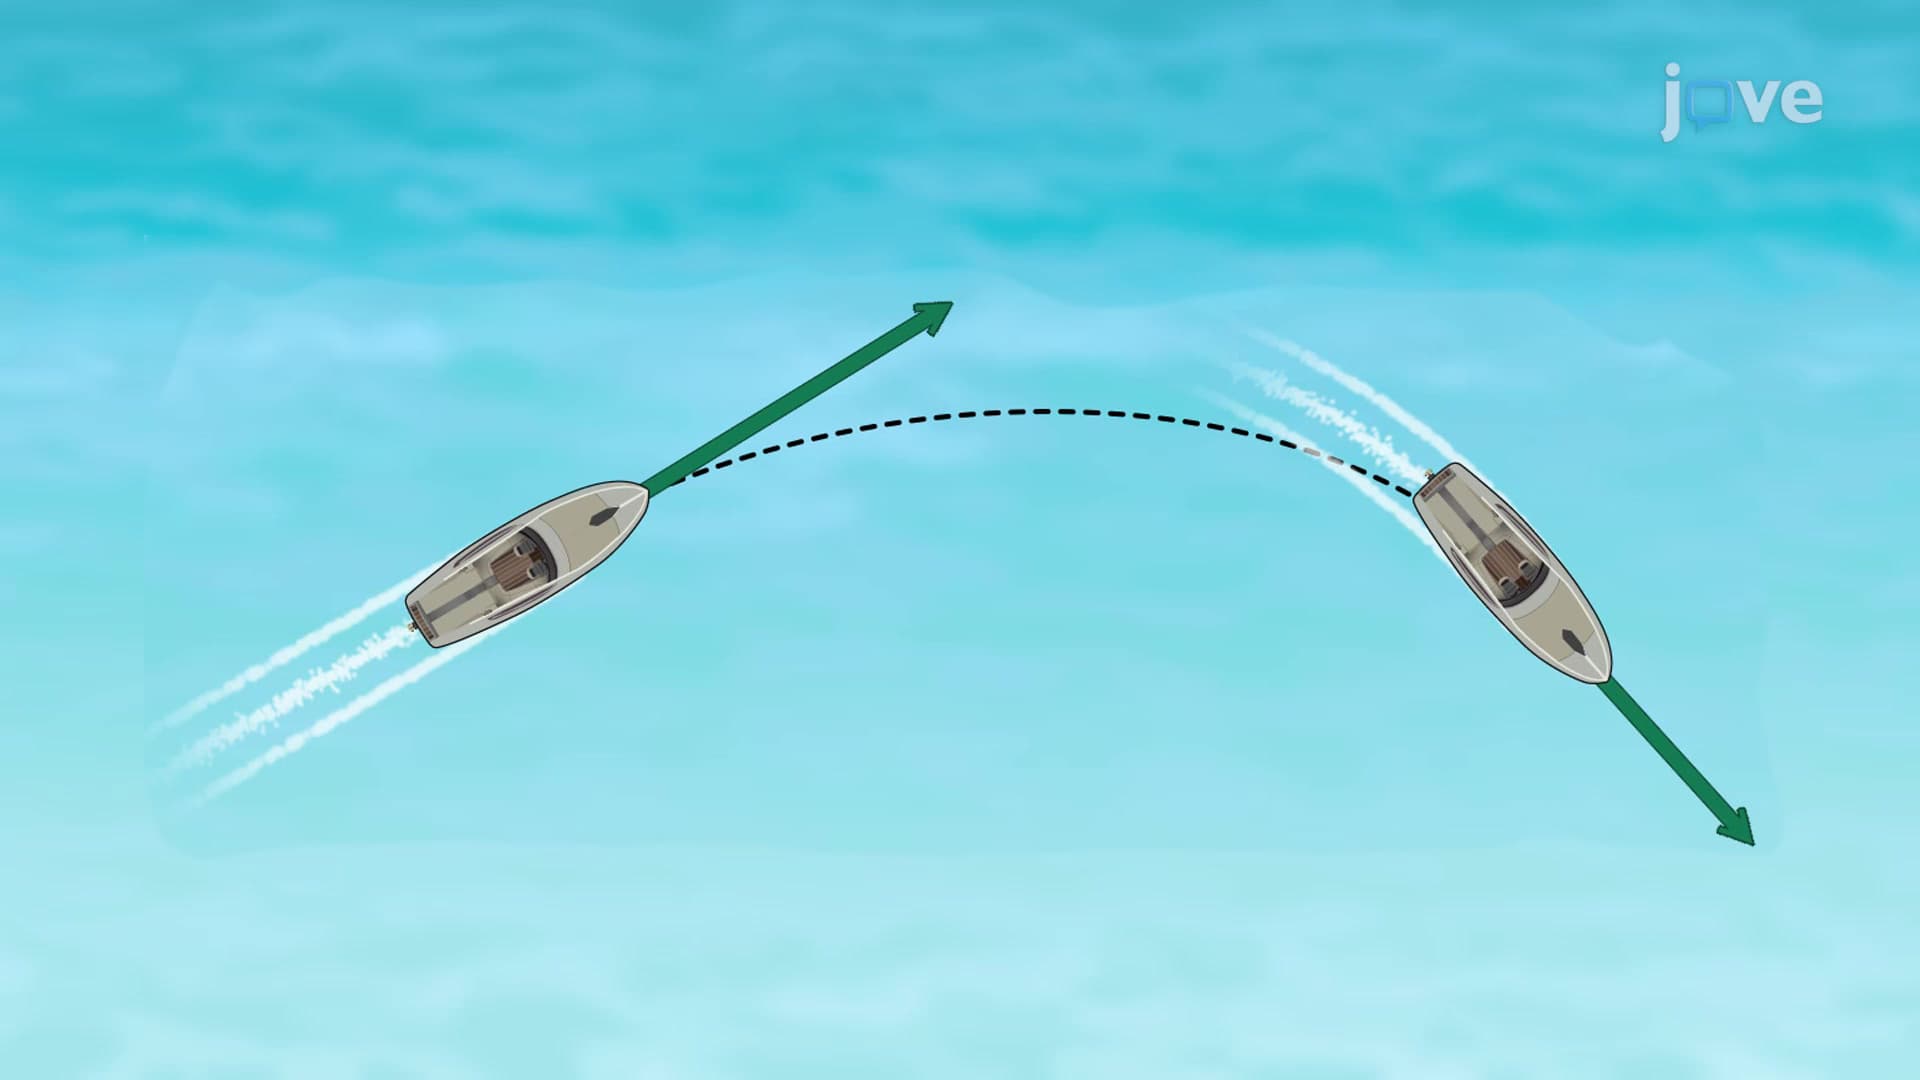 01:30
Acceleration Vectors