Related Experiment Video
Updated: Oct 19, 2025
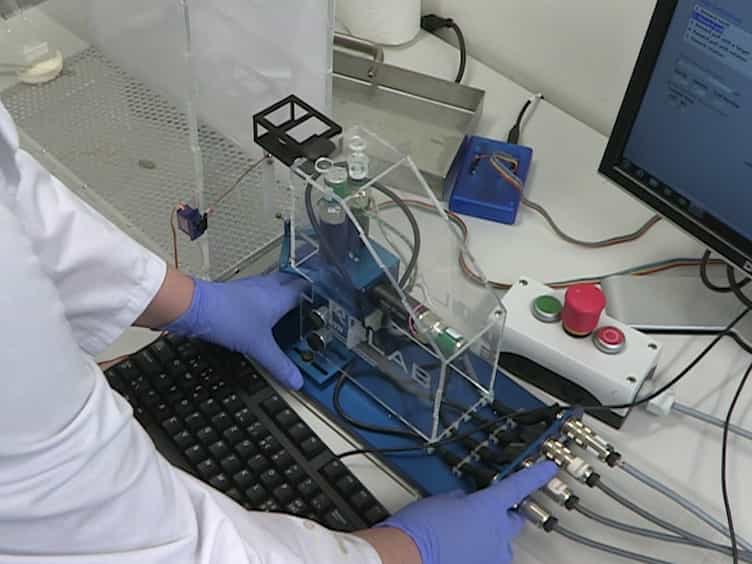
Investigating Motor Skill Learning Processes with a Robotic Manipulandum
Published on: February 12, 2017
Human-robot skill transmission for mobile robot via learning by demonstration
Jiehao Li1, Junzheng Wang1, Shoukun Wang1
1State Key Laboratory of Intelligent Control and Decision of Complex Systems, School of Automation, Beijing Institute of Technology, Beijing, 100081 China.

Abstract:
This paper proposed a skill transmission technique for the mobile robot via learning by demonstration. When the material is transported to the designated location, the robot can show the human-like capabilities: autonomous tracking target. In this case, a skill transmission framework is designed, which the Kinect sensor is utilized to distinguish human activity recognition to create a planned path. Moreover, the dynamic movement primitive method is implemented to represent the teaching data, and the Gaussian mixture regression is utilized to encode the learning trajectory. Furthermore, in order to realize the accurate position control of trajectory tracking, a model predictive tracking control is investigated, where the recurrent neural network is used to eliminate the uncertain interaction. Finally, some experimental tasks using the mobile robot (BIT-6NAZA) are carried out to demonstrate the effectiveness of the developed techniques in real-world scenarios.
Related Concept Videos
 02:16
Stereotype Content Model
 01:12
Observational Learning