Related Experiment Video
Updated: Oct 12, 2025
Long-term Video Tracking of Cohoused Aquatic Animals: A Case Study of the Daily Locomotor Activity of the Norway Lobster Nephrops norvegicus
Published on: April 8, 2019
A Novel Hybrid Level Set Model for Non-Rigid Object Contour Tracking

Abstract:
Most existing trackers use bounding boxes for object tracking. However, the background contained in the bounding box inevitably decreases the accuracy of the target model, which affects the performance of the tracker and is particularly pronounced for non-rigid objects. To address the above issue, this paper proposes a novel hybrid level set model, which can robustly address the issue of topology changing, occlusions and abrupt motion in non-rigid object tracking by accurately tracking the object contour. In particular, an appearance model is first obtained by repeatedly training and relabeling the initial labeled frame using competing one-class SVMs. Then, by integrating the trained appearance model, an edge detector and image spatial information into the level set model, a new hybrid level set model is presented, which accurately locates the object contour and feeds back to the competing one-class SVMs to update the appearance model of the next frame. In addition, a motion model is defined to predict the accurate location of the object when occlusion and abrupt motion occur in the next frame. Finally, the experimental results on state-of-the-art benchmarks demonstrate the feasibility and effectiveness of the proposed model and the superiority of the proposed method over existing trackers in terms of accuracy and robustness.

Related Concept Videos
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:27
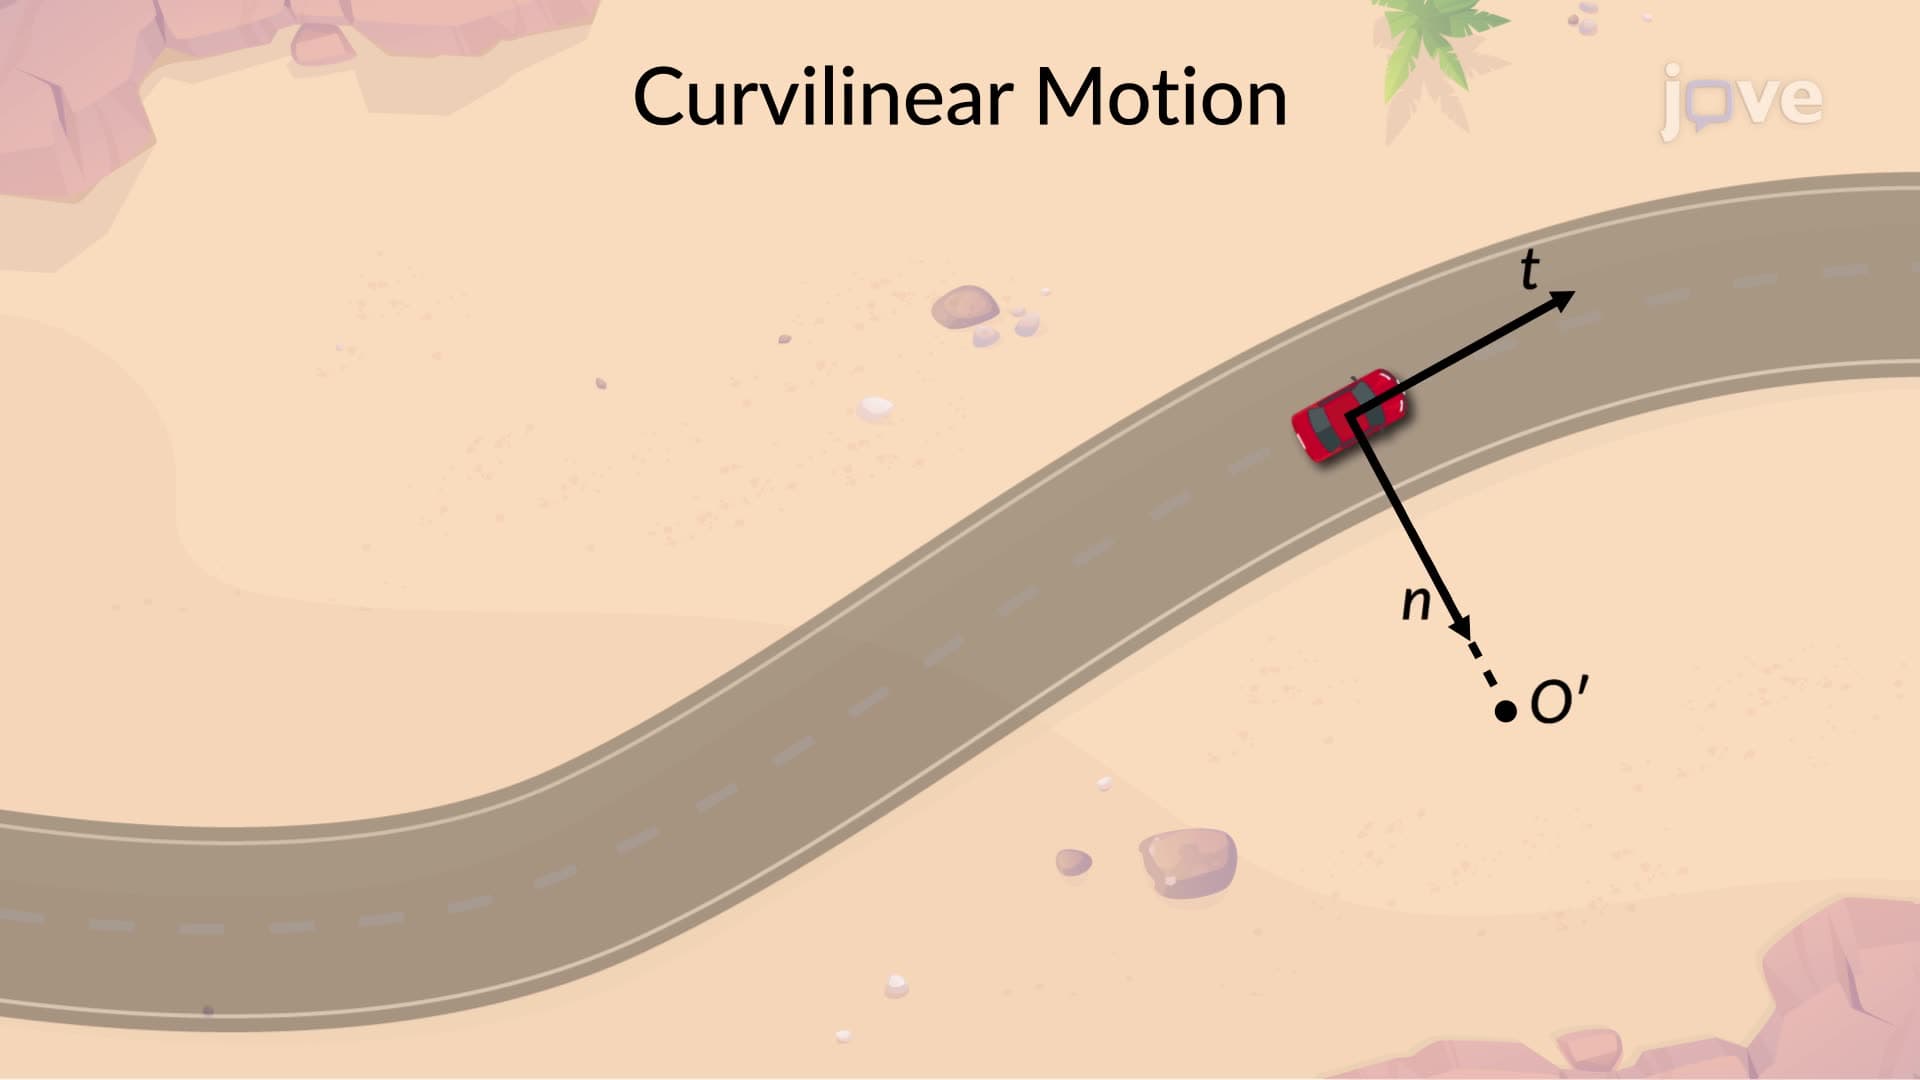
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:14
Conservation of Mass in Moving, Nondeforming Control Volume
In the context of a detention basin, the conservation of mass states that the total mass of water entering the basin must equal the mass leaving the basin plus any accumulation of...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:12
Differential Leveling