Related Experiment Video
Updated: Oct 11, 2025


An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
An active impulsive noise control algorithm with a post-adaptive filter and variable step size
Shanjun Li1, Guoyong Jin1, Yukun Chen1
1College of Power and Energy Engineering, Harbin Engineering University, Harbin, 150001, People's Republic of China.

Abstract:
Active noise control algorithms aimed at reducing Gaussian noise have been studied. However, the performance of these algorithms can deteriorate if impulsive noise or other non-Gaussian noise such as piling noise exists. To solve this problem, an algorithm named the filtered-x affine projection sign algorithm with a post-adaptive filter is proposed to reduce impulsive noise. The proposed algorithm is based on the filtered-x affine projection sign algorithm and the post-adaptive filter structure. In addition, an algorithm with a variable step size is proposed to improve the performance of the filtered-x affine projection sign algorithm with a post-adaptive filter by using a convex combination strategy. The fixed step size in the convex combination is replaced with a linear function of the ratio between the estimated error signal and the estimated desired signal. The detailed derivation processes of the proposed algorithms are given. The computational complexities are analyzed. Numerical simulations are carried out to demonstrate the performance of the proposed algorithms. The results illustrate that the proposed algorithms can effectively reduce impulsive noise. At the same time, the algorithm with a variable step size has better convergence performance than the filtered-x affine projection sign algorithm with a post-adaptive filter.
More Related Videos
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
 06:51
Microparticle Manipulation by Standing Surface Acoustic Waves with Dual-frequency Excitations
Published on: August 21, 2018
Related Concept Videos
 01:25
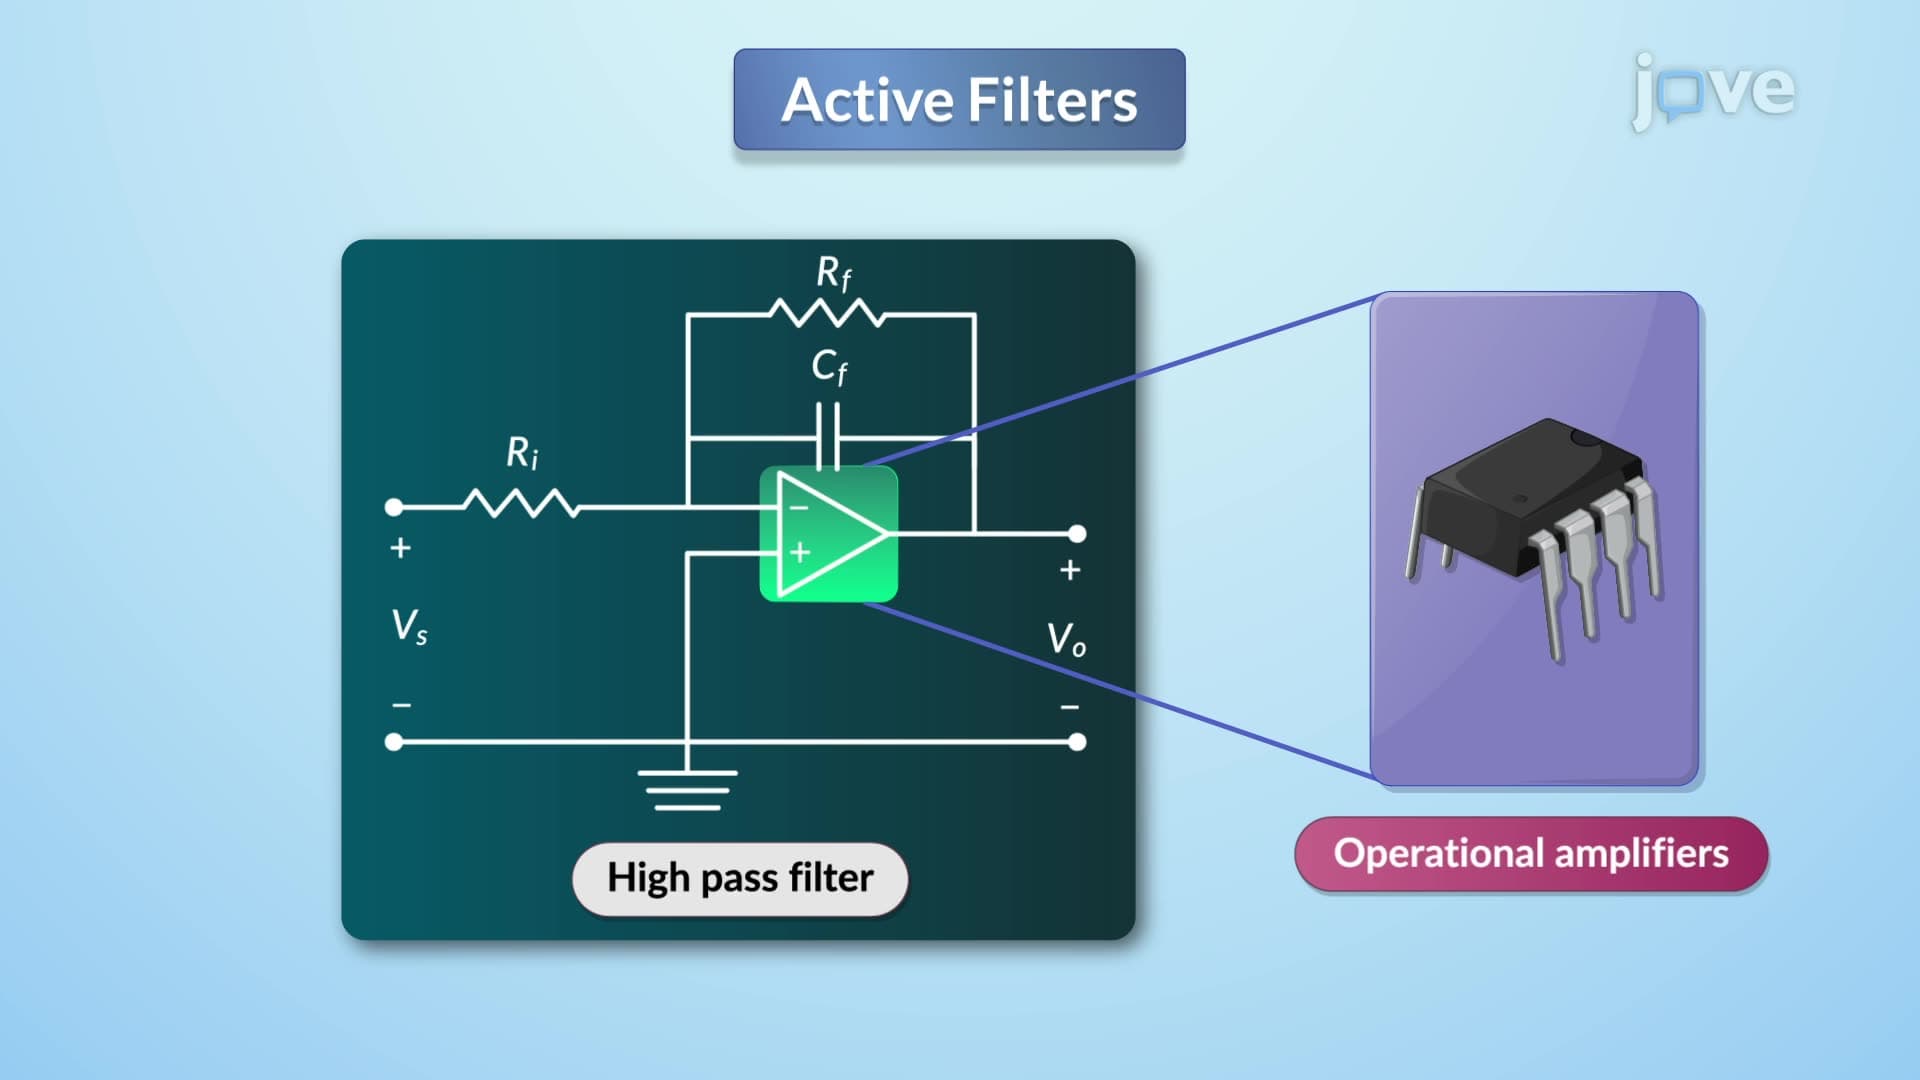
Active Filters
 01:22
Phase-lead and Phase-lag Controllers
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
 01:22
Upsampling