

Differential Evolution Algorithm-Based Iterative Sliding Mode Control of Underactuated Ship Motion
Huaran Yan1, Yingjie Xiao1, Qinrong Li1,2
1Merchant Marine College, Shanghai Maritime University, Shanghai 201306, China.

Abstract:
The differential evolution algorithm (DEA)-based iterative sliding mode control (ISMC) method was proposed for the path tracking problem of three-degree-of-freedom (3-DoF) underactuated ships under external interference, with the nonlinear separate model proposed by mathematical model group (MMG). To improve control quality and enhance robustness of the control system, a swarm intelligence optimization algorithm is used to design a controller parameter optimization system. The DEA was adopted in the system to solve the minimum system evaluation index function, and the optimal controller parameters are acquired. Considering the impact of chattering on the actual project, a chattering measurement function is defined in the controller design and used as an input of the controller parameter optimization system. Finally, the 5446TEU container ship is carried out for simulation. It is verified that the designed controller with strong robustness can effectively deal with the disturbances; meanwhile, the chattering of the output is significantly reduced, and the control rudder angle signal conforms to the actual operation requirements of the ship and is more in line with the engineering reality.

Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:10
Relative Motion Analysis - Acceleration
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:20
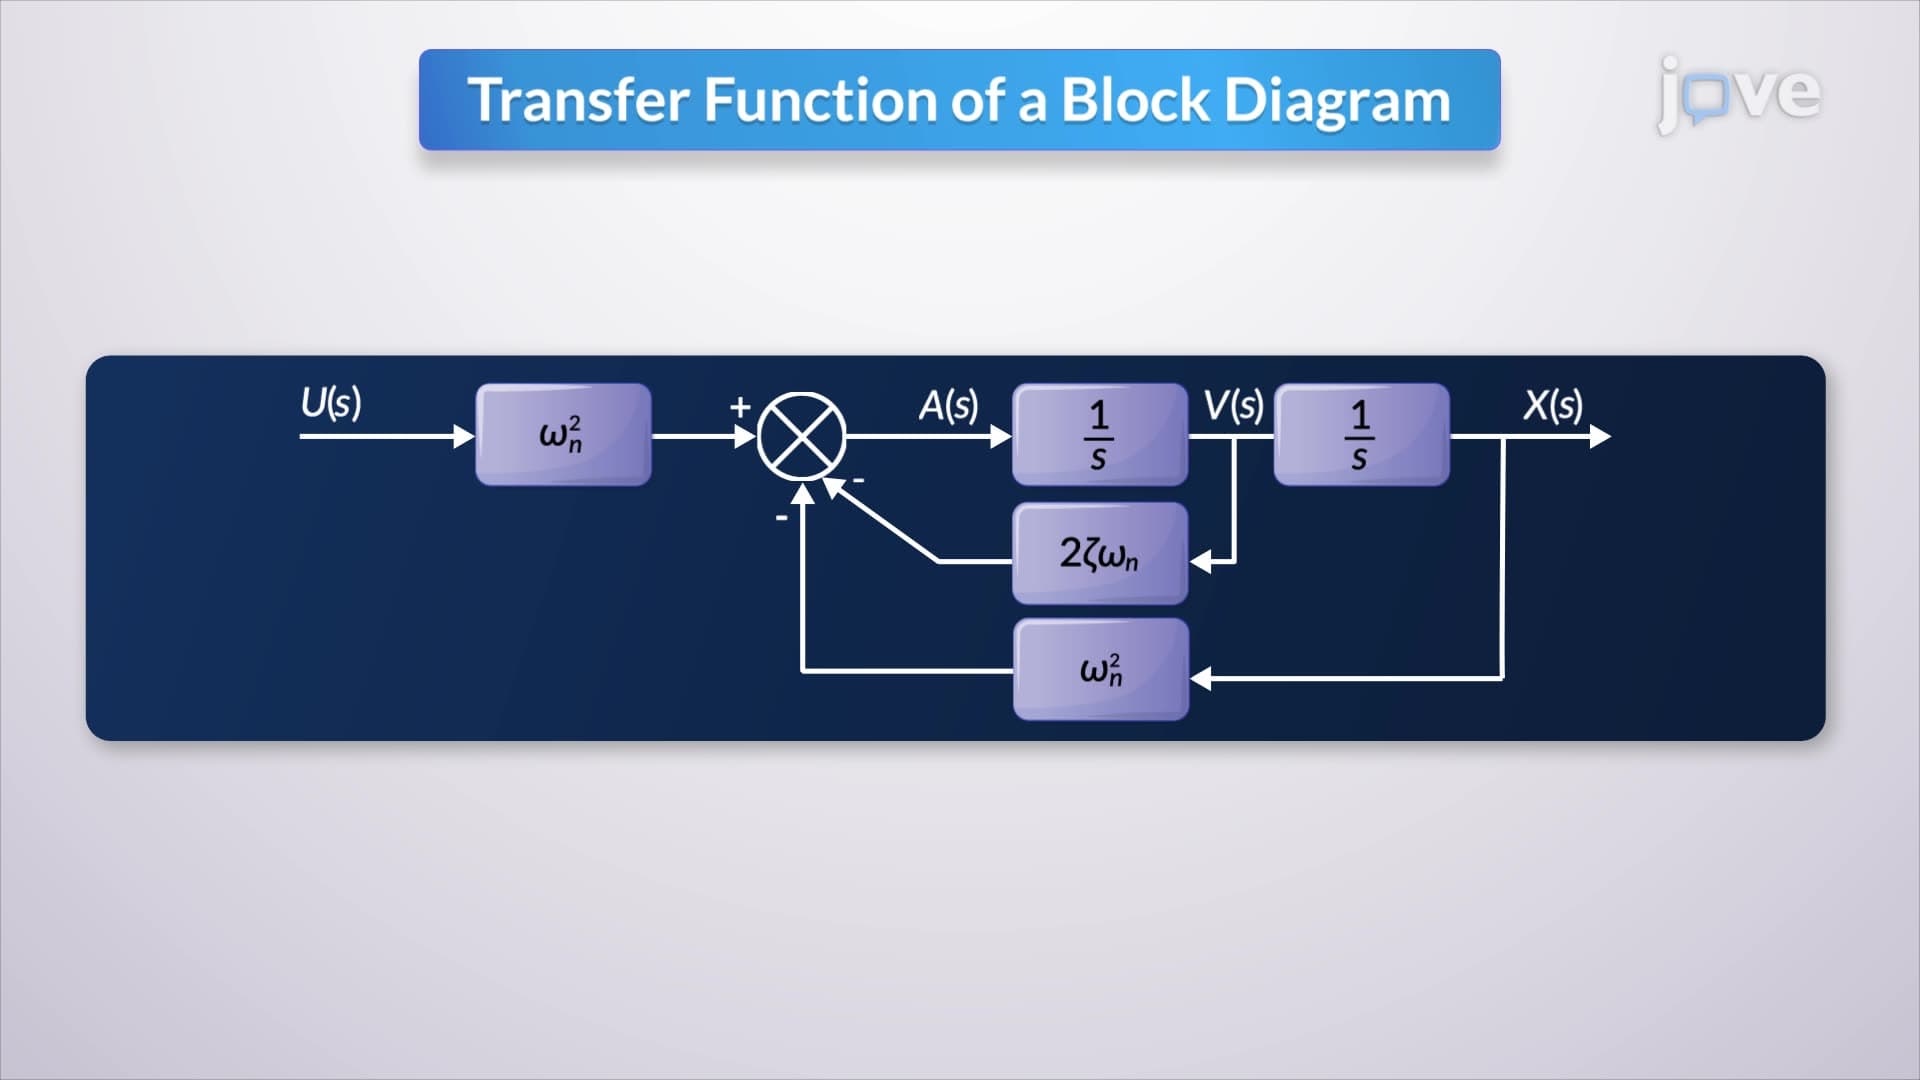
Relation between Mathematical Equations and Block Diagrams