Learning Risk-aware Costmaps for Traversability in Challenging Environments
Related Experiment Video
Updated: Oct 7, 2025
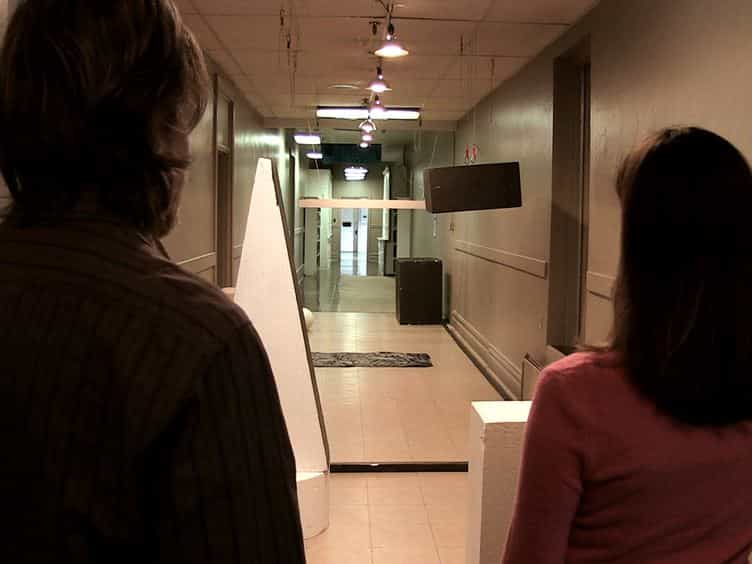
A Standardized Obstacle Course for Assessment of Visual Function in Ultra Low Vision and Artificial Vision
Published on: February 11, 2014
David D Fan1,2, Ali-Akbar Agha-Mohammadi2, Evangelos A Theodorou1
1David D. Fan and Evangelos A. Theodorou are with the Institute for Robotics and Intelligent Machines, Georgia Institute of Technology, Atlanta, GA, USA.

Abstract:
One of the main challenges in autonomous robotic exploration and navigation in unknown and unstructured environments is determining where the robot can or cannot safely move. A significant source of difficulty in this determination arises from stochasticity and uncertainty, coming from localization error, sensor sparsity and noise, difficult-to-model robot-ground interactions, and disturbances to the motion of the vehicle. Classical approaches to this problem rely on geometric analysis of the surrounding terrain, which can be prone to modeling errors and can be computationally expensive. Moreover, modeling the distribution of uncertain traversability costs is a difficult task, compounded by the various error sources mentioned above. In this work, we take a principled learning approach to this problem. We introduce a neural network architecture for robustly learning the distribution of traversability costs. Because we are motivated by preserving the life of the robot, we tackle this learning problem from the perspective of learning tail-risks, i.e. the conditional value-at-risk (CVaR). We show that this approach reliably learns the expected tail risk given a desired probability risk threshold between 0 and 1, producing a traversability costmap which is more robust to outliers, more accurately captures tail risks, and is more computationally efficient, when compared against baselines. We validate our method on data collected by a legged robot navigating challenging, unstructured environments including an abandoned subway, limestone caves, and lava tube caves.
Related Concept Videos
 01:17
Design Example: Analyzing Capacity Contours for Flood Risk Assessment
 01:19
Design Example: Maintaining Level of an Embankment
 01:15
Elastic Collisions: Case Study
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:28
Survey Safety
 01:12
Adjusting a Traverse