Kinematic-Model-Free Predictive Control for Robotic Manipulator Target Reaching With Obstacle Avoidance
Related Experiment Video
Updated: Oct 3, 2025

Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Ahmad AlAttar1,2, Digby Chappell1, Petar Kormushev1
1Robot Intelligence Lab, Dyson School of Design Engineering, Imperial College London, London, United Kingdom.

Abstract:
Model predictive control is a widely used optimal control method for robot path planning and obstacle avoidance. This control method, however, requires a system model to optimize control over a finite time horizon and possible trajectories. Certain types of robots, such as soft robots, continuum robots, and transforming robots, can be challenging to model, especially in unstructured or unknown environments. Kinematic-model-free control can overcome these challenges by learning local linear models online. This paper presents a novel perception-based robot motion controller, the kinematic-model-free predictive controller, that is capable of controlling robot manipulators without any prior knowledge of the robot's kinematic structure and dynamic parameters and is able to perform end-effector obstacle avoidance. Simulations and physical experiments were conducted to demonstrate the ability and adaptability of the controller to perform simultaneous target reaching and obstacle avoidance.
Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
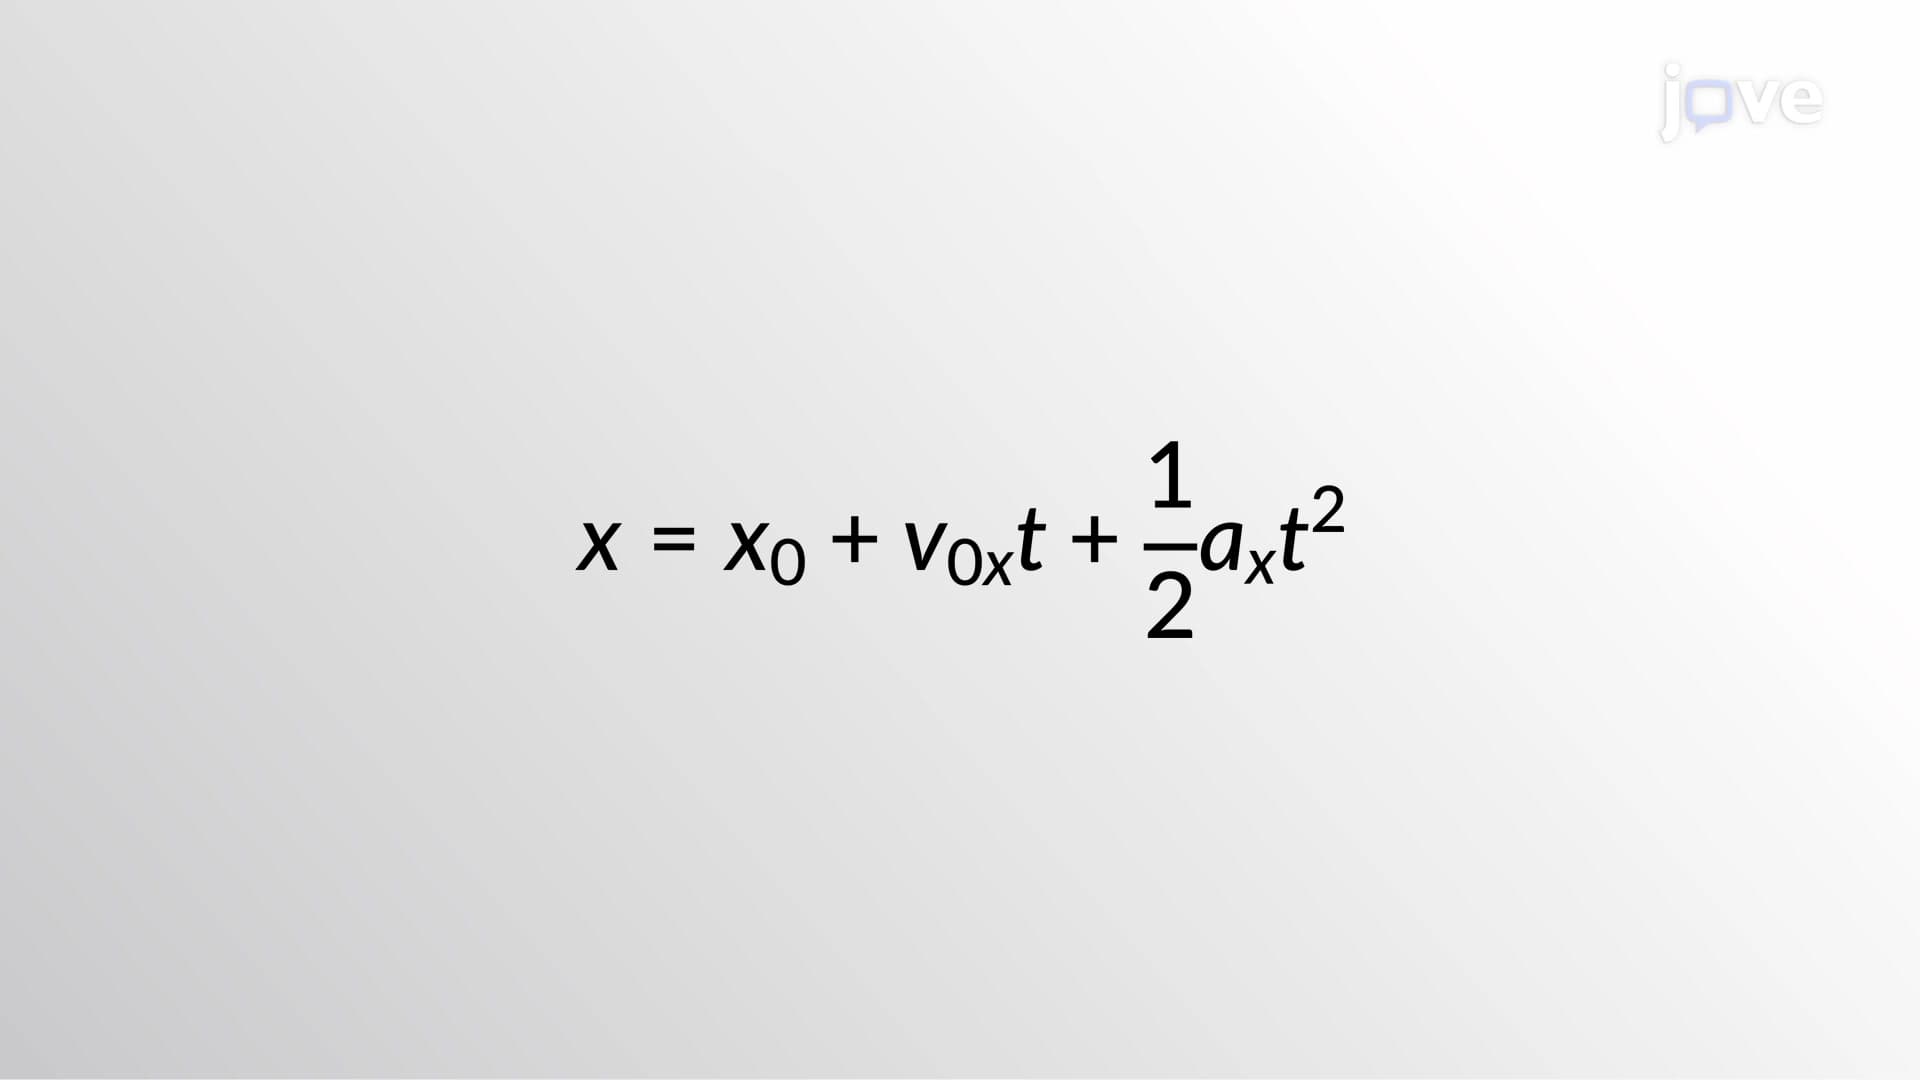 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:18
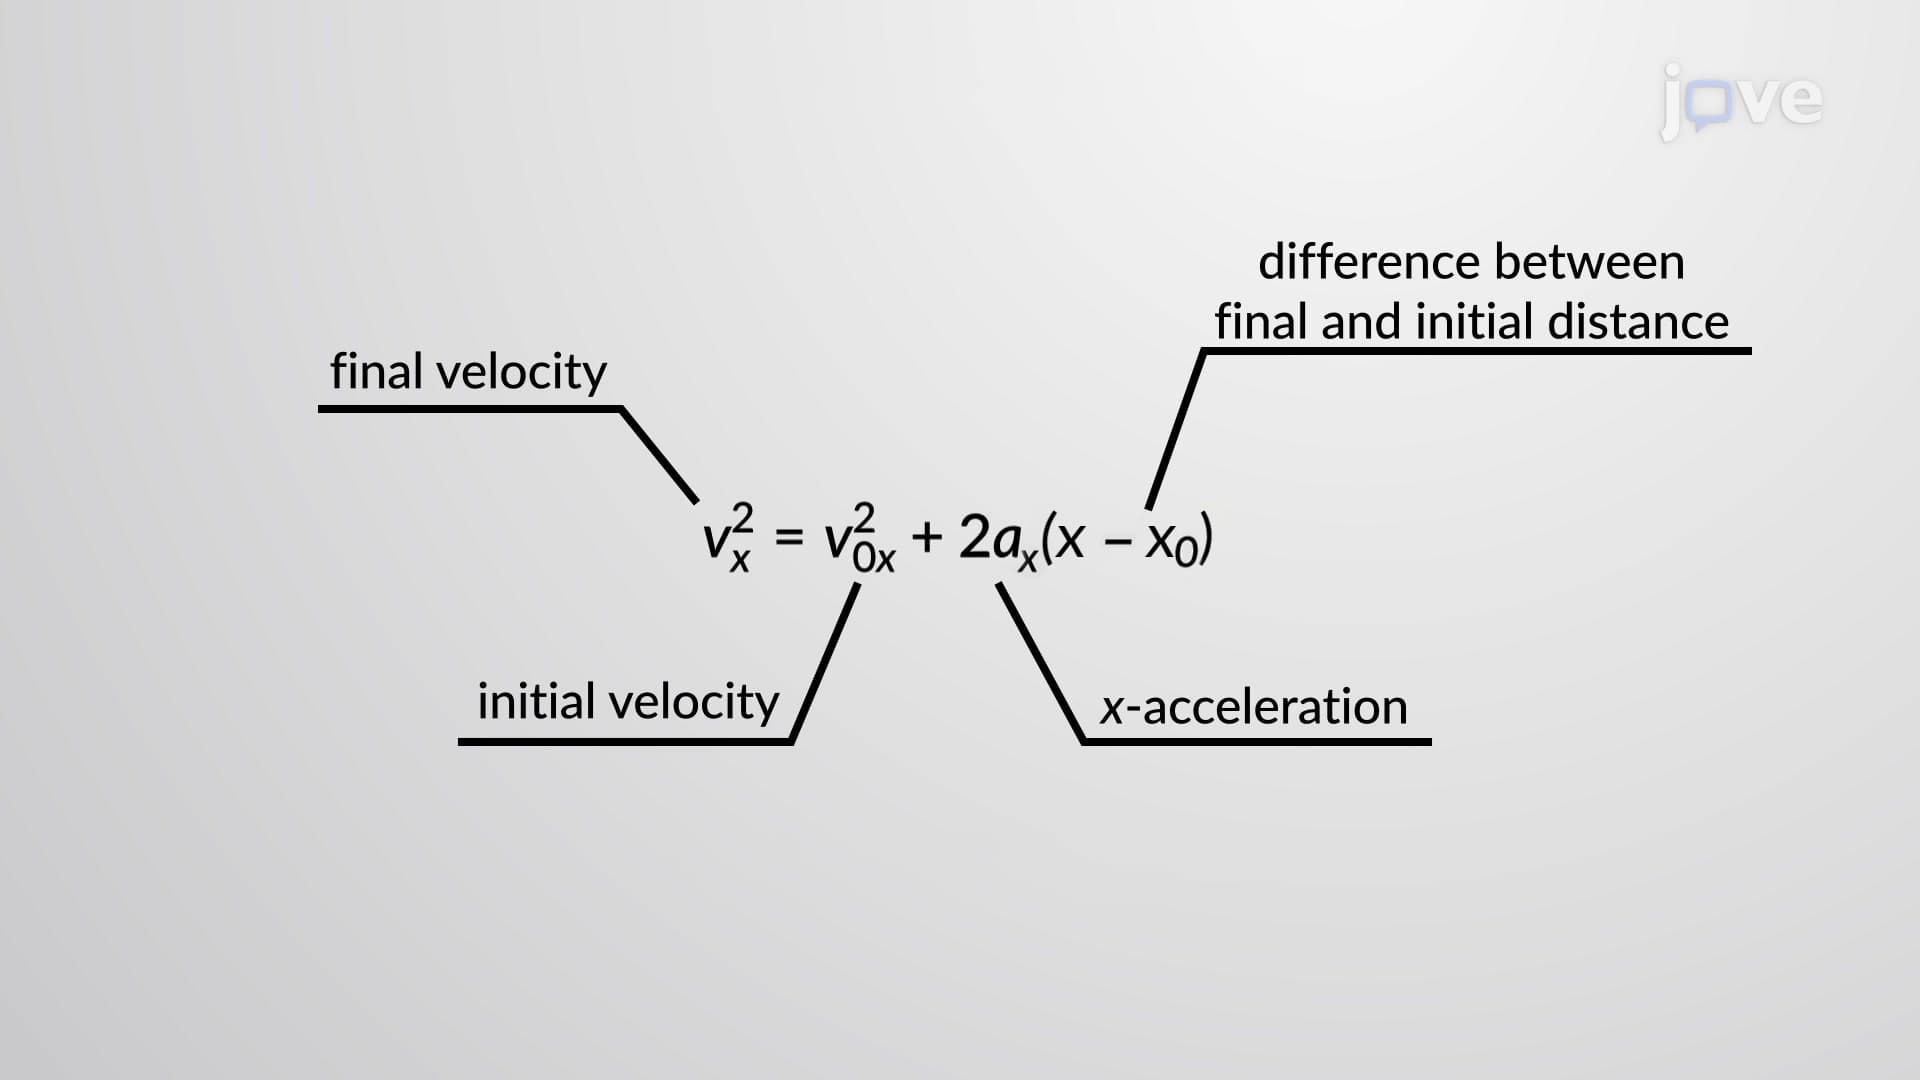
Kinematic Equations - III
Using the kinematic equations,...
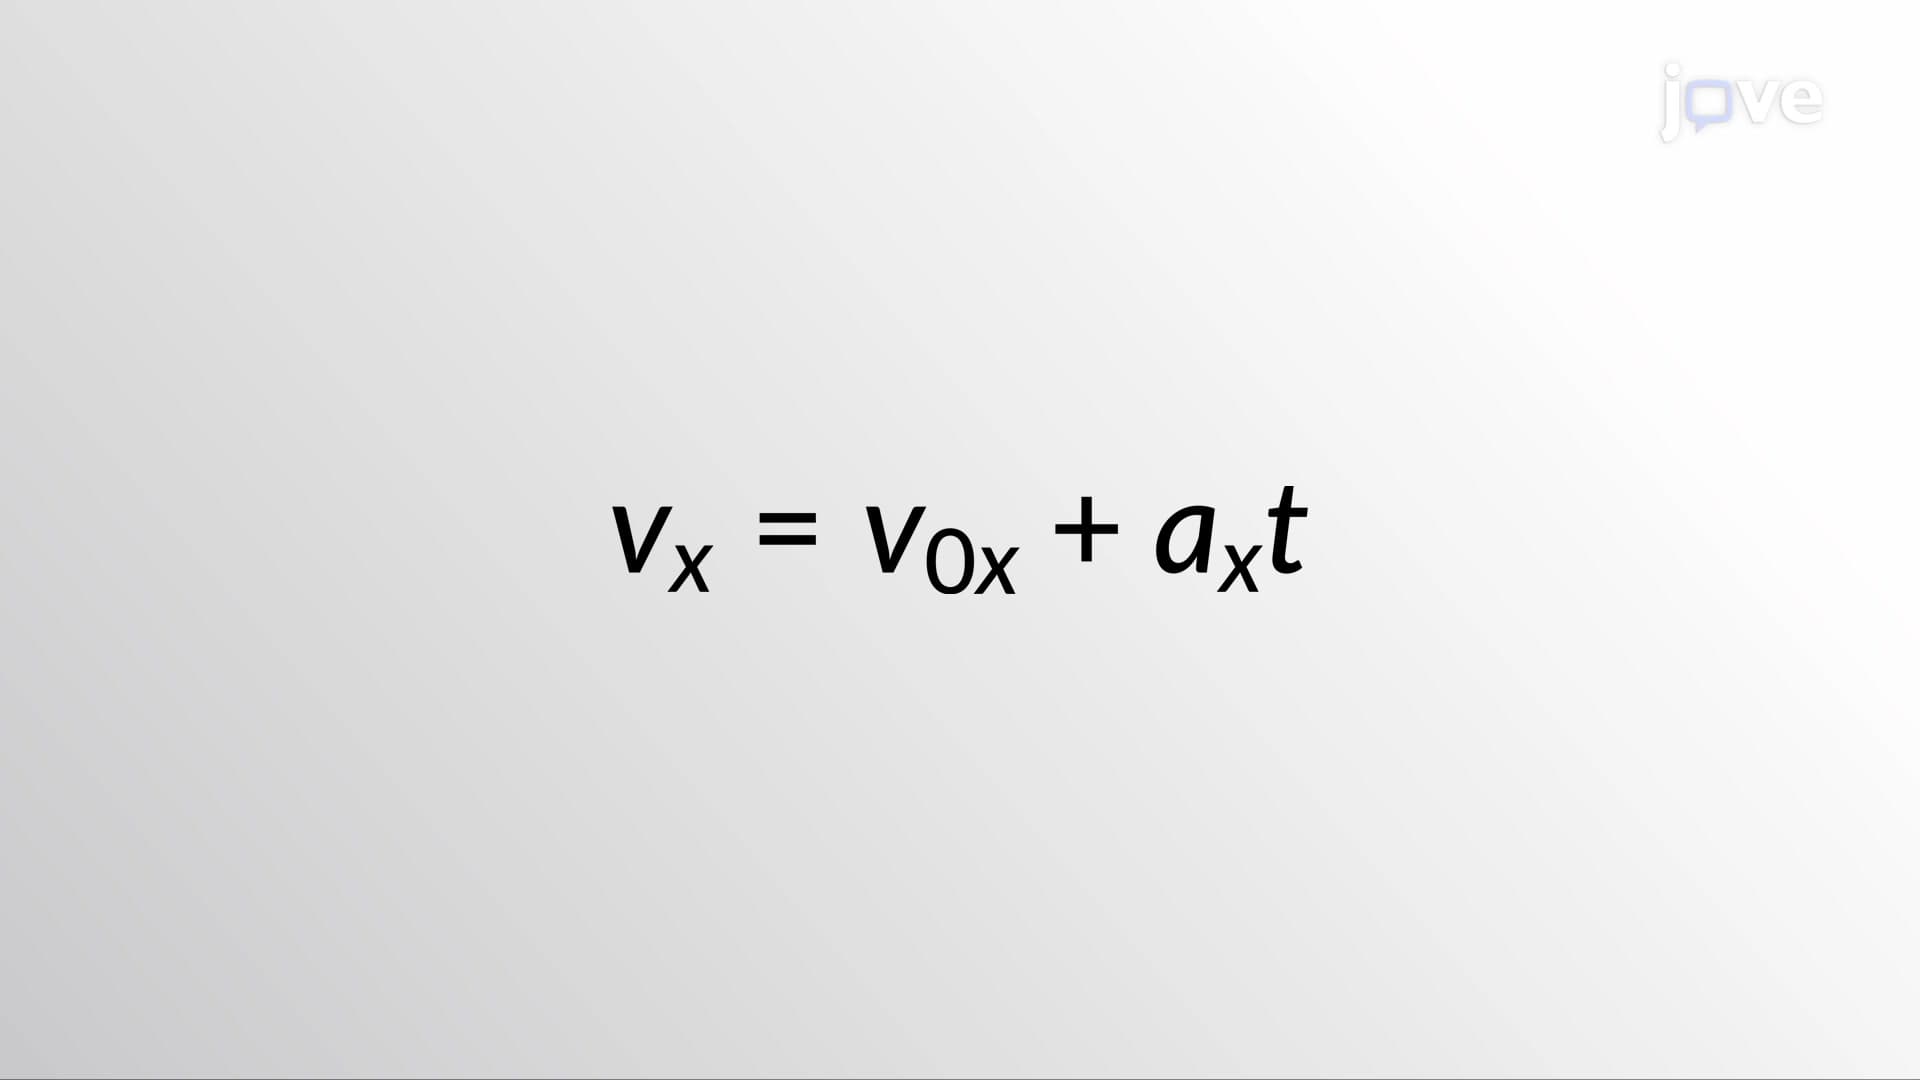 01:26
Kinematic Equations - I