Related Experiment Video
Updated: Oct 1, 2025

Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
Fast Online Optimization for Terrain-Blind Bipedal Robot Walking With a Decoupled Actuated SLIP Model
Ke Wang1, Hengyi Fei2, Petar Kormushev1
1Robot Intelligence Lab, Dyson School of Design Engineering, Imperial College London, London, United Kingdom.

Abstract:
We present an online optimization algorithm which enables bipedal robots to blindly walk over various kinds of uneven terrains while resisting pushes. The proposed optimization algorithm performs high-level motion planning of footstep locations and center-of-mass height variations using the decoupled actuated spring-loaded inverted pendulum (aSLIP) model. The decoupled aSLIP model simplifies the original aSLIP with linear inverted pendulum (LIP) dynamics in horizontal states and spring dynamics in the vertical state. The motion planning can be formulated as a discrete-time model predictive control (MPC) problem and solved at a frequency of 1 kHz. The output of the motion planner is fed into an inverse-dynamics-based whole body controller for execution on the robot. A key result of this controller is that the feet of the robot are compliant, which further extends the robot's ability to be robust to unobserved terrain variations. We evaluate our method in simulation with the bipedal robot SLIDER. The results show that the robot can blindly walk over various uneven terrains including slopes, wave fields, and stairs. It can also resist pushes of up to 40 N for a duration of 0.1 s while walking on uneven terrains.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:15
Kinematic Equations: Problem Solving
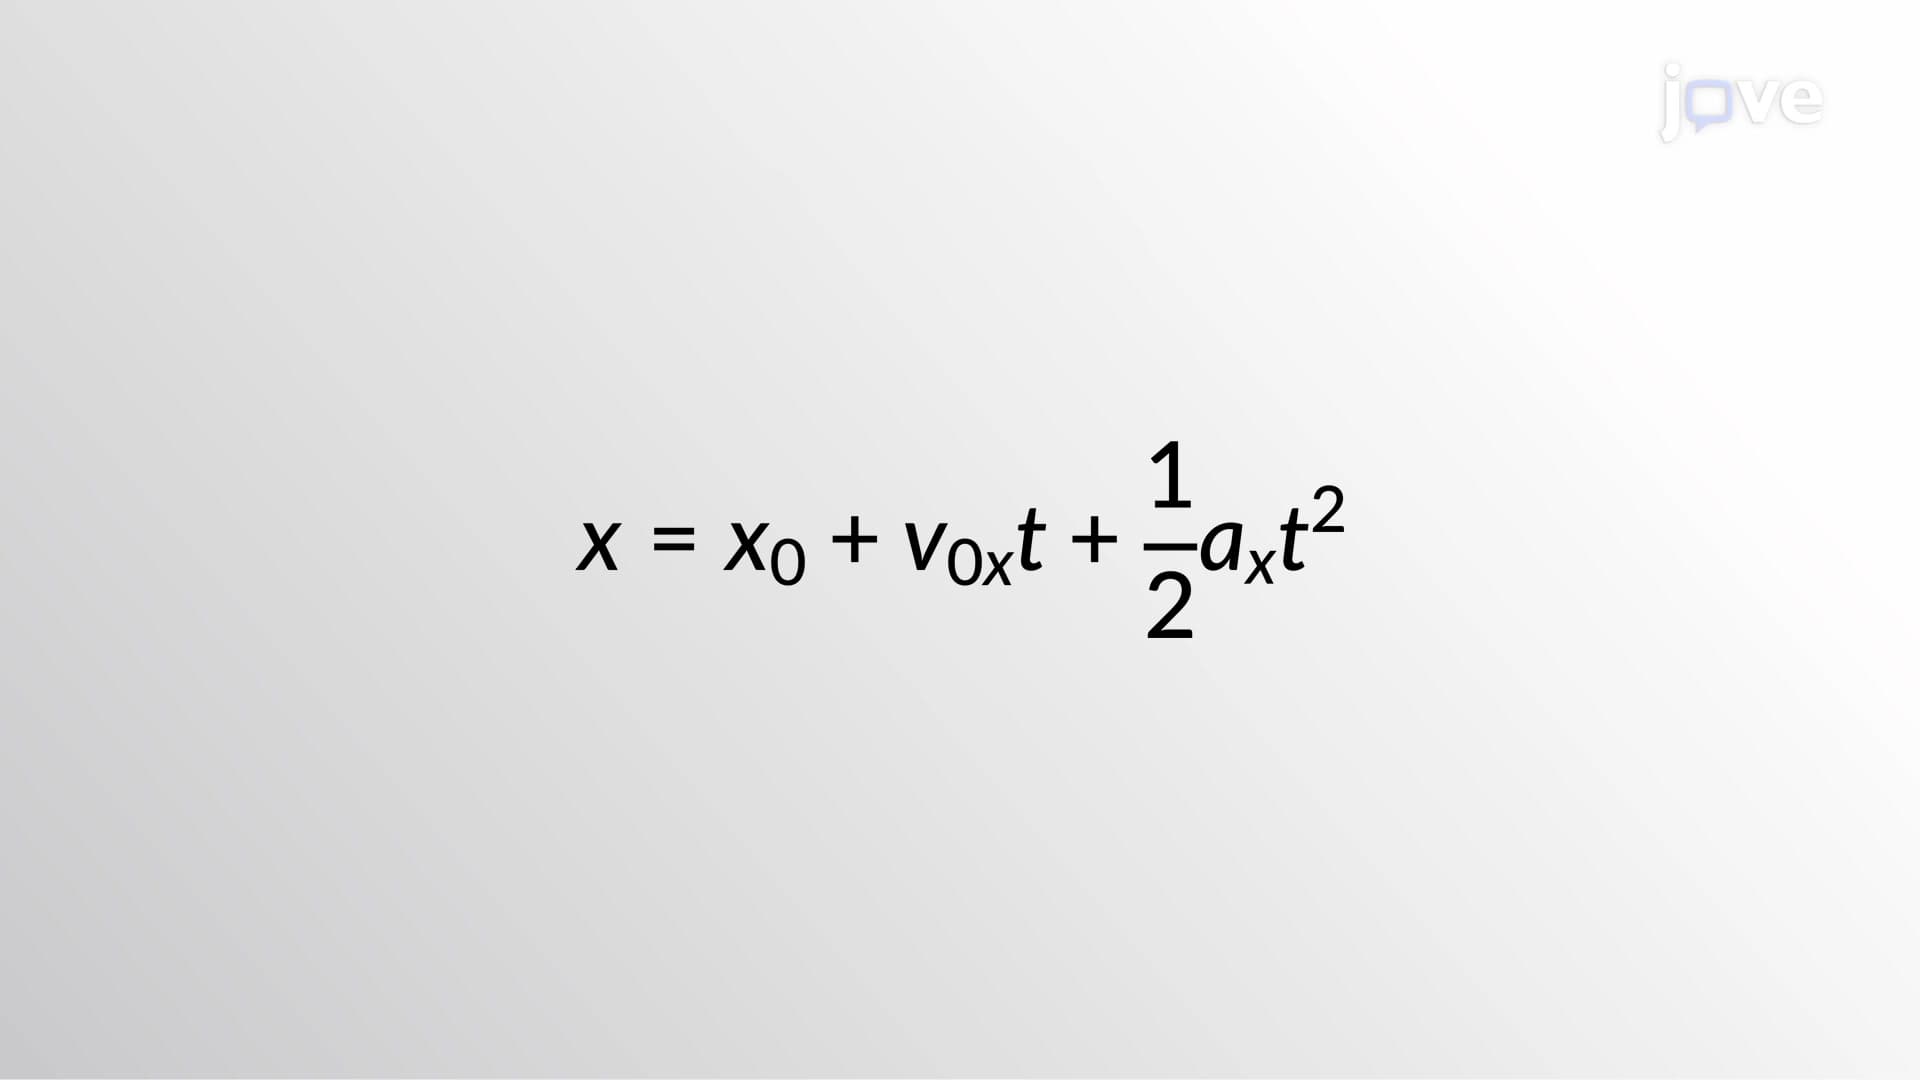 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
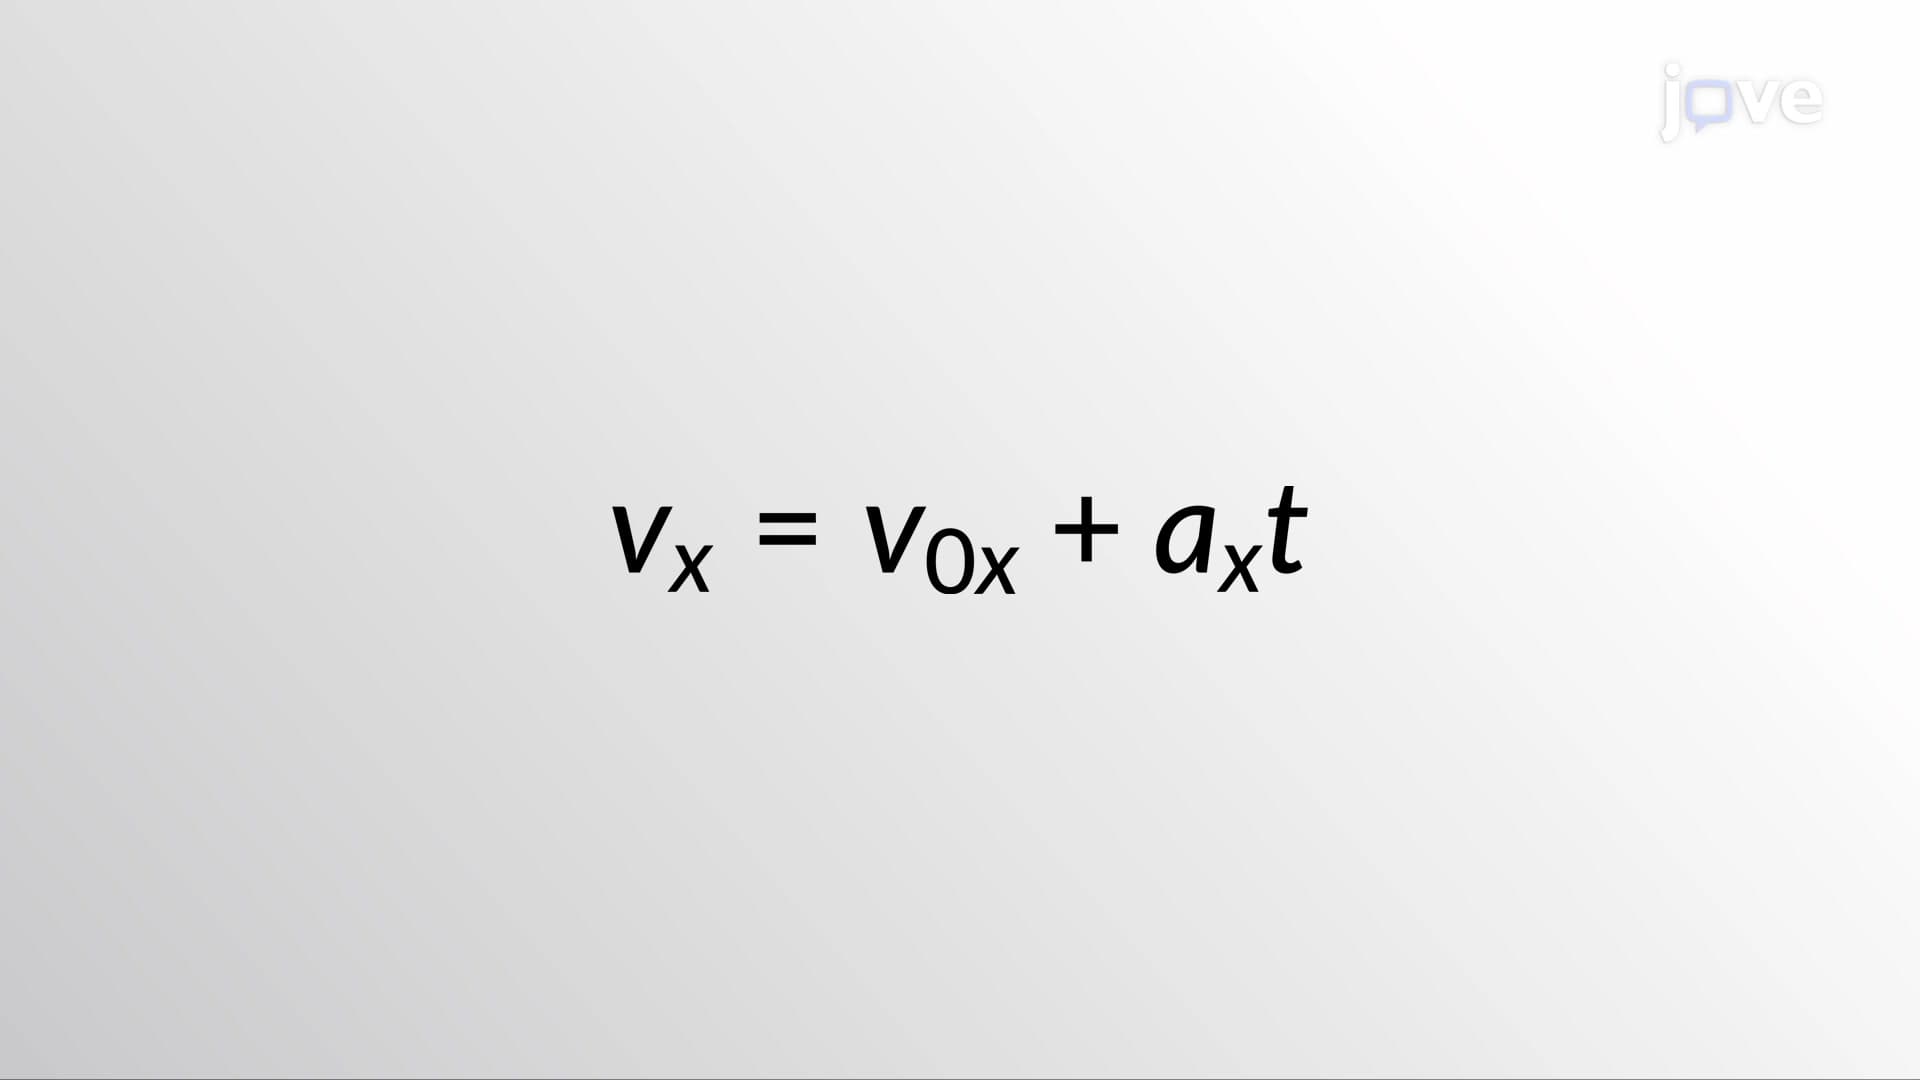 01:26
Kinematic Equations - I