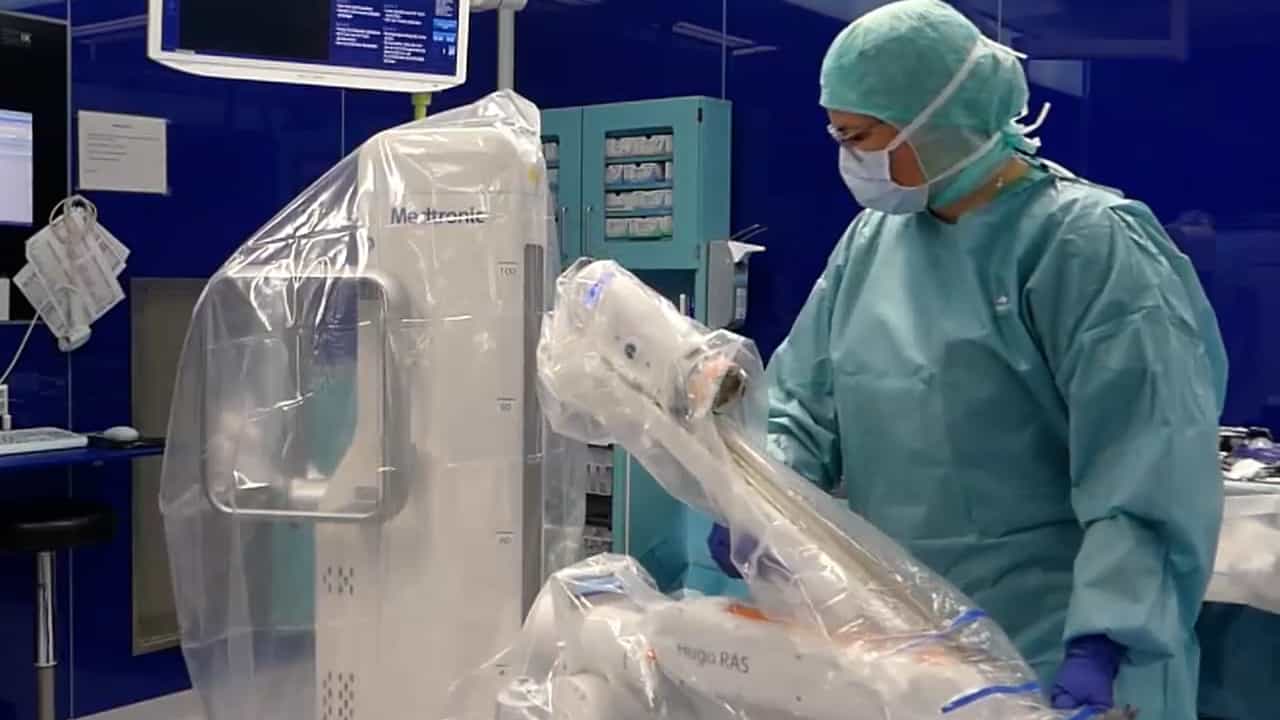
An introductory review of robotically assisted surgical systems
Related Experiment Video
Updated: Sep 25, 2025
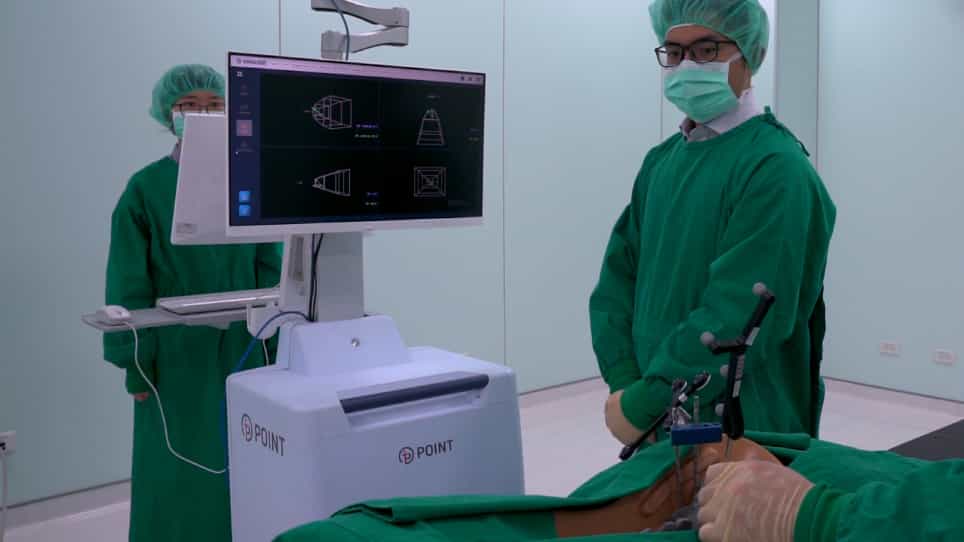
A Teleoperated Robotic System-Assisted Percutaneous Transiliac-Transsacral Screw Fixation Technique
Published on: January 6, 2023
Francesco Cepolina1, Roberto P Razzoli1
1Department of Mechanical Engineering, Energy, Production, Transport and Mathematical Models (DIME), University of Genoa, Genova, Italy.

Purpose:
The scope of the work is to present the state of the art of robotically assisted surgical systems and to give a general idea about how technology can help today and tomorrow robotic surgery. The road to innovation passes through research and on field trials; for this reason, not only commercial surgery robots, but also innovative prototype robots, proposed by the Academic world, are presented.
Design/Methodology/Approach:
Following a short introduction, robotically assisted surgery systems are introduced discussing their architectures and main peculiarities. A further section is dedicated to the key enabling technologies that will make possible to improve current systems and that will lead to a new generation of surgical robotic systems able to meet the patient's needs and facilitate the surgeon's task. Finally, brief concluding comments are given.
Findings:
The idea of using robots for surgery was born many years ago and in a short time a market demand was created. Today the market is very dynamic, and several new products are updated and created for the execution of both traditional and new procedures. The article provides a guide for the reader who has an interest in this area.
Originality/Value:
This paper provides an insight into the commercial robotic surgical systems and a look on research prototypes from academic and industrial worlds.