Related Experiment Video
Updated: Sep 24, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Energy-Based Continuous Inverse Optimal Control

Abstract:
The problem of continuous inverse optimal control (over finite time horizon) is to learn the unknown cost function over the sequence of continuous control variables from expert demonstrations. In this article, we study this fundamental problem in the framework of energy-based model (EBM), where the observed expert trajectories are assumed to be random samples from a probability density function defined as the exponential of the negative cost function up to a normalizing constant. The parameters of the cost function are learned by maximum likelihood via an "analysis by synthesis" scheme, which iterates: 1) synthesis step: sample the synthesized trajectories from the current probability density using the Langevin dynamics via backpropagation through time and 2) analysis step: update the model parameters based on the statistical difference between the synthesized trajectories and the observed trajectories. Given the fact that an efficient optimization algorithm is usually available for an optimal control problem, we also consider a convenient approximation of the above learning method, where we replace the sampling in the synthesis step by optimization. Moreover, to make the sampling or optimization more efficient, we propose to train the EBM simultaneously with a top-down trajectory generator via cooperative learning, where the trajectory generator is used to fast initialize the synthesis step of the EBM. We demonstrate the proposed methods on autonomous driving tasks and show that they can learn suitable cost functions for optimal control.


Related Concept Videos
 01:10
Control Systems
At the heart...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:14
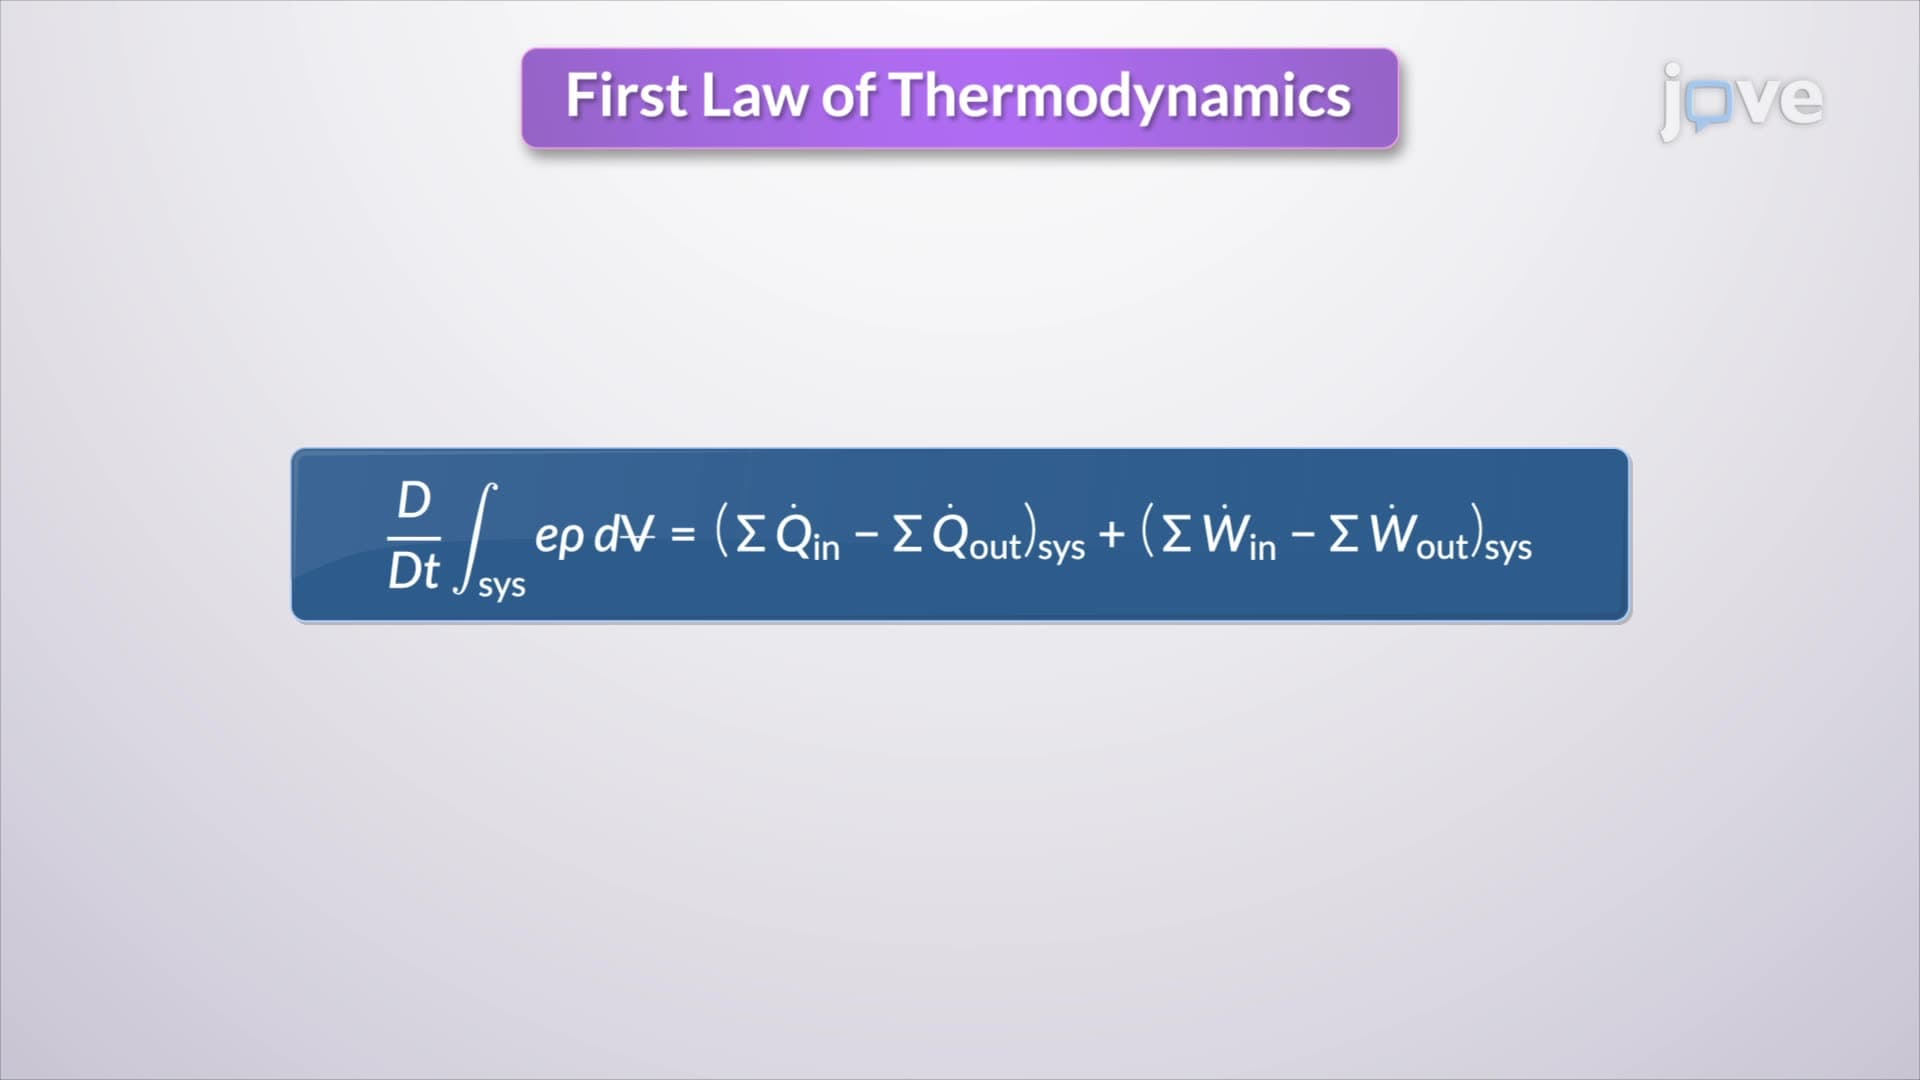
Conservation of Energy in Control Volume
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
 01:21
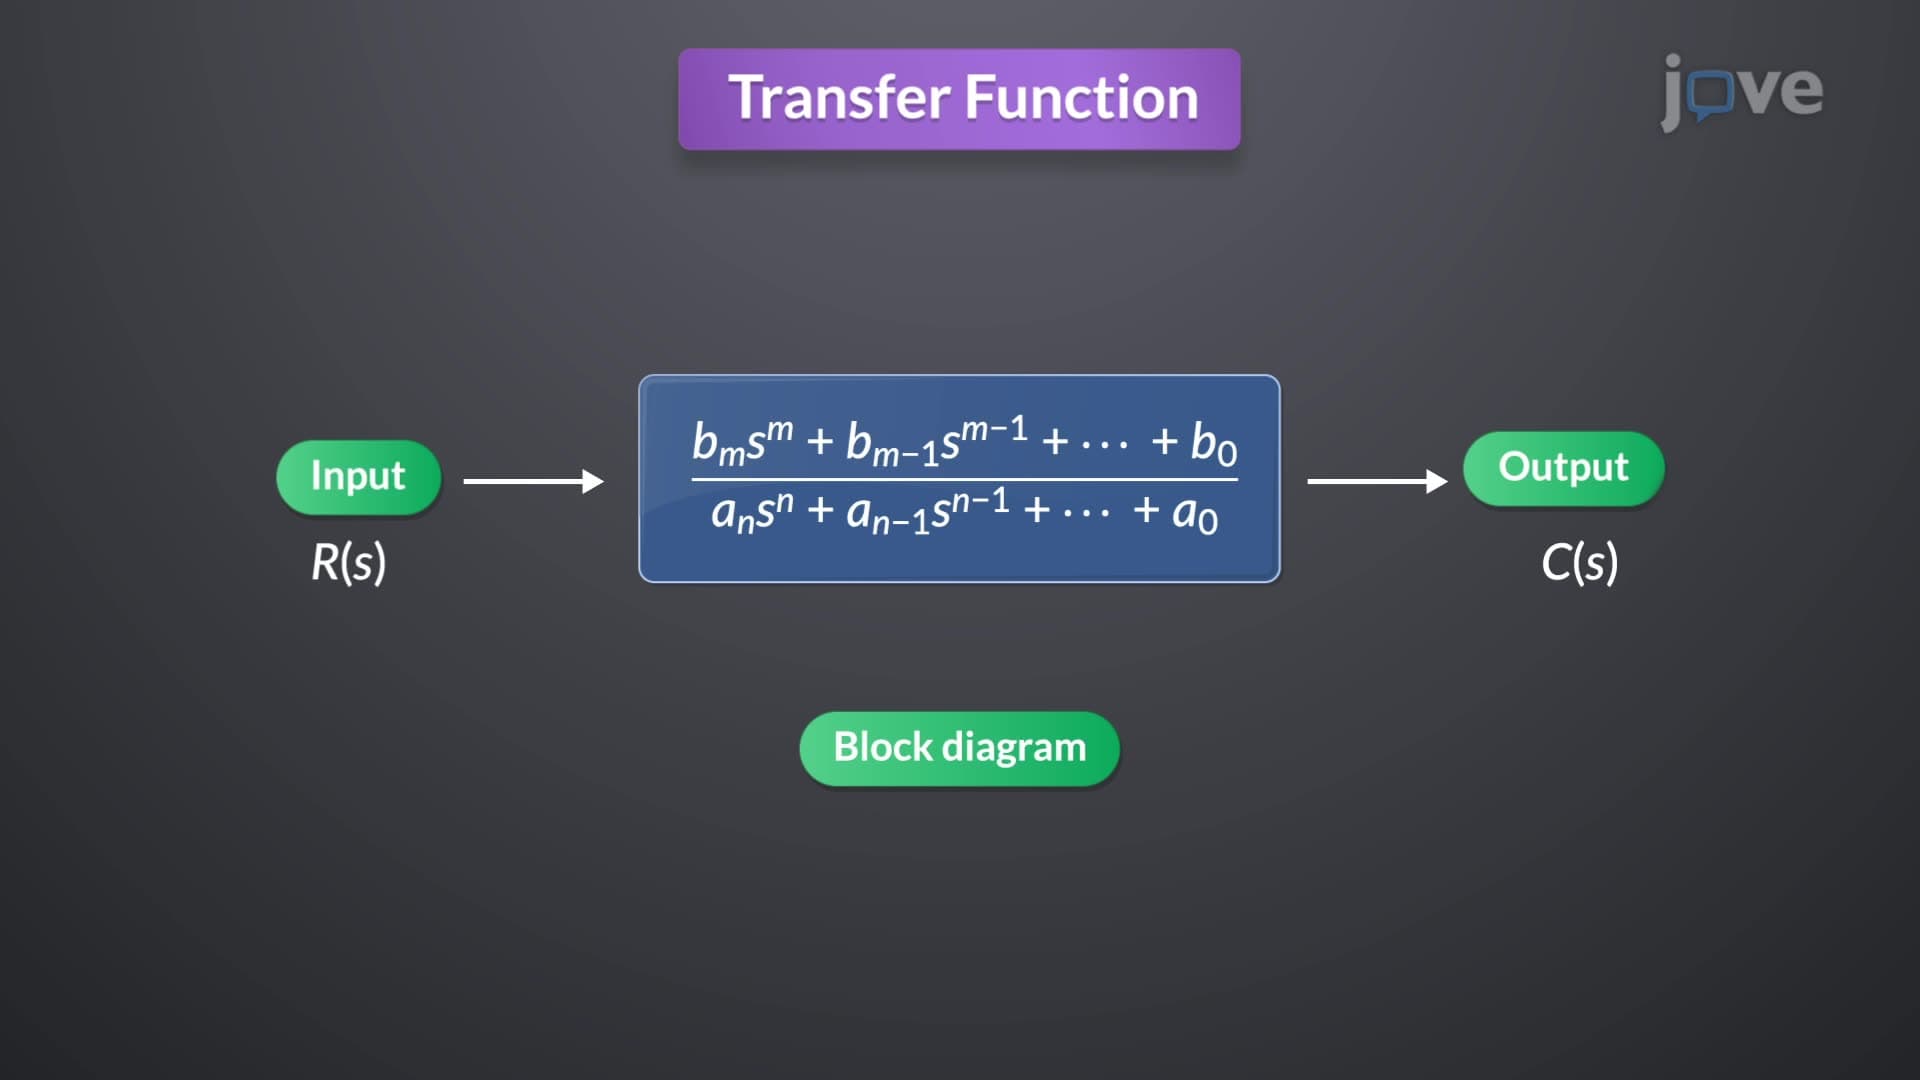
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:13
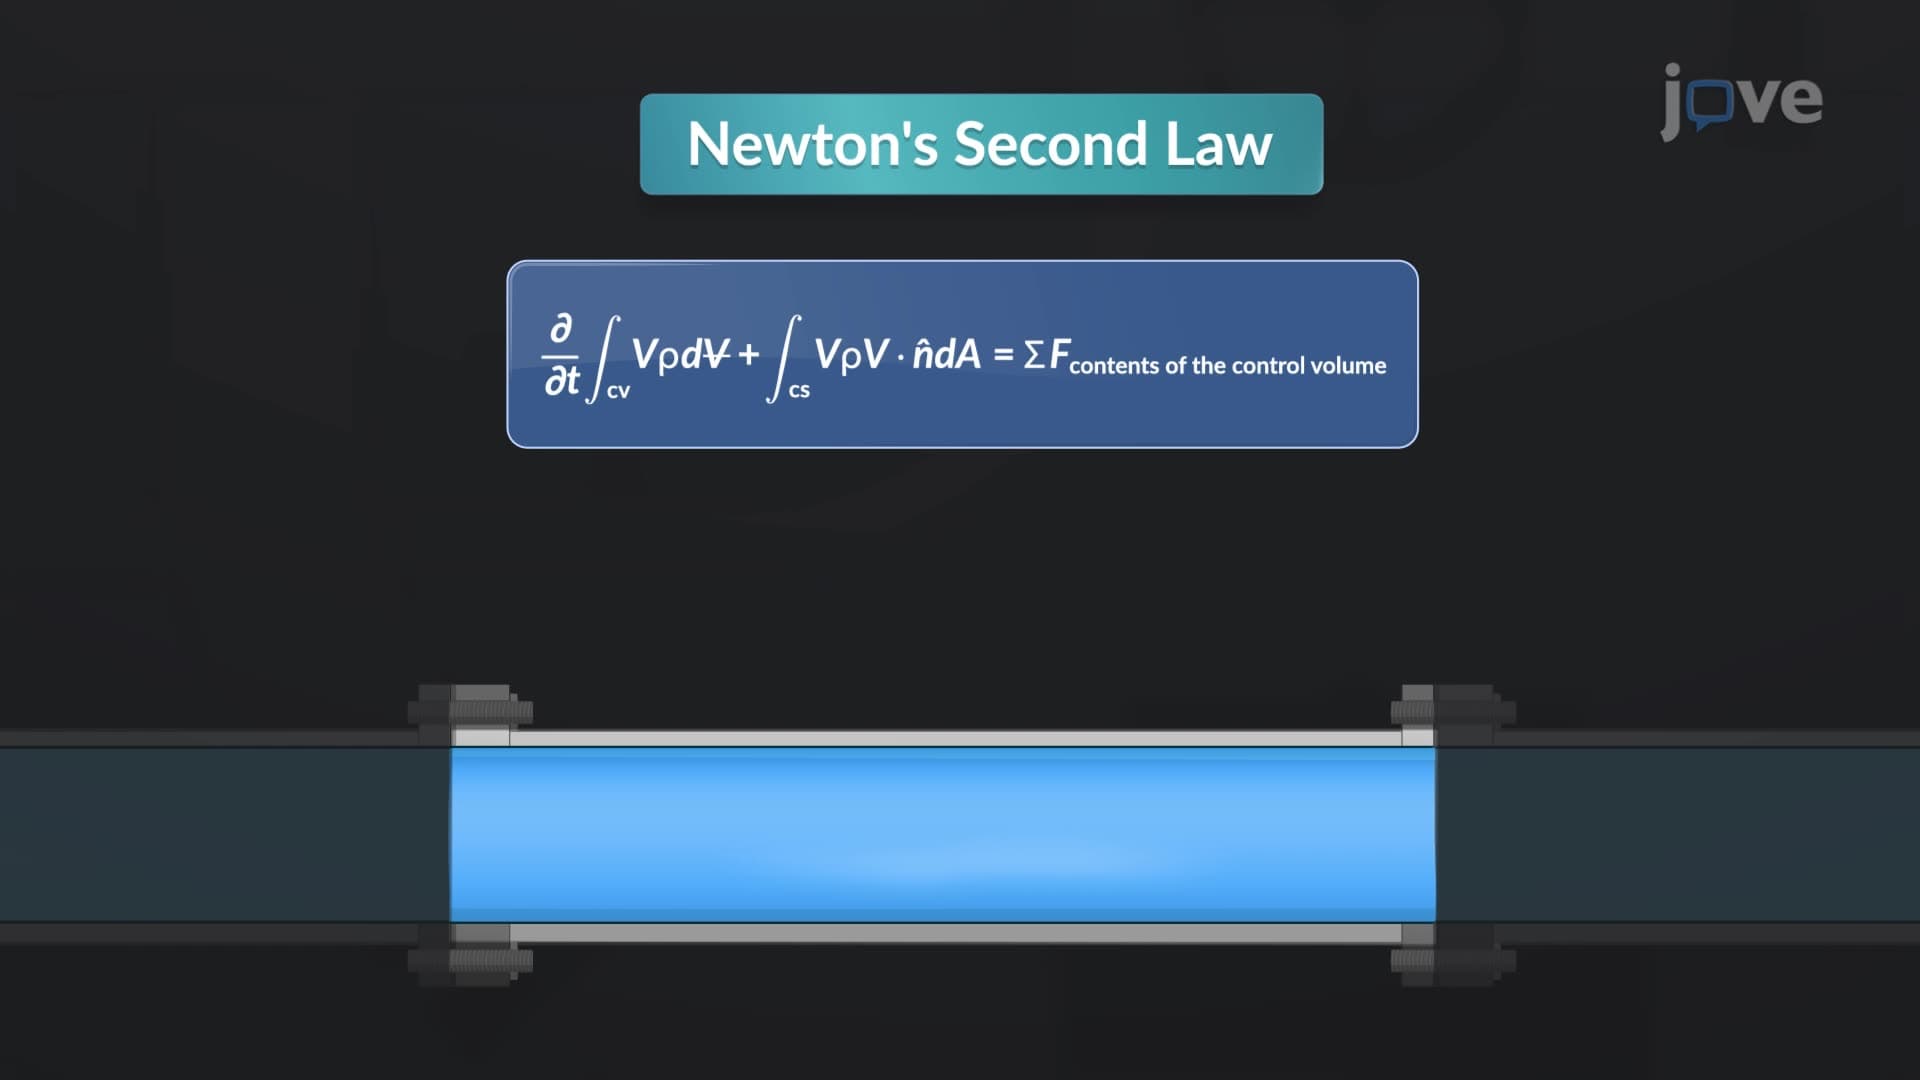
Linear Momentum in Control Volume