Sample entropy based prescribed performance control for tailless aircraft
Related Experiment Video
Updated: Sep 23, 2025
A Simple Flight Mill for the Study of Tethered Flight in Insects
Published on: December 10, 2015
Zihou He1, Jianbo Hu1, Yingyang Wang1
1Equipment Management and Unmanned Aerial Vehicle Engineering College, Air Force Engineering University, Xi'an, 710051, China.

Abstract:
This paper proposes a sample entropy (SampEn) based prescribed performance controller (SPPC) for the longitudinal control of a supersonic tailless aircraft subject to model uncertainty and nonlinearity. Considering that SampEn can evaluate the system's stability, a SampEn-based feedback adjust system (SFAS) is developed in this paper. With the help of SFAS, the SPPC could identify the dangerous chattering in the status signal that may lead the aircraft to lose control and make appropriate adjustments to feedback. Besides, the SPPC does not require any accurate model information and only needs to know the rough trend of dynamic functions. Although no adaptive or robust control mechanisms are introduced, the SPPC shows robustness against model uncertainty utilizing the nonlinear error feedback. Compared with traditional prescribed performance control (TPPC), the SPPC achieves better performance and safer flight. The whole control structure is developed through the backstepping technique, and the closed-loop stability is proved. At last, the advance of SPPC is verified via simulation using a high-fidelity tailless aircraft model, and the inner mechanisms of SPPC are further discussed.
Related Concept Videos
 01:15
Determination of Pi Terms
The theorem indicates that...
 01:10
Control Systems
At the heart...
 01:17
Turbine-Governor Control
 01:28
Load-frequency control
 01:23
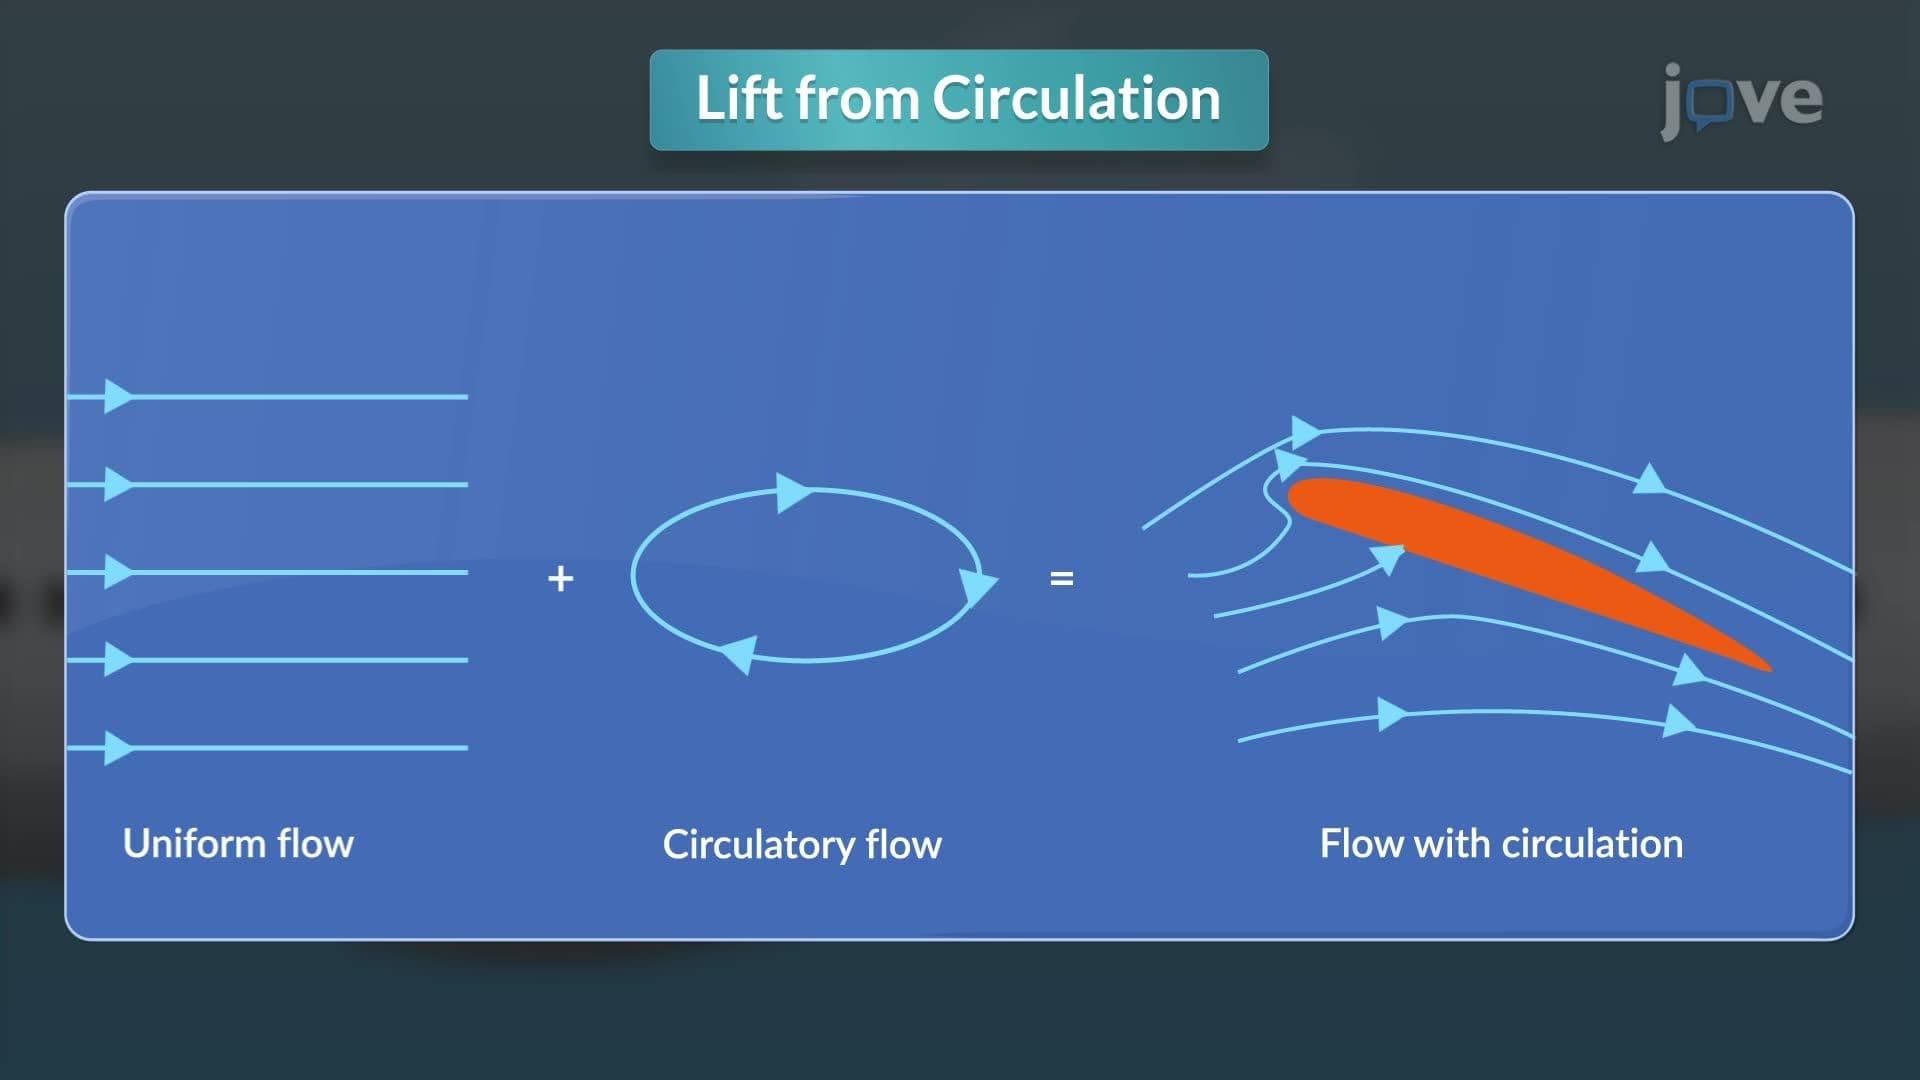
Lift
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...