Related Experiment Video
Updated: Sep 21, 2025
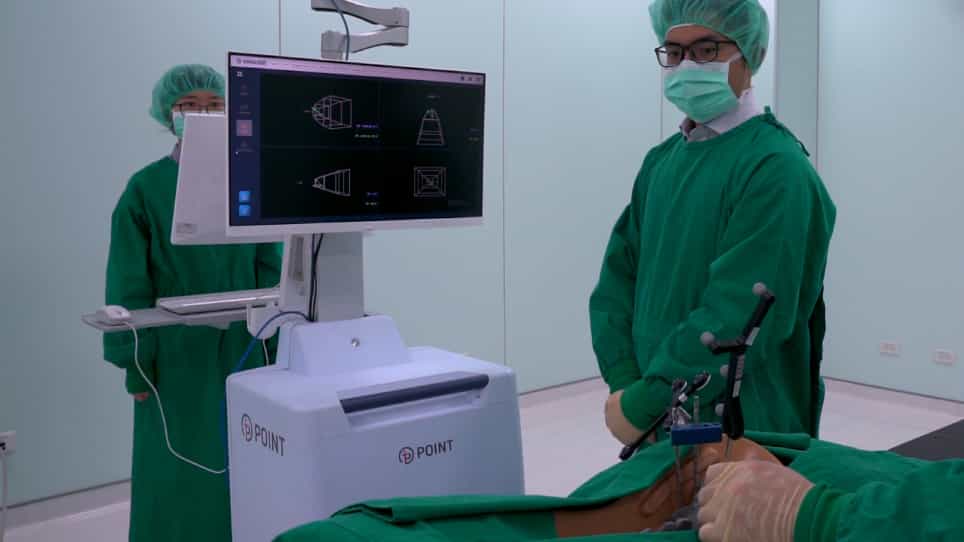

A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
An admittance-controlled amplified force tracking scheme for collaborative lumbar puncture surgical robot system
Hongbing Li1, Xun Nie2, Ding Duan2
1Department of Instrument Science and Engineering, and Shanghai Engineering Research Center for Intelligent Diagnosis and Treatment Instrument, School of Electronic Information and Electrical Engineering, Shanghai Jiao Tong University, Shanghai, China.

Background:
The accurate sensing and display of the delicate needle-tissue interaction force to the operator is desirable for needle insertion procedures. It not only plays a significant role in the surgical treatment effect, but also has a great significance in improving surgical safety and reducing the incidence of complications. However, the direct detection of the interaction force between the tissue and needle tip by placement of a force sensor is challenging owing to the constraints of miniaturisation, cost, and sterilisation.
Methods:
In this study, a new position-based force-to-motion controller with magnified force feedback is presented to provide augmented force perception to the operator during needle insertion on the soft tissue. Furthermore, the demonstration to the position-based low level motion controller is more suitable for needle insertion surgical requirements in the cooperative robotic system.
Results:
The proposed controller was experimentally validated by a collaborative lumbar puncture robotics system. Additionally, to provide hand tremor rejection for the stable manipulation of the puncture needle, it was demonstrated that the proposed amplified feedback force controller allowed a safer object interaction with the robotic needle insertion assistance.
Conclusions:
The results of the experiment show that a desirable interaction force profile is perceived by the operator during the overall insertion task operation. The admittance gain for the simplified admittance controller has a significant impact on the operator's ability to accurately control the applied force.