Related Experiment Video
Updated: Sep 7, 2025
Flapping Soft Fin Deformation Modeling using Planar Laser-Induced Fluorescence Imaging
Published on: April 28, 2022
Motion mechanism and thrust characteristics of amphibious robots with long fin fluctuation for propulsion on hard
Jian Zhang1, Junjie Zhou1,2, Shihua Yuan1
1National Key Laboratory of Vehicular Transmission, Beijing Institute of Technology, Beijing 100081, People's Republic of China.

Abstract:
This paper presents the principle of motion, mechanical modeling and key characteristics of the propulsive force of a new flexible-fin traveling wave propulsion mechanism used in an amphibious robot. Firstly, the form of motion and the basic propulsion principle of traveling wave propulsion of flexible fins on the ground are described. During fluctuation of the flexible fins, the relative motion between the outermost contact line on the fin surface and the ground generates the propulsive force of forward motion and the lateral force along the fin surface. Based on the laws of flexible-fin fluctuation kinematics and the basic principles of friction mechanics, the propulsion mechanics model of flexible fins during traveling wave propulsion on the ground is established. By numerically solving the propulsive force equation, the relationship between the propulsive force of the flexible fin and the motion parameters of the fin surface can be obtained. Numerical calculations combined with the results of experimental tests reveal that the flexible-fin propulsive force shows periodic variations within one fluctuation period of the fin surface, and the variation period is related to the number of waves present on the fin surface. The wavenumber on the fin surface has a large impact on the fluctuation amplitude of the propulsive force. In the range of 1.6-1.9 waves on the fin surface, the average propulsive force is the most ideal, while in the range of fin-surface inclinations less than 50° and fluctuation amplitudes greater than 30°, the propulsive force of the flexible fin is the ideal parameter range. This research provides theoretical support for the design of a flexible-fin traveling wave propulsion mechanism.
Related Concept Videos
 01:11
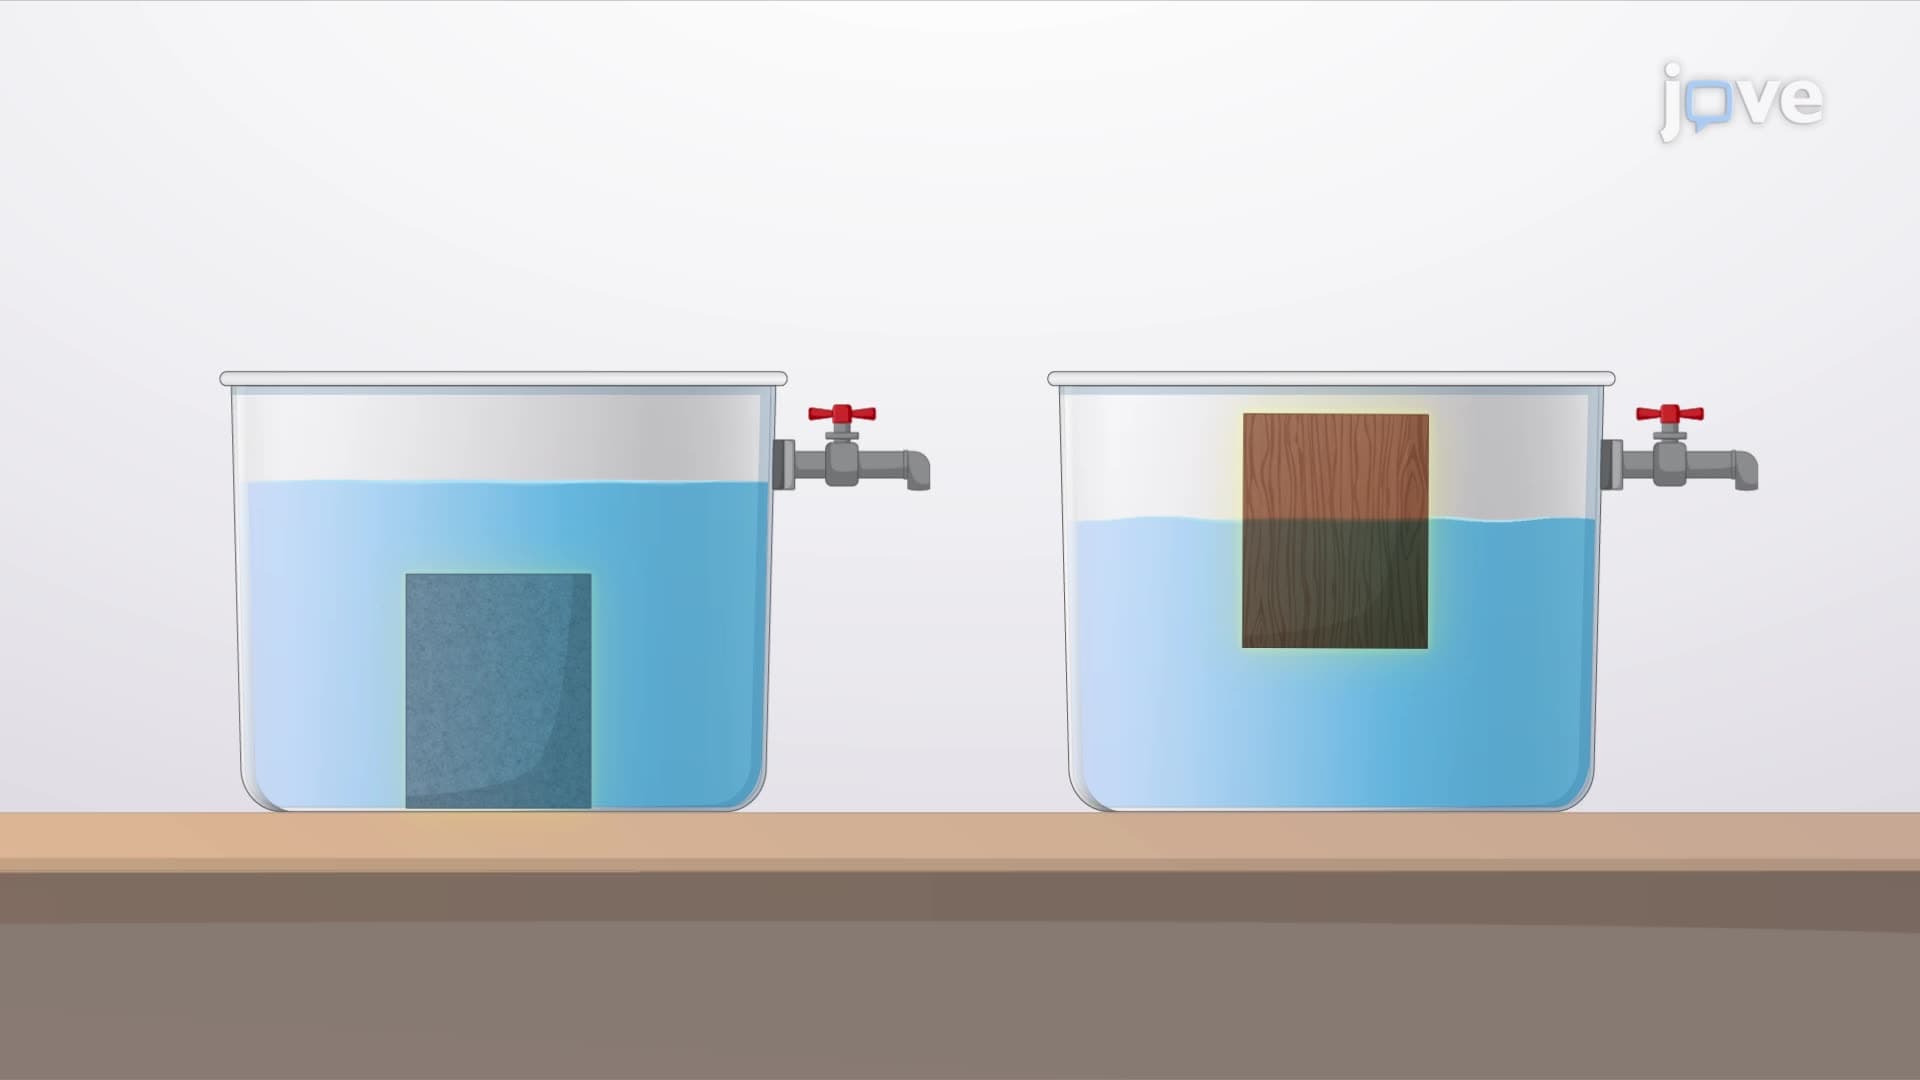
Buoyancy and Stability for Submerged and Floating Bodies
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:30
Typical Model Studies
 01:05
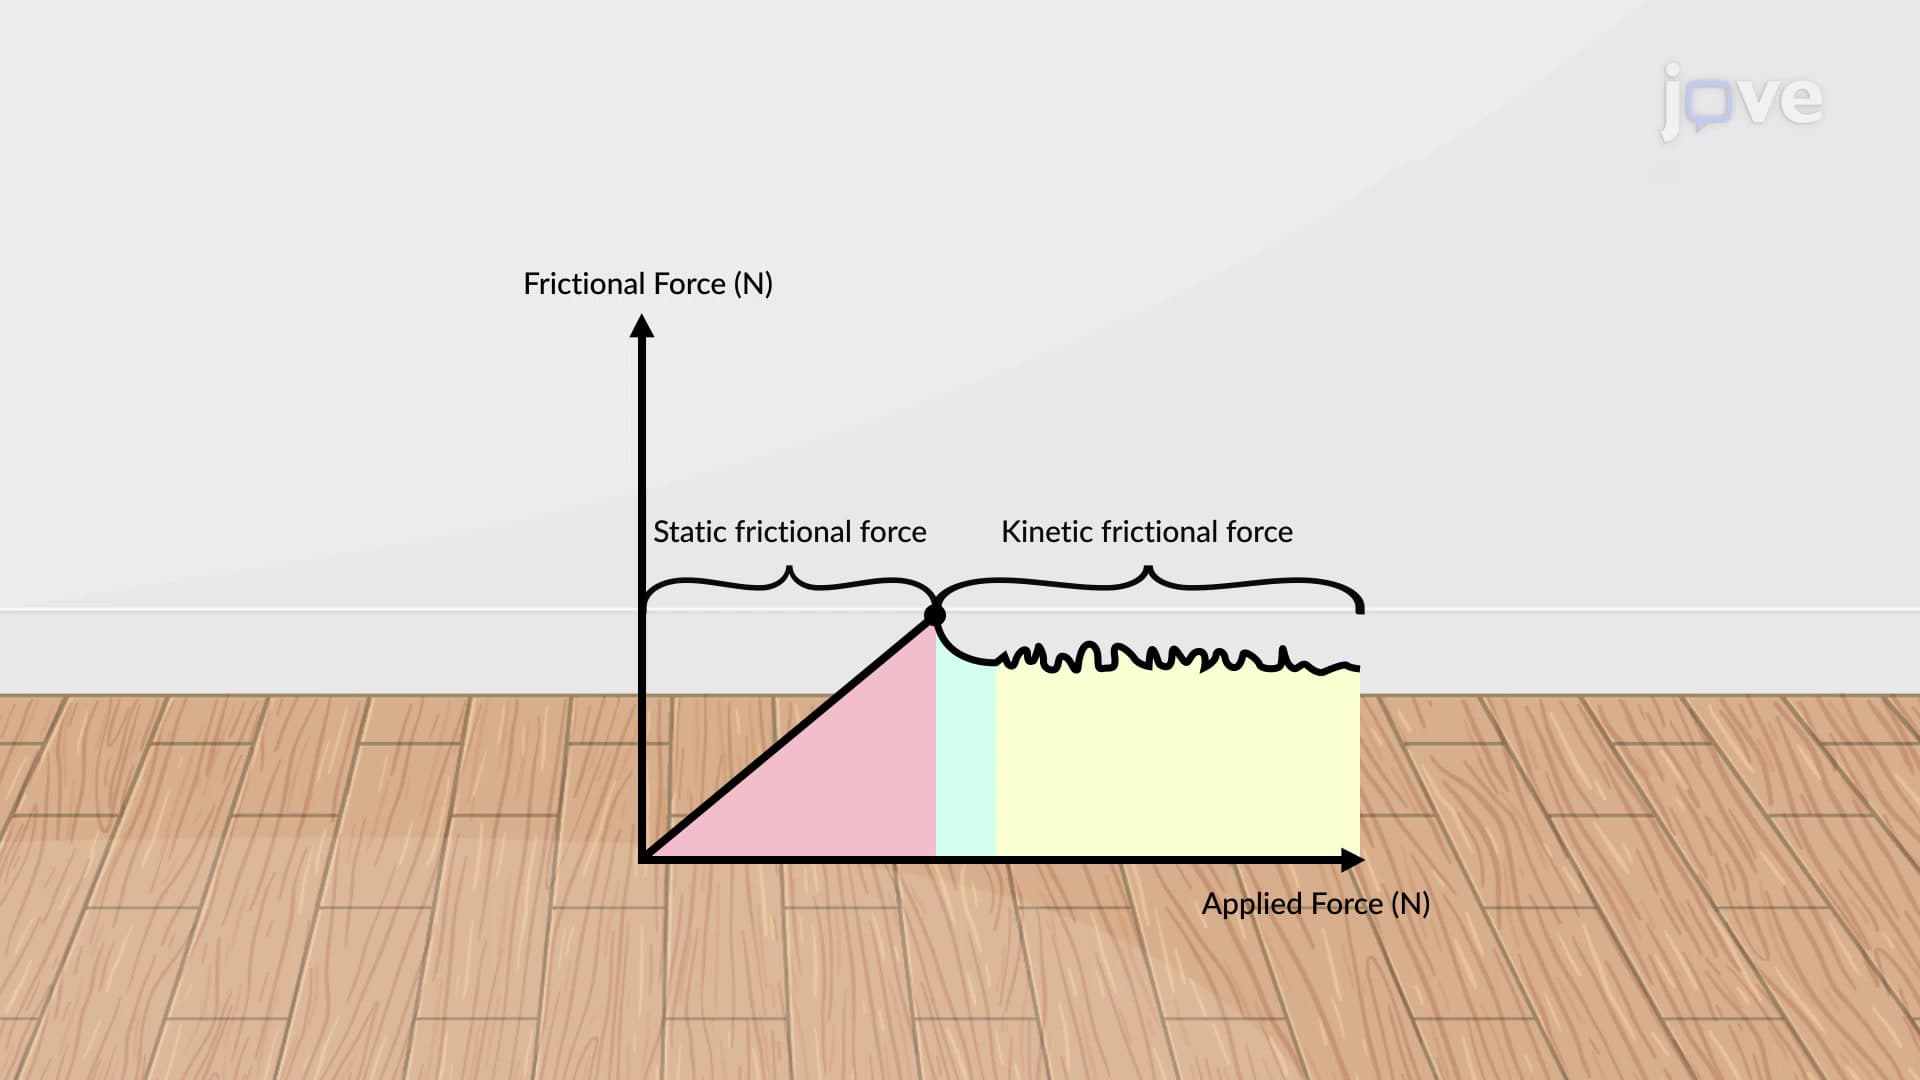
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:16
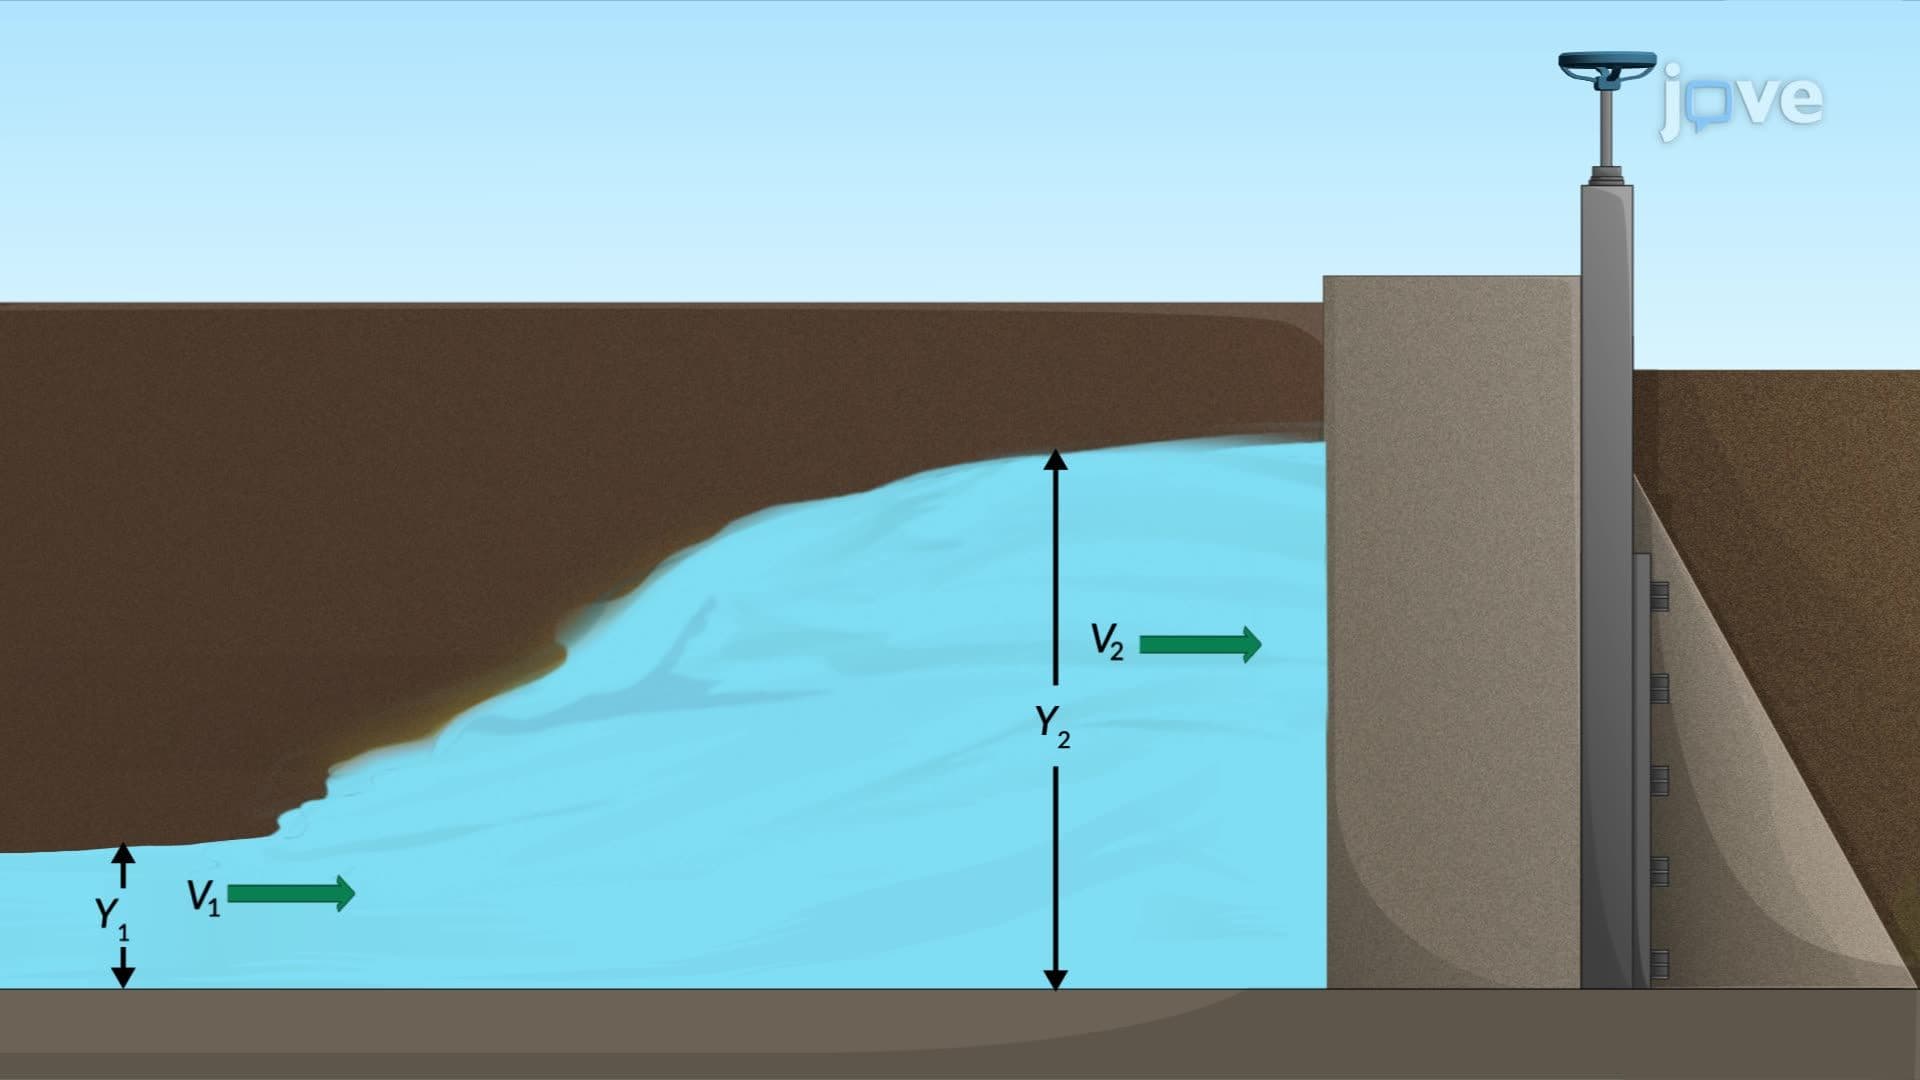
Hydraulic Jump: Problem Solving
 01:39
Mechanism of Filopodia Formation
Their main function is to guide migrating cells during normal tissue morphogenesis or cancer metastasis by recognizing and making initial contacts with the extracellular matrix. However, they can also act as stationary cell anchors or help to establish communication...