Related Experiment Video
Updated: Sep 5, 2025


A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Global fixed-time trajectory tracking control of underactuated USV based on fixed-time extended state observer
Yunsheng Fan1, Bingbing Qiu1, Lei Liu1
1College of Marine Electrical Engineering, Dalian Maritime University, Dalian 116026, China.

Abstract:
This paper studies the trajectory tracking problem of unmanned surface vehicle subject to unmeasurable velocities and unknown disturbances. By combining a fixed-time extended state observer (FESO) and a fixed-time differentiator, a fixed-time sliding mode control (FTSMC) law is proposed, in which a saturation function is adopted to make the terminal sliding mode surface leave the singularity area. The value of this paper can be described: first, this paper designs a novel guidance law that can converge in a fixed time to reduce the convergence time of the error. Then, unmeasurable velocities and lumped disturbances are estimated by applying a FESO. Meanwhile, a fixed-time differentiator is used to obtain real-time differential signals, thus reducing the difficulty of controller design. Subsequently, a novel auxiliary dynamic system is designed to address actuator saturation. According to Lyapunov's theory, the entire closed-loop control system has uniformly global fixed-time stability (UGFTS). The superiority of the designed controller is demonstrated through numerical simulations.
Related Concept Videos
 01:21
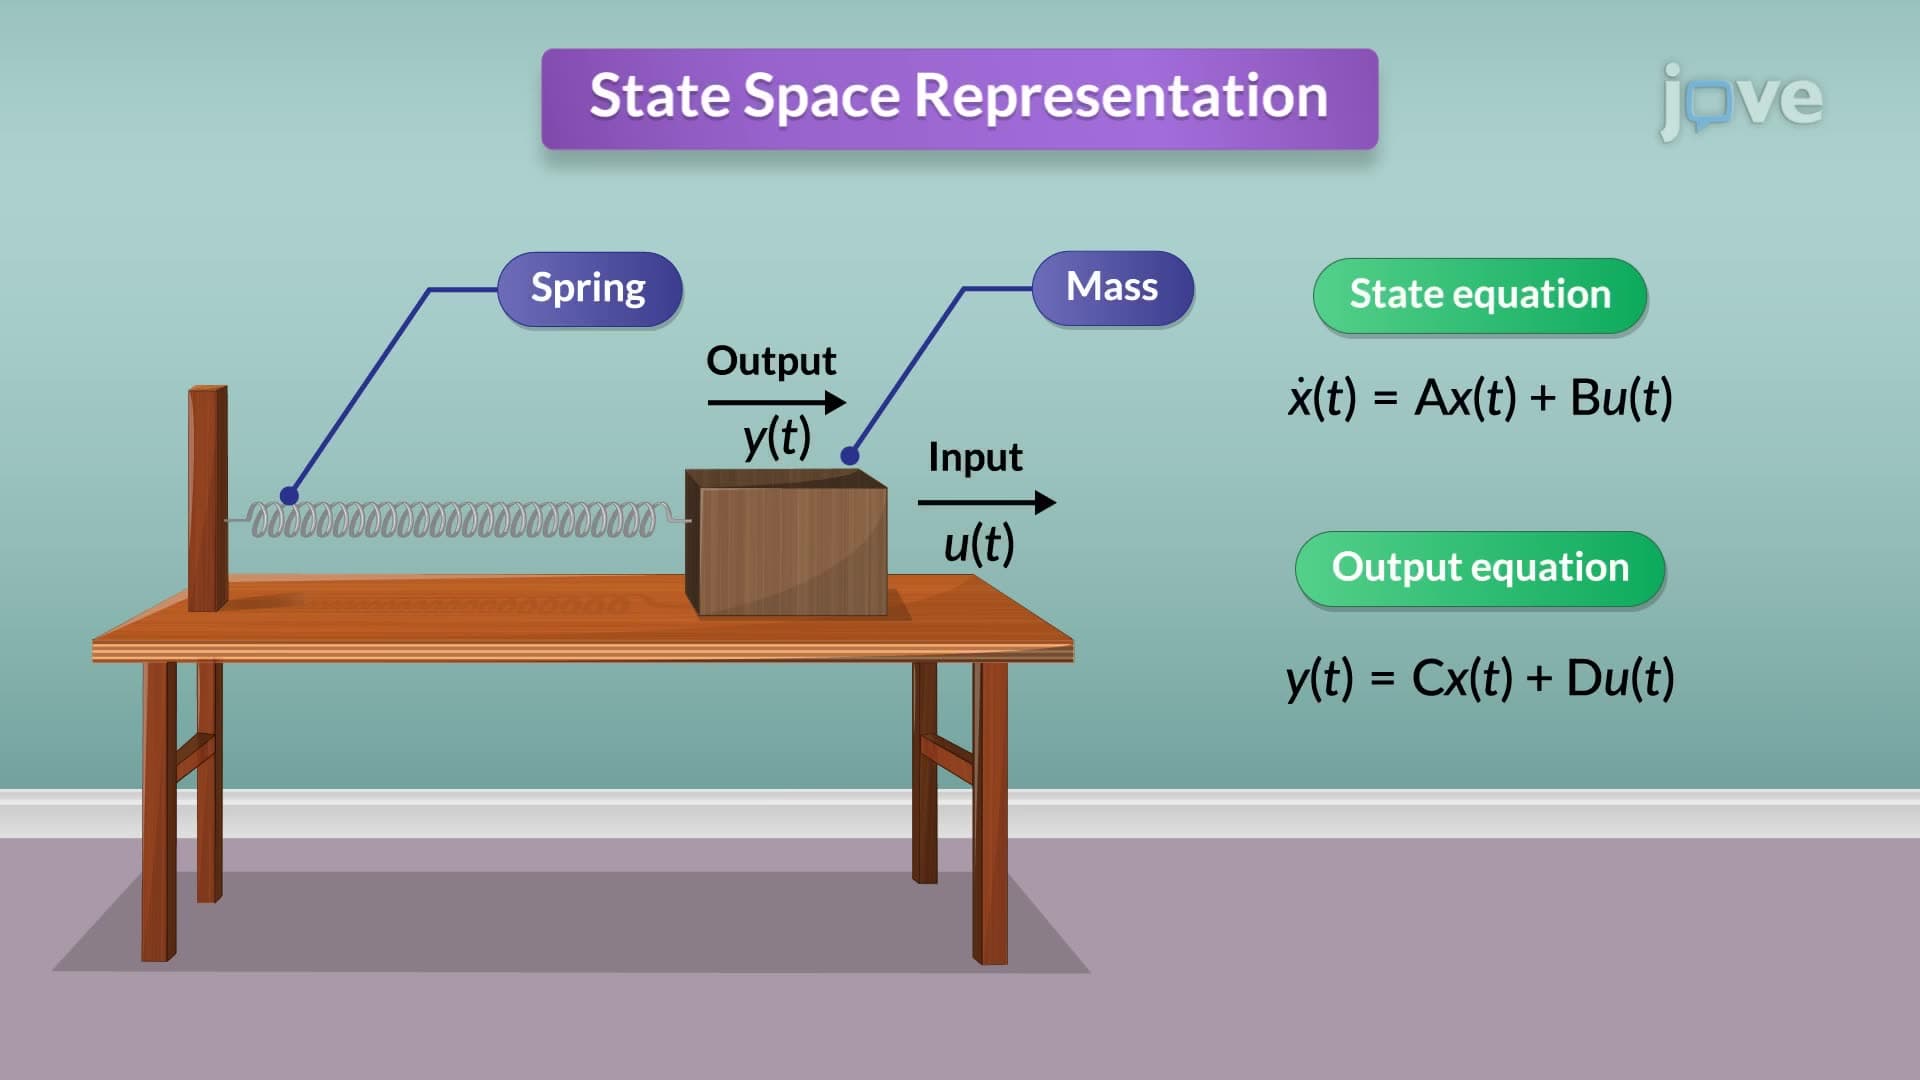
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:15
Kinematic Equations: Problem Solving
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...