Related Experiment Video
Updated: Sep 1, 2025
Automating Citrus Budwood Processing for Downstream Pathogen Detection Through Instrument Engineering
Published on: April 21, 2023
Detection and localization of citrus fruit based on improved You Only Look Once v5s and binocular vision in the
Chaojun Hou1, Xiaodi Zhang1, Yu Tang2
1Academy of Contemporary Agriculture Engineering Innovations, Zhongkai University of Agriculture and Engineering, Guangzhou, China.

Abstract:
Intelligent detection and localization of mature citrus fruits is a critical challenge in developing an automatic harvesting robot. Variable illumination conditions and different occlusion states are some of the essential issues that must be addressed for the accurate detection and localization of citrus in the orchard environment. In this paper, a novel method for the detection and localization of mature citrus using improved You Only Look Once (YOLO) v5s with binocular vision is proposed. First, a new loss function (polarity binary cross-entropy with logit loss) for YOLO v5s is designed to calculate the loss value of class probability and objectness score, so that a large penalty for false and missing detection is applied during the training process. Second, to recover the missing depth information caused by randomly overlapping background participants, Cr-Cb chromatic mapping, the Otsu thresholding algorithm, and morphological processing are successively used to extract the complete shape of the citrus, and the kriging method is applied to obtain the best linear unbiased estimator for the missing depth value. Finally, the citrus spatial position and posture information are obtained according to the camera imaging model and the geometric features of the citrus. The experimental results show that the recall rates of citrus detection under non-uniform illumination conditions, weak illumination, and well illumination are 99.55%, 98.47%, and 98.48%, respectively, approximately 2-9% higher than those of the original YOLO v5s network. The average error of the distance between the citrus fruit and the camera is 3.98 mm, and the average errors of the citrus diameters in the 3D direction are less than 2.75 mm. The average detection time per frame is 78.96 ms. The results indicate that our method can detect and localize citrus fruits in the complex environment of orchards with high accuracy and speed. Our dataset and codes are available at https://github.com/AshesBen/citrus-detection-localization.
More Related Videos
 09:23
Specific and Accurate Detection of the Citrus Greening Pathogen Candidatus liberibacter spp. Using Conventional PCR on Citrus Leaf Tissue Samples
Published on: June 29, 2018
 09:03
Field-Deployable Candidatus Liberibacter asiaticus Detection Using Recombinase Polymerase Amplification Combined with CRISPR-Cas12a
Published on: December 23, 2022
Related Concept Videos
 02:16
Light Acquisition
 01:58
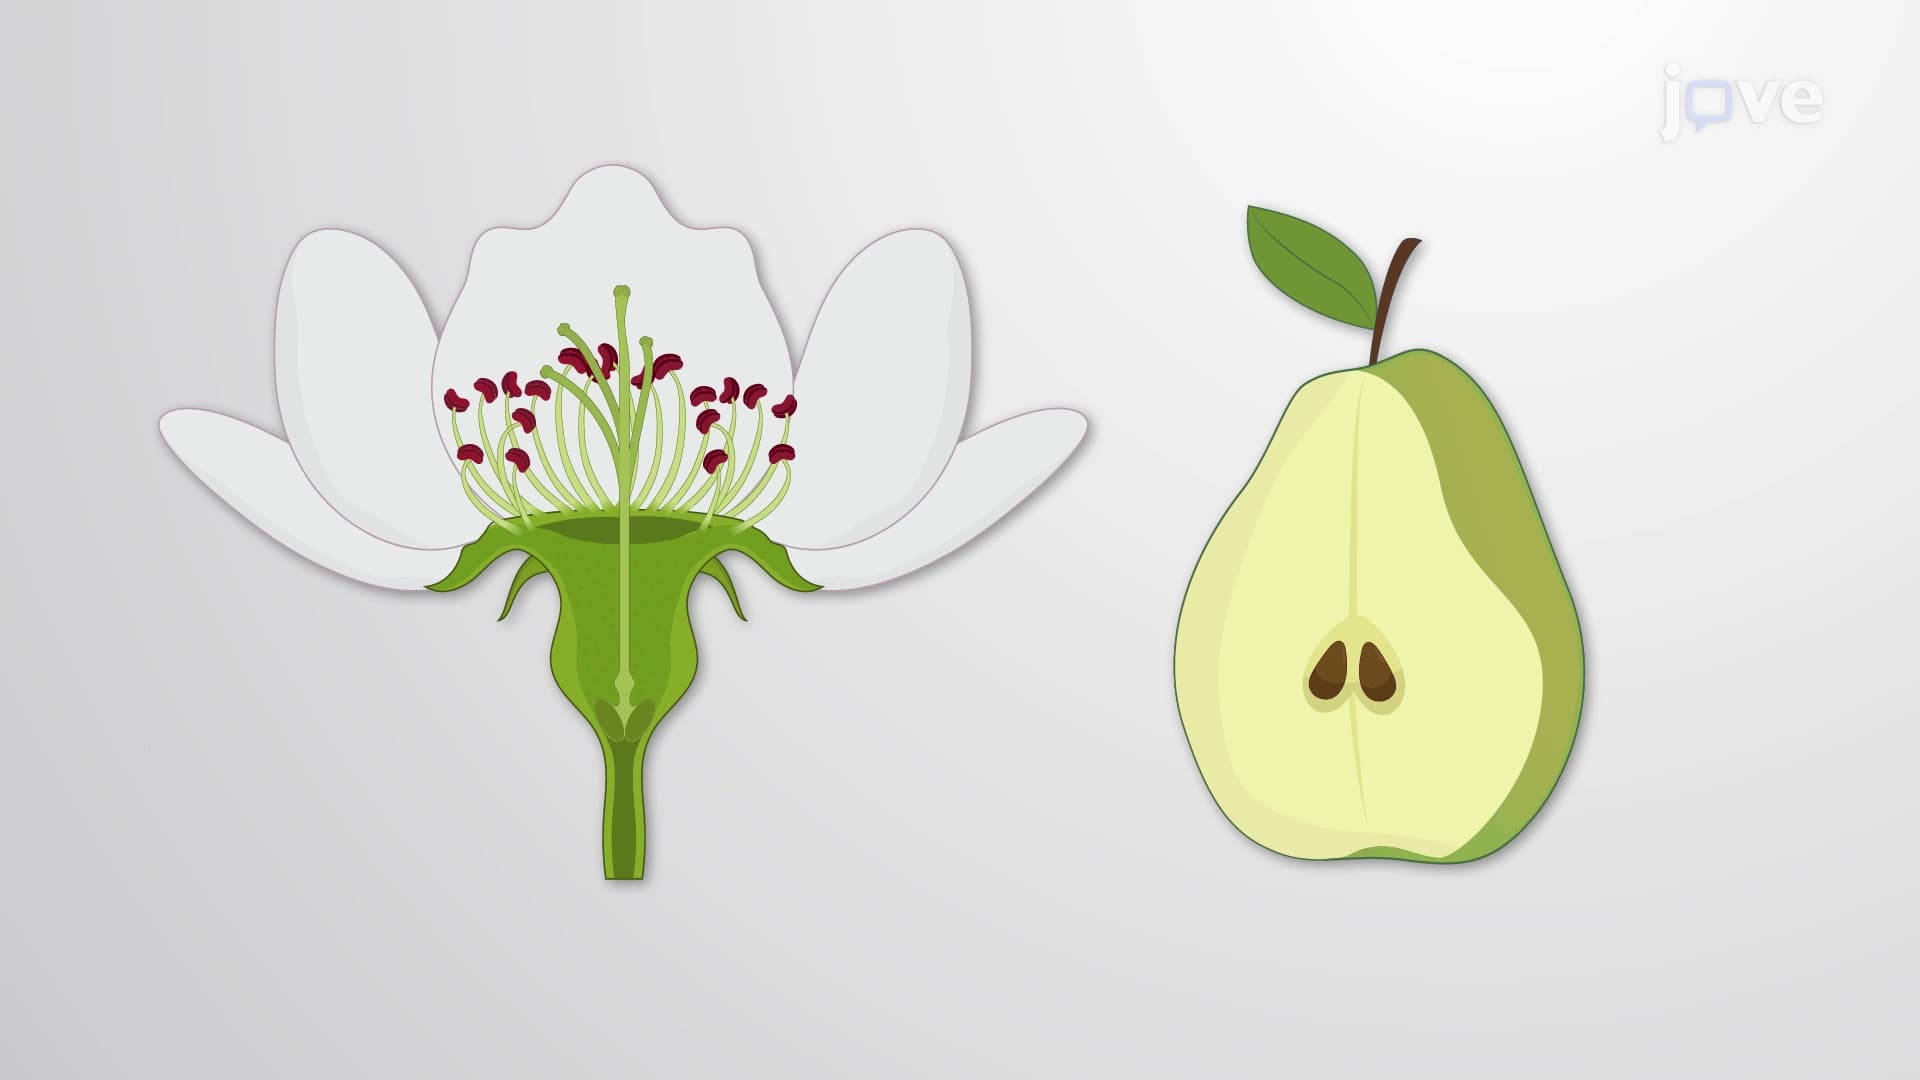
Fruit Development, Structure, and Function
 02:35
Key Elements for Plant Nutrition
 01:18
Imaging Biological Samples with Optical Microscopy
In optical microscopy, the specimen to be viewed is placed on a glass slide and clipped on the stage...
 02:00
Photoreceptors and Plant Responses to Light
 01:03
IR Frequency Region: Fingerprint Region