Related Experiment Video
Updated: Aug 29, 2025
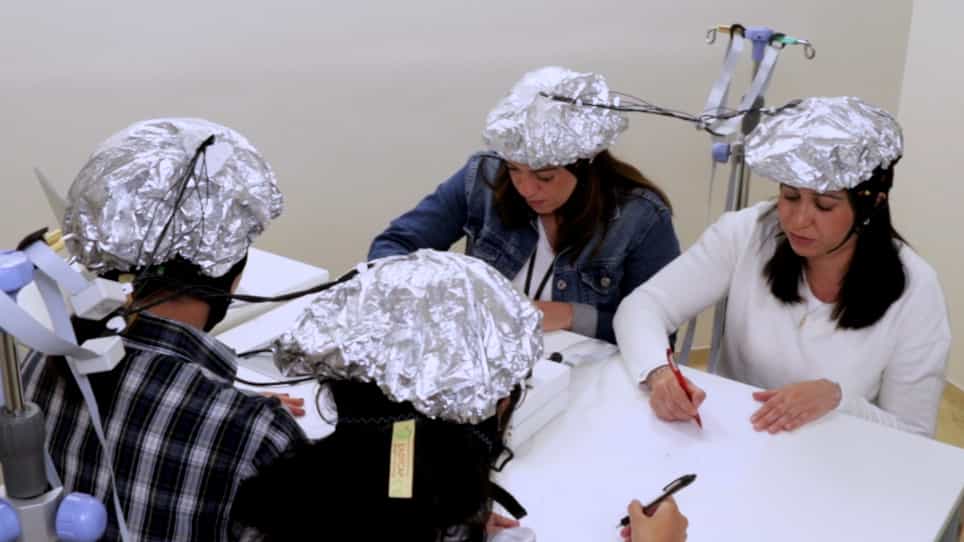
Group Synchronization During Collaborative Drawing Using Functional Near-Infrared Spectroscopy
Published on: August 5, 2022
Distributed robust group output synchronization control for heterogeneous uncertain linear multi-agent systems
Jie Zhang1, Da-Wei Ding2, Yingying Ren2
1School of Automation and Electrical Engineering, University of Science and Technology Beijing, Beijing 100083, China; School of Electronics and Information Engineering, Taiyuan University of Science and Technology, Taiyuan, 030024, China.

Abstract:
This paper investigates the distributed robust group output synchronization problem of heterogeneous uncertain linear leader-follower multi-agent systems (MASs), whose followers have nonidentical and parameter uncertain dynamics. To achieve cooperative tracking with multiple targets, a new group synchronization framework based upon the output regulation technique is established. In the underlying directed communication topology, all nonidentical followers are divided into several subgroups. Meanwhile, each subgroup has its output tracking objective generated by an autonomous exosystem which is seen as the leader of each subgroup. Since not all followers can access their exosystems directly, the distributed exosystem observer based on the algebraic Riccati inequality (ARI) is designed to obtain the information of exosystems. Moreover, to compensate for parameter uncertainties for different group topologies, the p-copy internal model is synthesized into distributed control laws, i.e., dynamic state feedback control protocol under an acyclic directed graph and dynamic output feedback control protocol under a general directed graph. It is shown that group synchronization can be respectively achieved with these controllers under acyclic and general partitions regardless of parameter uncertainties. Finally, some examples are provided to verify the validity of the analytic results.


Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:21
Distributed Loads: Problem Solving
 01:10
Propagation of Uncertainty from Systematic Error
 01:25
Distribution Reliability and Automation
 01:22
Multi-input and Multi-variable systems
In the absence...