Related Experiment Video
Updated: Aug 29, 2025

Taking Advantage of Reduced Droplet-surface Interaction to Optimize Transport of Bioanalytes in Digital Microfluidics
Published on: November 10, 2014
On-demand, remote and lossless manipulation of biofluid droplets
Wei Wang1,2, Jiefeng Sun3, Sravanthi Vallabhuneni1
1Department of Mechanical and Aerospace Engineering, North Carolina State University, Raleigh, NC, 27695, USA. akota2@ncsu.edu.

Abstract:
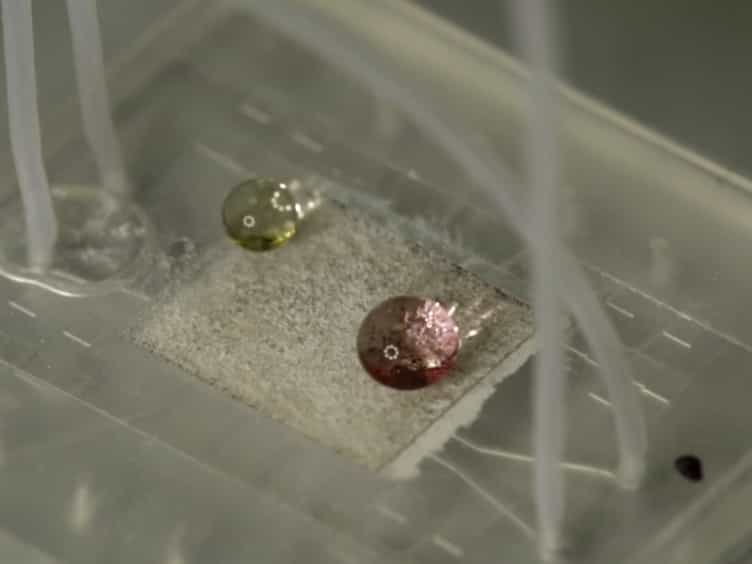
The recent global outbreaks of epidemics and pandemics have shown us that we are severely under-prepared to cope with infectious agents. Exposure to infectious agents present in biofluids (e.g., blood, saliva, urine etc.) poses a severe risk to clinical laboratory personnel and healthcare workers, resulting in hundreds of millions of hospital-acquired and laboratory-acquired infections annually. Novel technologies that can minimize human exposure through remote and automated handling of infectious biofluids will mitigate such risk. In this work, we present biofluid manipulators, which allow on-demand, remote and lossless manipulation of virtually any liquid droplet. Our manipulators are designed by integrating thermo-responsive soft actuators with superomniphobic surfaces. Utilizing our manipulators, we demonstrate on-demand, remote and lossless manipulation of biofluid droplets. We envision that our biofluid manipulators will not only reduce manual operations and minimize exposure to infectious agents, but also pave the way for developing inexpensive, simple and portable robotic systems, which can allow point-of-care operations, particularly in developing nations.
Insights
New biofluid manipulators reduce infection risk for healthcare workers. These devices enable remote, automated handling of infectious liquids, minimizing manual operations and enabling point-of-care diagnostics.
Area of Science:
- Biotechnology
- Robotics
- Materials Science
Background:
- Global epidemics highlight inadequate preparedness for infectious agents.
- Healthcare workers face high risks from handling infectious biofluids, leading to millions of infections annually.
- Minimizing human exposure through automated technologies is crucial for mitigating infection risks.
Purpose of the Study:
- To develop novel biofluid manipulators for remote and automated handling of liquid droplets.
- To reduce manual operations and minimize healthcare worker exposure to infectious agents.
- To enable development of inexpensive, portable robotic systems for point-of-care diagnostics.
Main Methods:
- Integration of thermo-responsive soft actuators with superomniphobic surfaces.
- Design of manipulators for on-demand, remote, and lossless liquid droplet handling.
- Demonstration of biofluid droplet manipulation using the developed system.
Main Results:
- Successful on-demand, remote, and lossless manipulation of biofluid droplets was achieved.
- The developed manipulators effectively handle various liquid droplets.
- The technology shows potential for reducing manual operations and infection exposure.
Conclusions:
- Biofluid manipulators offer a novel solution for safe handling of infectious materials.
- This technology can significantly reduce hospital-acquired and laboratory-acquired infections.
- The manipulators pave the way for affordable, portable robotic systems for point-of-care applications, especially in developing nations.