Related Experiment Video
Updated: Aug 28, 2025

Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
Linear quadratic regulator design via metaheuristics applied to the damping of low-frequency oscillations in power
Luis Carvalho1, Jozias R L Neto1, Jefferson C Rezende1
1Department of Engineering and Technology, Federal Rural University of the Semi-Arid Region, Rua Francisco Mota 572, Pres. Costa e Silva, 59625-900 Mossoró, RN, Brazil.

Abstract:
This paper proposes the application of control by state feedback using the linear quadratic regulator (LQR) optimized by metaheuristics to damp low-frequency electromechanical oscillations in electrical power systems. The current sensitivity model was used to represent the single machine infinite bus (SMIB) system in the time domain. The weighting matrices of the LQR were adjusted using four different algorithms: (i) the genetic algorithm, (ii) the differential evolution algorithm, (iii) the particle swarm optimization algorithm, and (iv) the gray wolf optimization (GWO) algorithm. In the cases considered, disturbances were applied to the electrical power system and, then, performances comparisons associated with each metaheuristic were statistically analyzed, in which the number of iterations, error, and time to achieve convergence of each algorithm were compared. From the results, it was possible to conclude that the algorithms were efficient in adjusting the weighting matrices of the LQR, providing additional damping to the poles of interest of the system. It was also possible to conclude that the GWO algorithm presented the best performance, accrediting it as a powerful tool in the study of small-signal stability for the analyzed case.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 06:04
Experimental Investigation of the Hierarchical Control in DC Microgrids Using a Real-time Simulator
Published on: February 14, 2025
Related Concept Videos
 01:17
Design Example: Underdamped Parallel RLC Circuit
Starting with a fixed...
 01:30
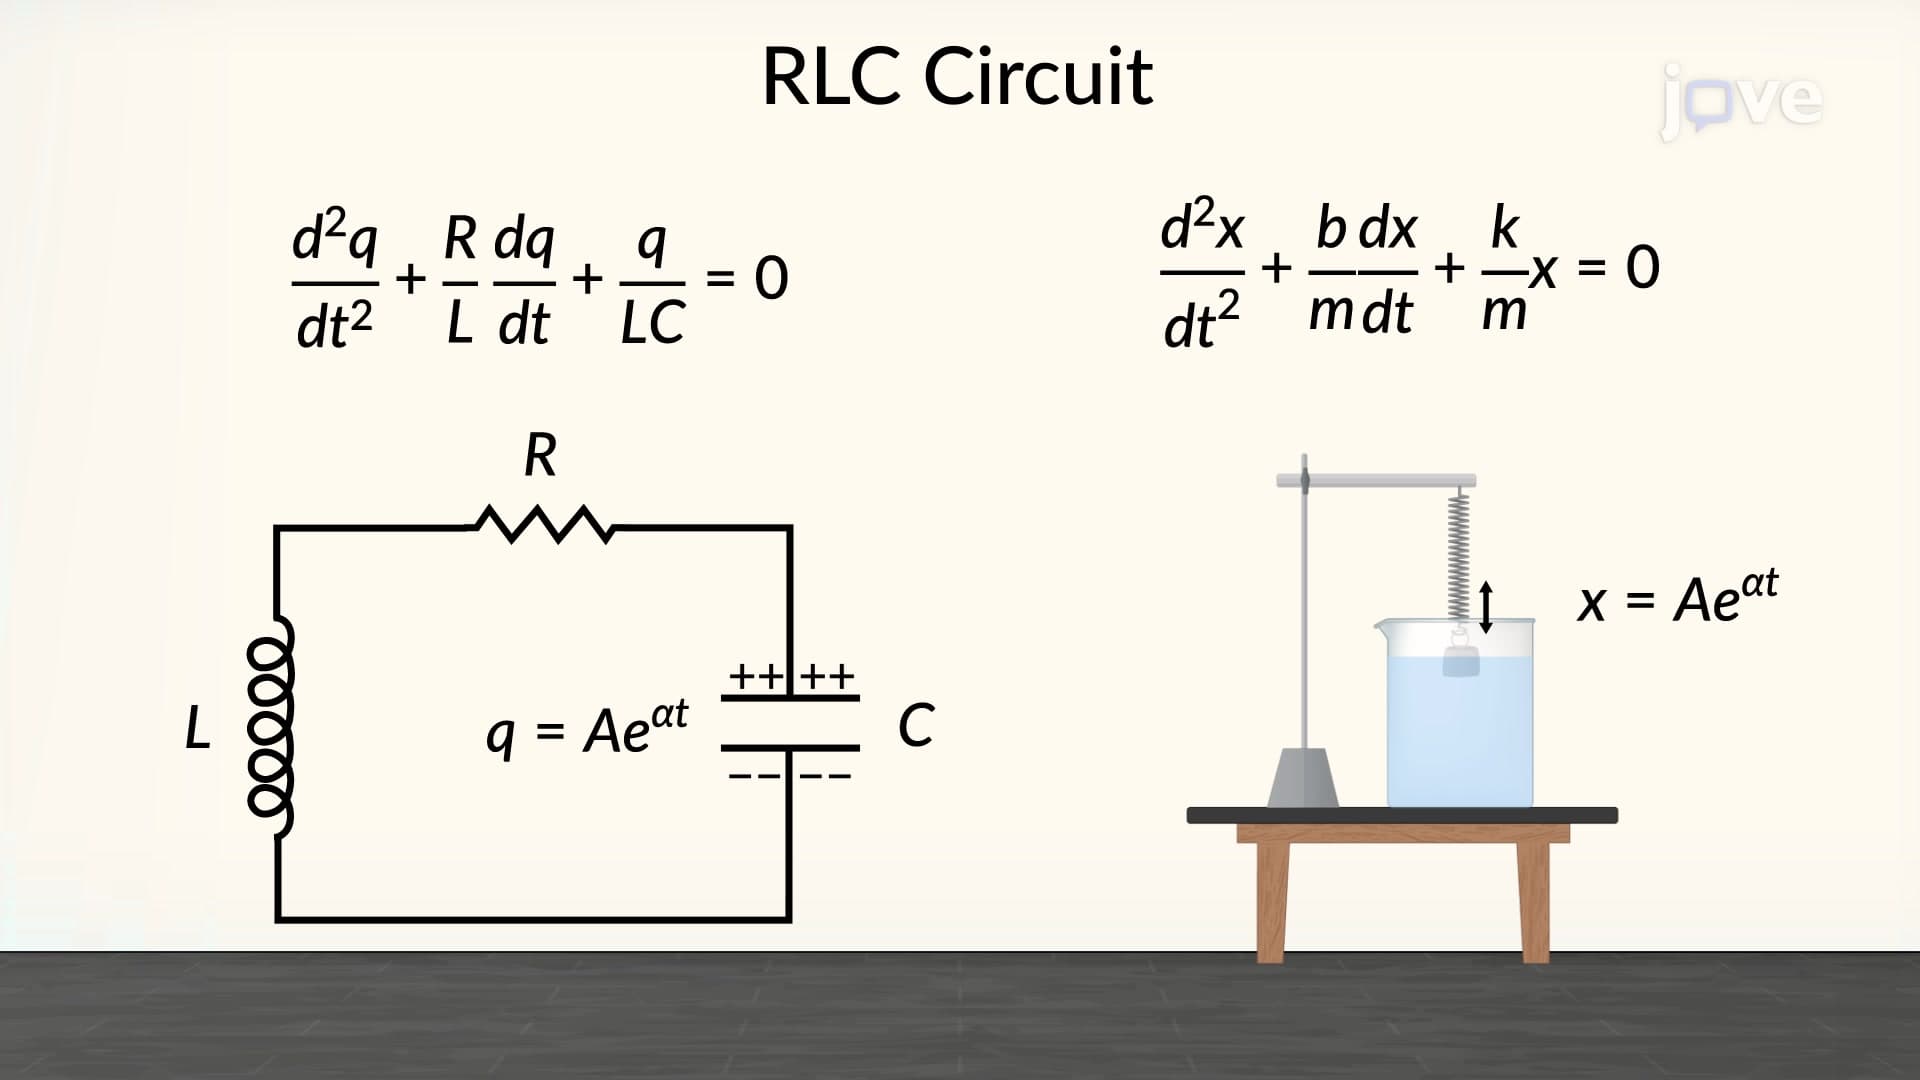
RLC Circuit as a Damped Oscillator
Consider a series RLC circuit. Here, the presence of resistance in the circuit leads to energy loss due to joule heating in the resistance. Therefore, the total electromagnetic energy in the circuit is no longer constant and decreases with time. Since the magnitude of charge, current, and potential difference continuously decreases, their oscillations are said to be damped. This is...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:19
Second-order Op Amp Circuits
The analysis of such circuits follows a systematic approach, similar to the second-order RLC circuits. In practical scenarios, bulky inductors are rarely employed due to their size and weight. This means...
 01:18
Second Order systems II
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...