Related Experiment Video
Updated: Aug 27, 2025
Quantifying Learning in Young Infants: Tracking Leg Actions During a Discovery-learning Task
Published on: June 1, 2015
A path planning approach for mobile robots using short and safe Q-learning
He Du1, Bing Hao1, Jianshuo Zhao1
1College of Computer and Control Engineering, Qiqihar University, Qiqihar, China.

Abstract:
Path planning is a major challenging problem for mobile robots, as the robot is required to reach the target position from the starting position while simultaneously avoiding conflicts with obstacles. This paper refers to a novel method as short and safe Q-learning to alleviate the short and safe path planning task of mobile robots. To solve the slow convergence of Q-learning, the artificial potential field is utilized to avoid random exploration and provides a priori knowledge of the environment for mobile robots. Furthermore, to speed up the convergence of the Q-learning and reduce the computing time, a dynamic reward is proposed to facilitate the mobile robot towards the target point. The experiments are divided into two parts: short and safe path planning. The mobile robot can reach the target with the optimal path length in short path planning, and away from obstacles in safe path planning. Experiments compared with the state-of-the-art algorithm demonstrate the effectiveness and practicality of the proposed approach. Concluded, the path length, computing time and turning angle of SSQL is increased by 2.83%, 23.98% and 7.98% in short path planning, 3.64%, 23.42% and 12.61% in safe path planning compared with classical Q-learning. Furthermore, the SSQL outperforms other optimization algorithms with shorter path length and smaller turning angles.


Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:11
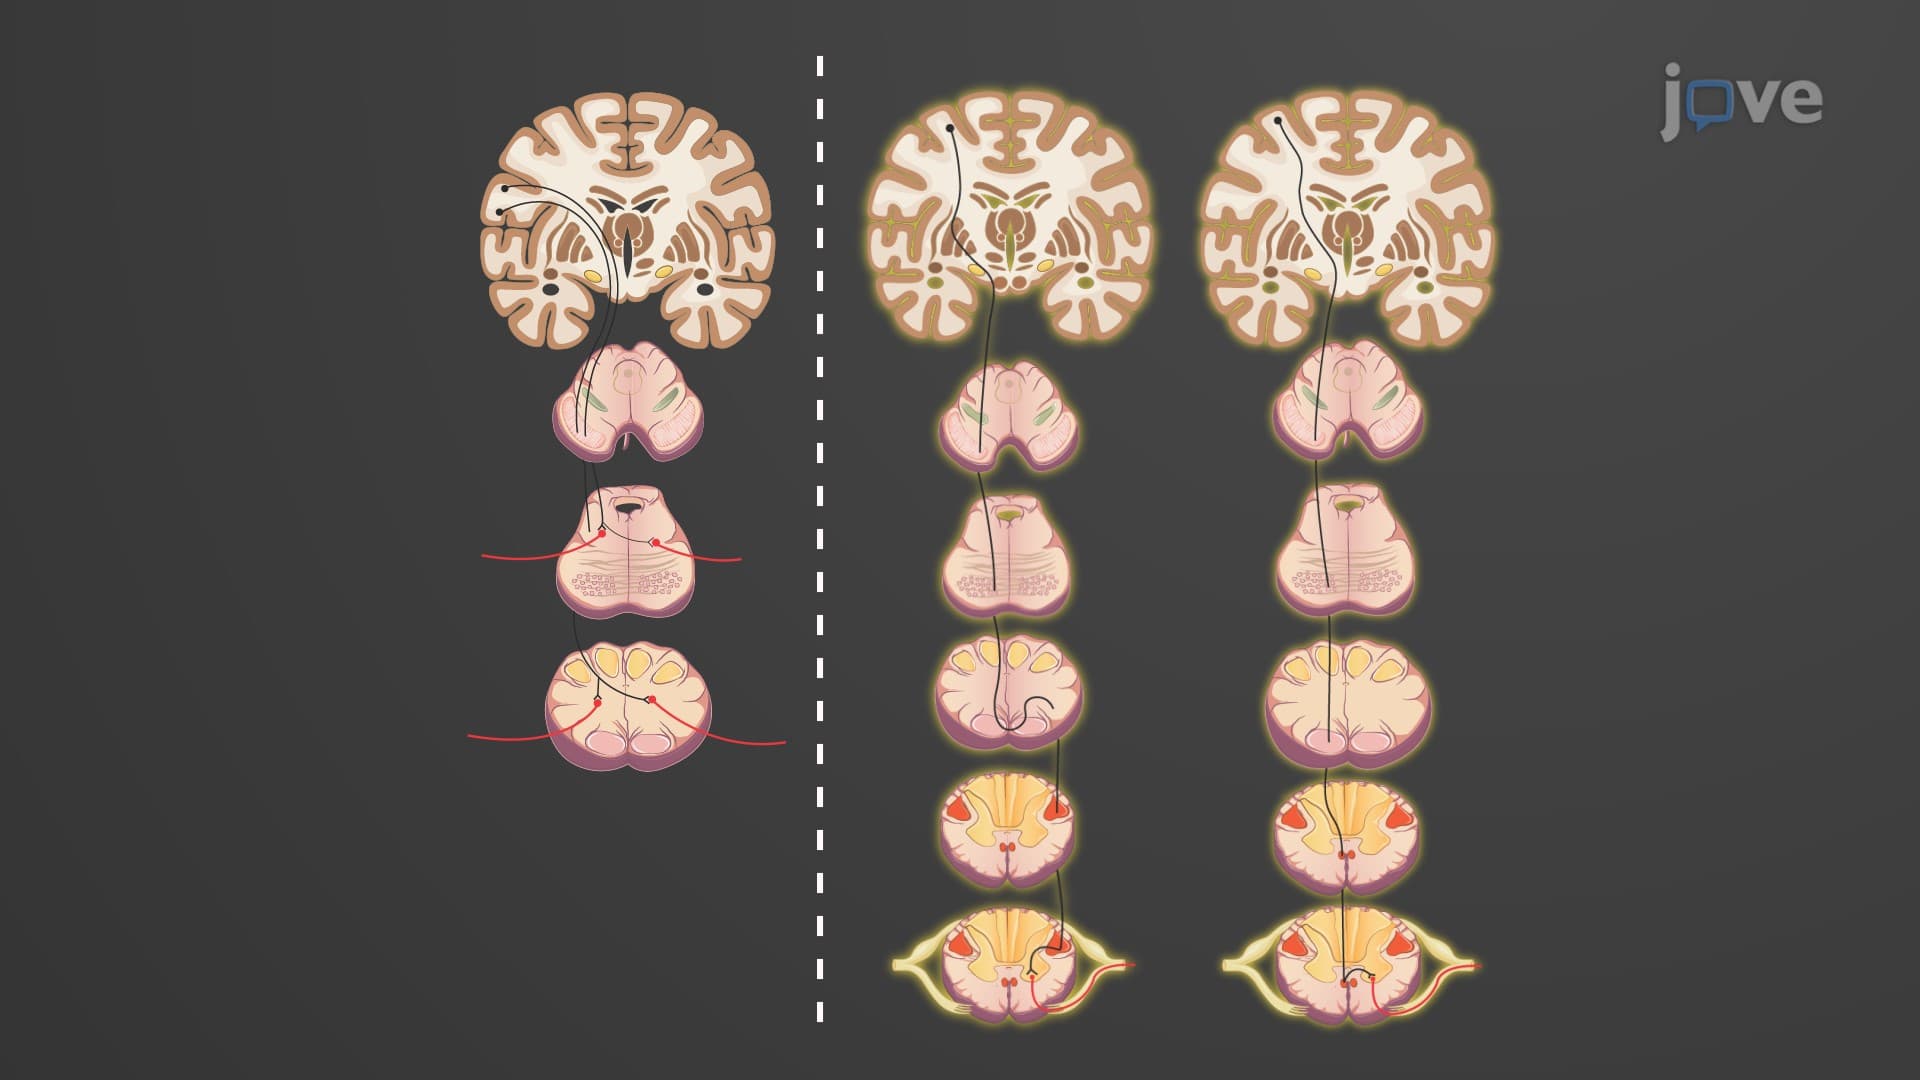
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:12
Observational Learning
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...