Related Experiment Video
Updated: Aug 25, 2025
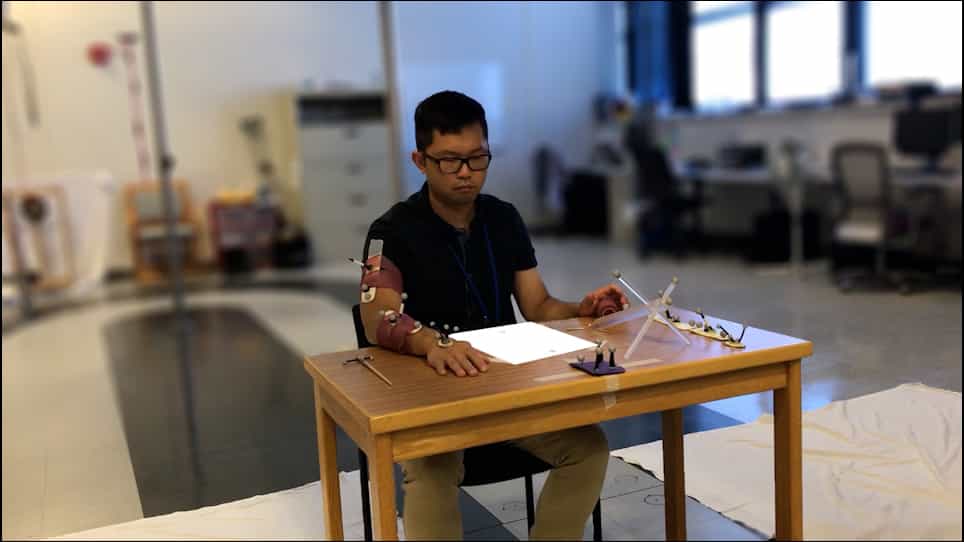

The Impact of Motor Task Conditions on Goal-Directed Arm Reaching Kinematics and Trunk Compensation in Chronic Stroke Survivors
Published on: May 2, 2021
Analytical-stochastic model of motor difficulty for three-dimensional manipulation tasks
Andrea Lucchese1, Salvatore Digiesi1, Carlotta Mummolo1
1Department of Mechanics, Mathematics and Management, Polytechnic University of Bari, Bari, Italy.

Abstract:
Multiple models exist for the evaluation of human motor performance; some of these rely on the Index of Difficulty (ID), a measure to evaluate the difficulty associated to simple reaching tasks. Despite the numerous applications of the ID in reaching movements, the existing formulations are functions of the geometrical features of the task and do not consider the motor behaviour of subjects performing repetitive movements in interaction with the environment. Variability of movements, length of trajectories, subject-specific strength and skill, and required interaction with the environment are all factors that contribute to the motor difficulty experienced by a moving agent (e.g., human, robot) as it repeatedly interacts with the environment during a given task (e.g., target-reaching movement, locomotion, etc.). A novel concept of motor difficulty experienced by an agent executing repetitive end-effector movements is presented in this study. A stochastic ID formulation is proposed that captures the abovementioned factors and applies to general three-dimensional motor tasks. Natural motor variability, inherent in the proposed model, is representative of the flexibility in motor synergies for a given agent-environment interaction: the smaller the flexibility, the greater the experienced difficulty throughout the movement. The quantification of experienced motor difficulty is demonstrated for the case of young healthy subjects performing three-dimensional arm movements during which different objects are manipulated. Results show that subjects' experienced motor difficulty is influenced by the type of object. In particular, a difference in motor difficulty is observed when manipulating objects with different grasp types. The proposed model can be employed as a novel tool to evaluate the motor performance of agents involved in repetitive movements, such as in pick and place and manipulation, with application in both industrial and rehabilitation contexts.


Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...