Related Experiment Video
Updated: Aug 24, 2025
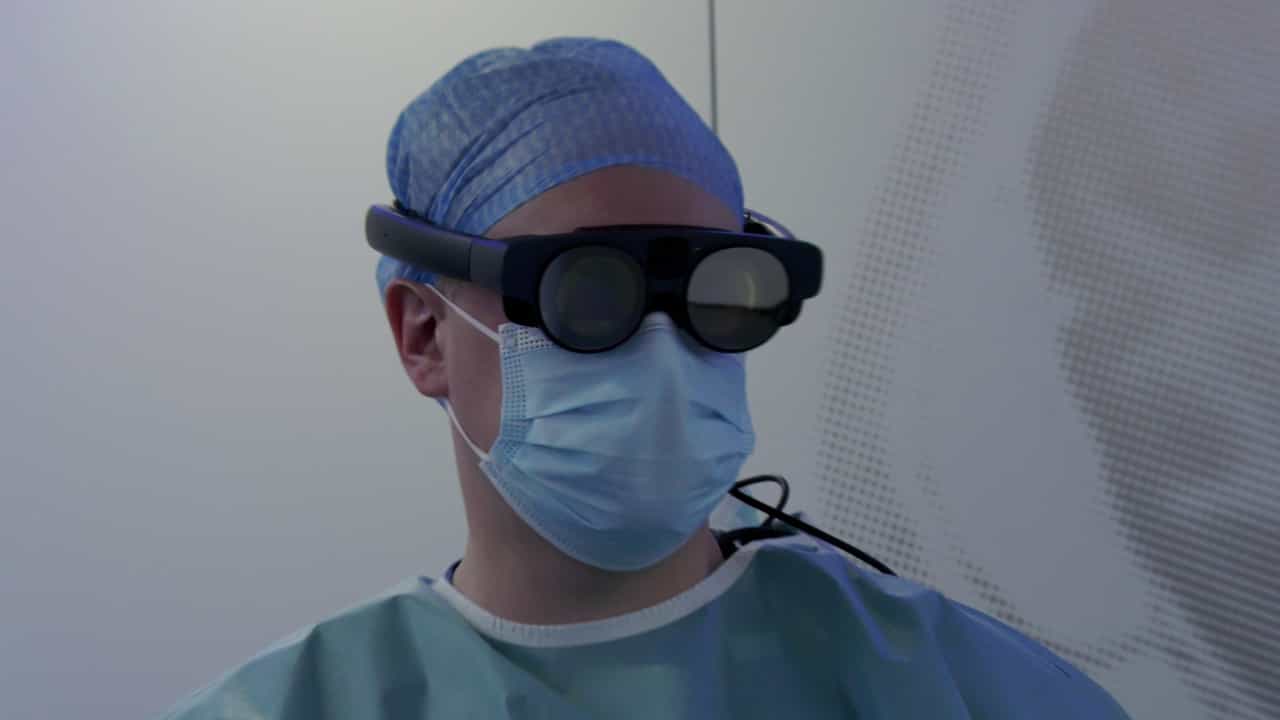

Pedicle Screw Placement Using an Augmented Reality Head-Mounted Display in a Porcine Model
Published on: May 24, 2024
An Augmented Reality-Based Interaction Scheme for Robotic Pedicle Screw Placement
Viktor Vörös1,2, Ruixuan Li1, Ayoob Davoodi1
1Robot-Assisted Surgery Group, Department of Mechanical Engineering, KU Leuven, Celestijnenlaan 300, 3000 Leuven, Belgium.

Abstract:
Robot-assisted surgery is becoming popular in the operation room (OR) for, e.g., orthopedic surgery (among other surgeries). However, robotic executions related to surgical steps cannot simply rely on preoperative plans. Using pedicle screw placement as an example, extra adjustments are needed to adapt to the intraoperative changes when the preoperative planning is outdated. During surgery, adjusting a surgical plan is non-trivial and typically rather complex since the available interfaces used in current robotic systems are not always intuitive to use. Recently, thanks to technical advancements in head-mounted displays (HMD), augmented reality (AR)-based medical applications are emerging in the OR. The rendered virtual objects can be overlapped with real-world physical objects to offer intuitive displays of the surgical sites and anatomy. Moreover, the potential of combining AR with robotics is even more promising; however, it has not been fully exploited. In this paper, an innovative AR-based robotic approach is proposed and its technical feasibility in simulated pedicle screw placement is demonstrated. An approach for spatial calibration between the robot and HoloLens 2 without using an external 3D tracking system is proposed. The developed system offers an intuitive AR-robot interaction approach between the surgeon and the surgical robot by projecting the current surgical plan to the surgeon for fine-tuning and transferring the updated surgical plan immediately back to the robot side for execution. A series of bench-top experiments were conducted to evaluate system accuracy and human-related errors. A mean calibration error of 3.61 mm was found. The overall target pose error was 3.05 mm in translation and 1.12∘ in orientation. The average execution time for defining a target entry point intraoperatively was 26.56 s. This work offers an intuitive AR-based robotic approach, which could facilitate robotic technology in the OR and boost synergy between AR and robots for other medical applications.