A wrist-inspired suspended tubercle-type tensegrity joint with variable stiffness capacity
Related Experiment Video
Updated: Aug 22, 2025
Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023
Xiongdun Xie1, Dezhu Xiong1, James Zhiqing Wen1
1Ji Hua Laboratory, Engineering Research Center for Intelligent Robotics, Foshan, People's Republic of China.

Abstract:
In complex and unpredictable environments or in situations of human-robot interaction, a soft and flexible robot performs more safely and is more impact resistant compared to a traditional rigid robot. To enable robots to have bionic features (flexibility, compliance and variable stiffness) similar to human joints, structures involving suspended tubercle tensegrity are researched. The suspended tubercle gives the joint compliance and flexibility by isolating two moving parts. The variable stiffness capacity is achieved by changing the internal stress of tensegrity through the simultaneous contraction or relaxation of the driving tendons. A wrist-inspired tensegrity-based bionic joint is proposed as a case study. It has variable stiffness and two rotations with a total of three degrees of freedom. Through theoretical derivation and simulation calculation in the NASA Tensegrity RobotToolkit (NTRT) simulator, the range of motion, stiffness adjustable capacity, and their interaction are studied. A prototype is built and tested under a motion capture system. The experimental result agrees well with the theoretical simulation. Our experiments show that the suspended tubercle-type tensegrity is flexible, the stiffness is adjustable and easy to control, and it has great potential for bionic joints.
Related Concept Videos
 01:09
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:20
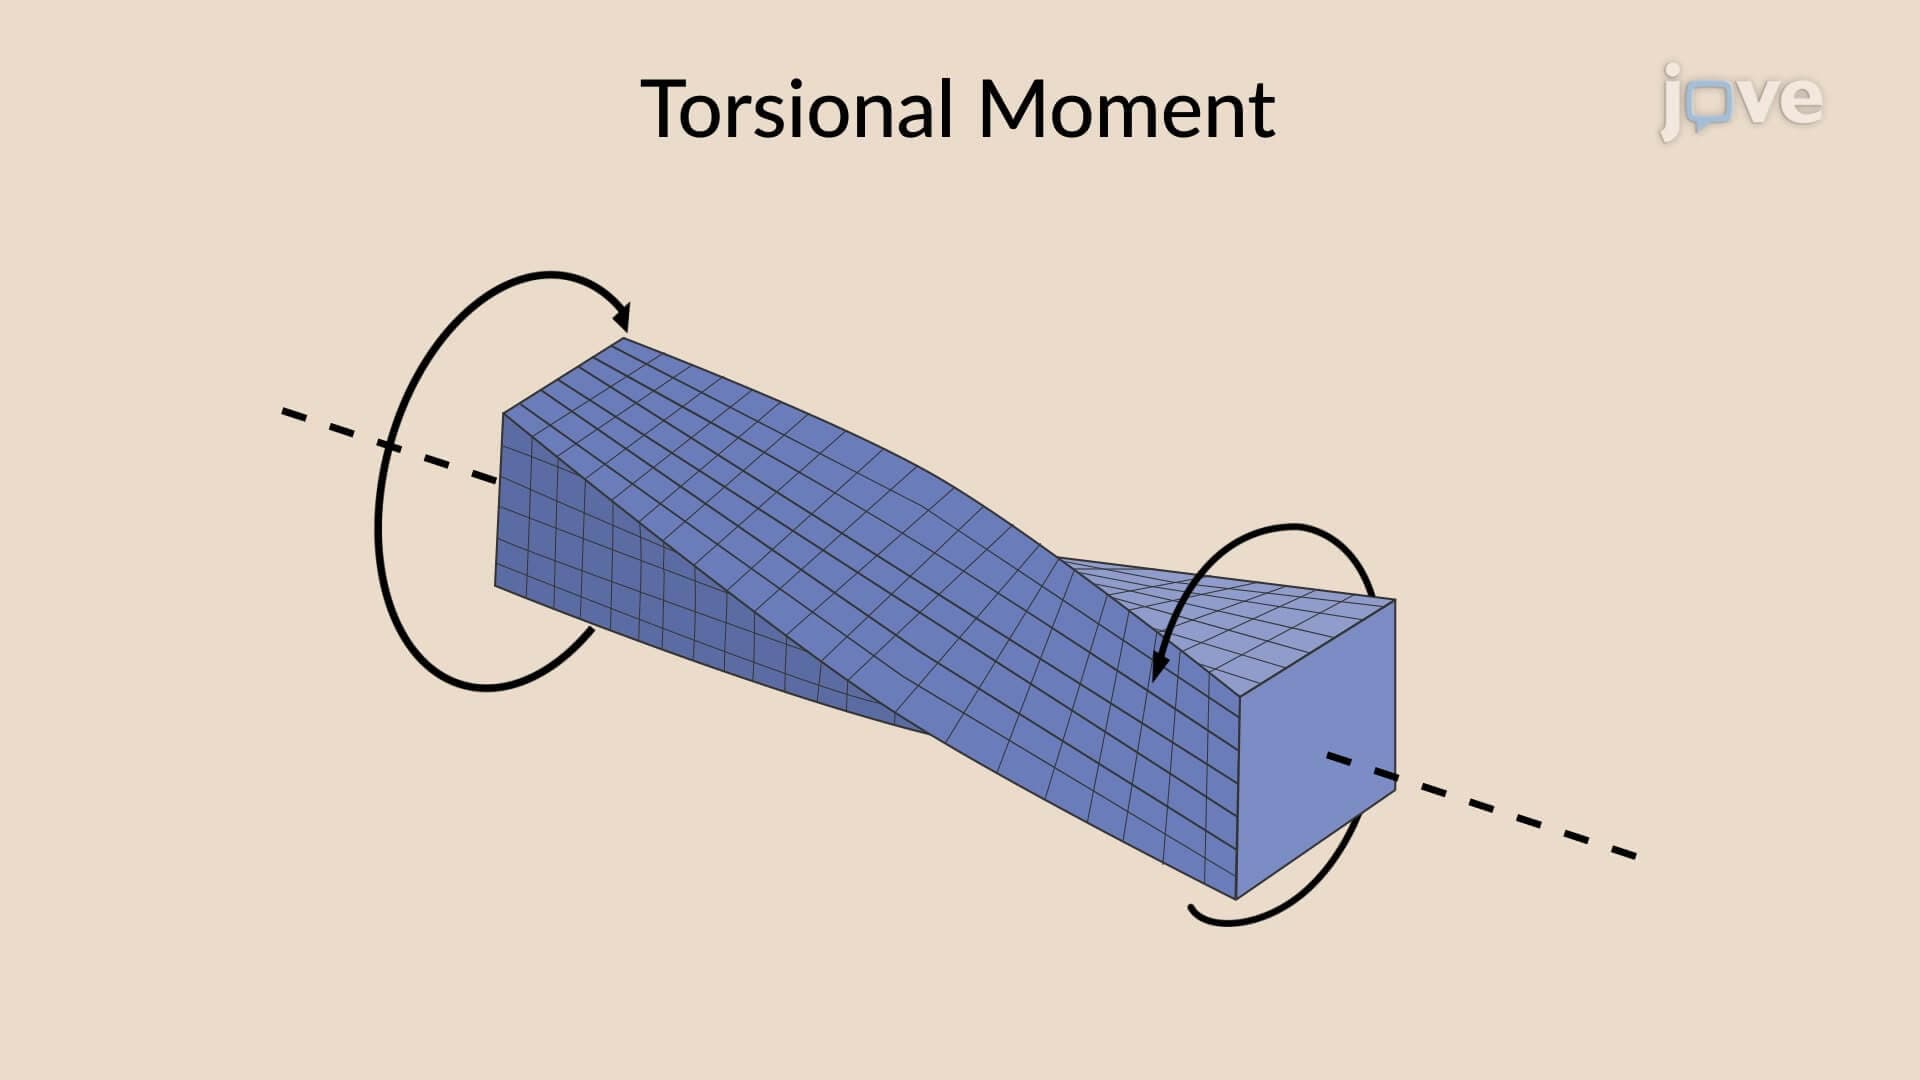
Bending and Torsional Moments
The reaction developed in a structural element when subjected to an external force causes the element to bend. When a structural element bends upwards, it creates compressive normal forces on the top and tensile normal forces on the bottom, resulting in a couple that determines the bending...
 01:16
Structural Joints: Synovial Joints
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...
 01:10
Ankle Joint
 01:17
Structural Joints: Cartilaginous Joints
There are two types of cartilaginous joints:
Synchondrosis
A synchondrosis ("joined by cartilage") is a cartilaginous joint where bones are connected by hyaline cartilage. Synchondrosis may be temporary...