Related Experiment Video
Updated: Aug 20, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Stability for IT2 T-S fuzzy systems under alternate event-triggered control
Dongsheng Xu1, Siyuan Cheng1, Huan Su1
1Department of Mathematics, Harbin Institute of Technology (Weihai), Weihai 264209, PR China.

Abstract:
In this paper, an alternate event-triggered control is proposed to achieve stability of interval type-2 Takagi-Sugeno fuzzy systems. Comparing with the existing literature, this new control strategy displays an almost complete aperiodic feature which eliminates the conservativeness caused by time-triggered property of the traditional aperiodically intermittent control. Moreover, with two events being triggered alternately in this control strategy through examining two predetermined conditions, the efficiency of control can be further improved and the resources consumption can be greatly reduced. By employing the Lyapunov function and graph theory, several stability criteria are rigorously demonstrated. In addition, Zeno behavior is excluded in our system through obtaining a positive lower bound of the time interval between two triggering points. Subsequently, the validity of the presented strategy is evidenced by single-link robot arms systems. Finally, a numerical example is given to lend insight into the feasibility of our theoretical results.


Related Concept Videos
 01:28
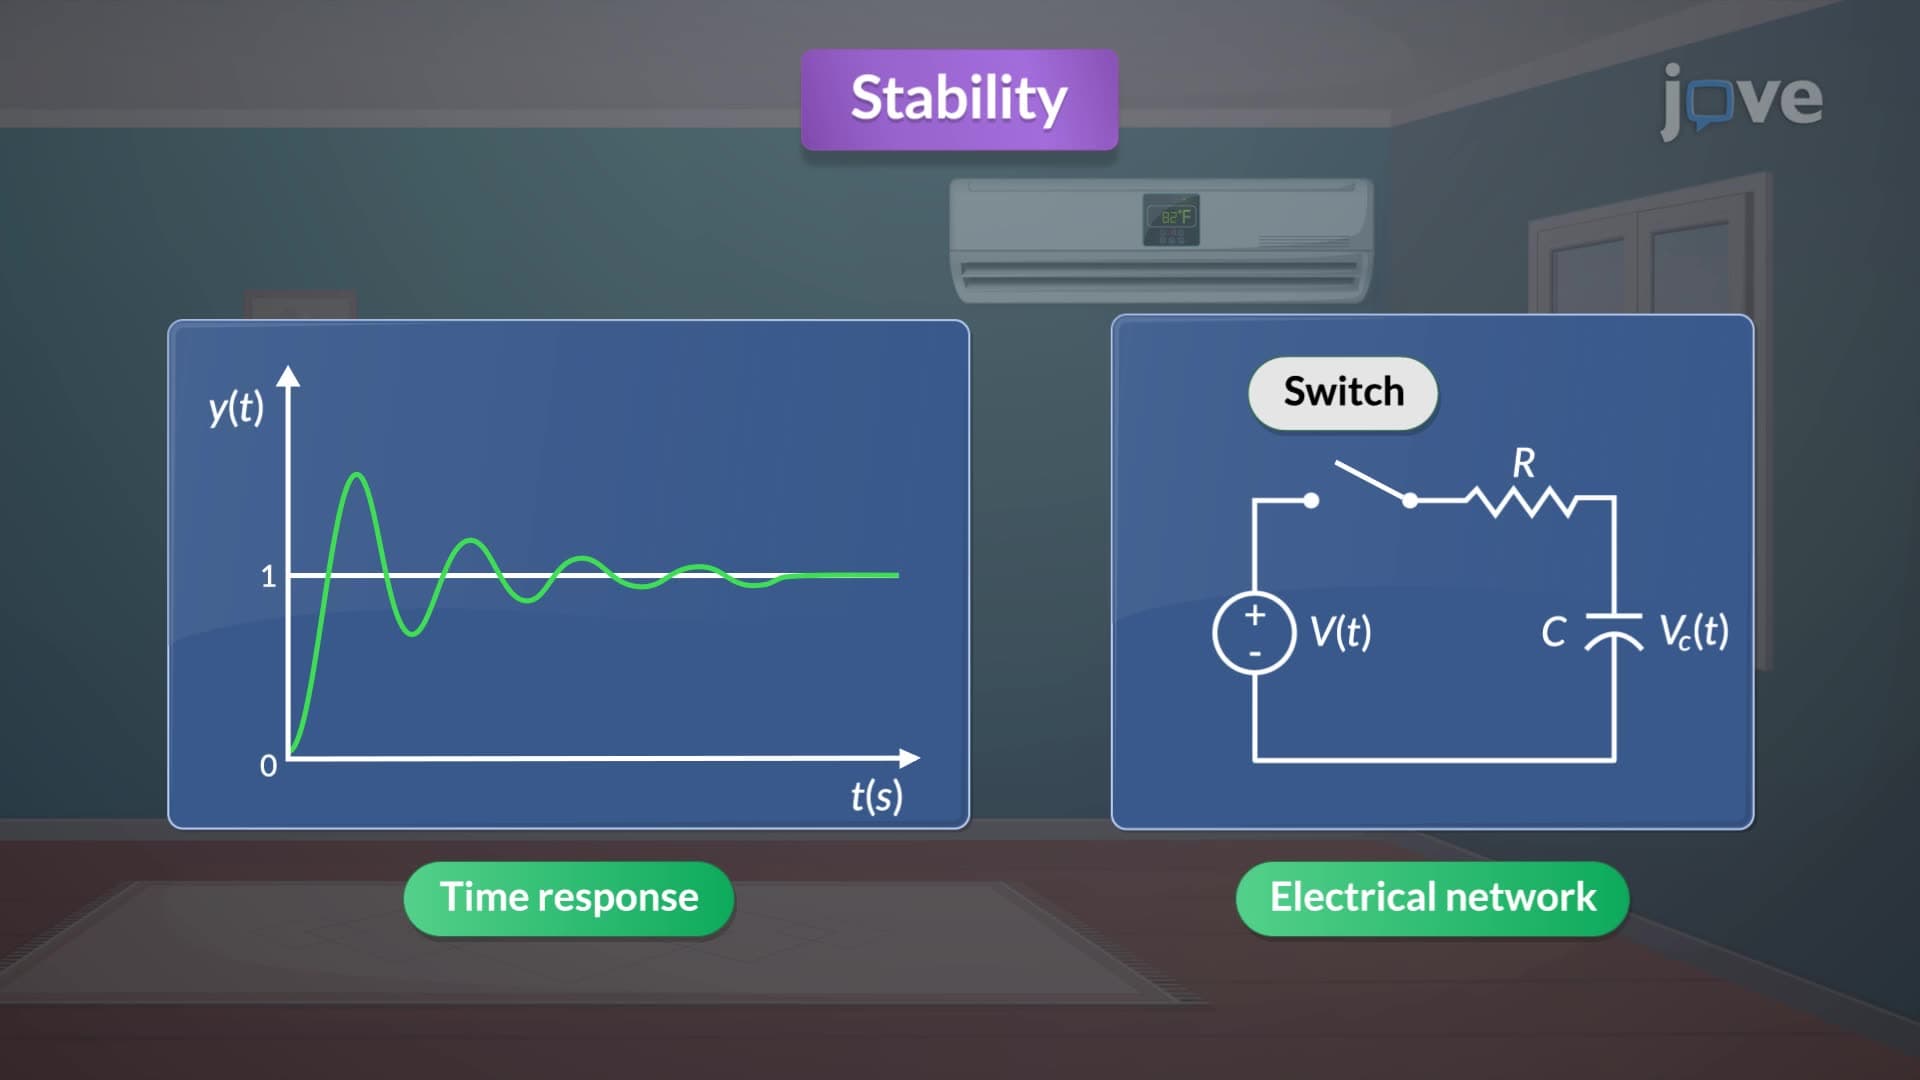
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:24
Transient and Steady-state Response
These test signals are integral in designing control systems to exhibit two key performance aspects: transient response and steady-state...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....