Related Experiment Video
Updated: Aug 15, 2025

Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
A Study on Dynamic Motion Planning for Autonomous Vehicles Based on Nonlinear Vehicle Model
Xin Tang1, Boyuan Li2, Haiping Du3
1Fok Ying Tung Research Institute, Hong Kong University of Science and Technology (HKUST), Guangzhou 511458, China.

Abstract:
Autonomous driving technology, especially motion planning and the trajectory tracking method, is the foundation of an intelligent interconnected vehicle, which needs to be improved urgently. Currently, research on path planning methods has improved, but few of the current studies consider the vehicle's nonlinear characteristics in the reference model, due to the heavy computational effort. At present, most of the algorithms are designed by a linear vehicle model in order to achieve the real-time performance at the cost of lost accuracy. To achieve a better performance, the dynamics and kinematics characteristics of the vehicle must be simulated, and real-time computing ensured at the same time. In this article, a Takagi-Sugeno fuzzy-model-based closed-loop rapidly exploring random tree algorithm with on-line re-planning process is applied to build the motion planner, which effectively improves the vehicle performance of dynamic obstacle avoidance, and plans the local obstacle avoidance path in line with the dynamic characteristics of the vehicle. A nonlinear vehicle model is integrated into the motion planner design directly. For fast local path planning mission, the Takagi-Sugeno fuzzy modelling method is applied to the modeling process in the planner design, so that the vehicle state can be directly utilized into the path planner to create a feasible path in real-time. The performance of the planner was evaluated by numerical simulation. The results demonstrate that the proposed motion planner can effectively generate a reference trajectory that guarantees driving efficiency with a lower re-planning rate.
More Related Videos
 10:52
Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
 09:46
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:15
Kinematic Equations: Problem Solving
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
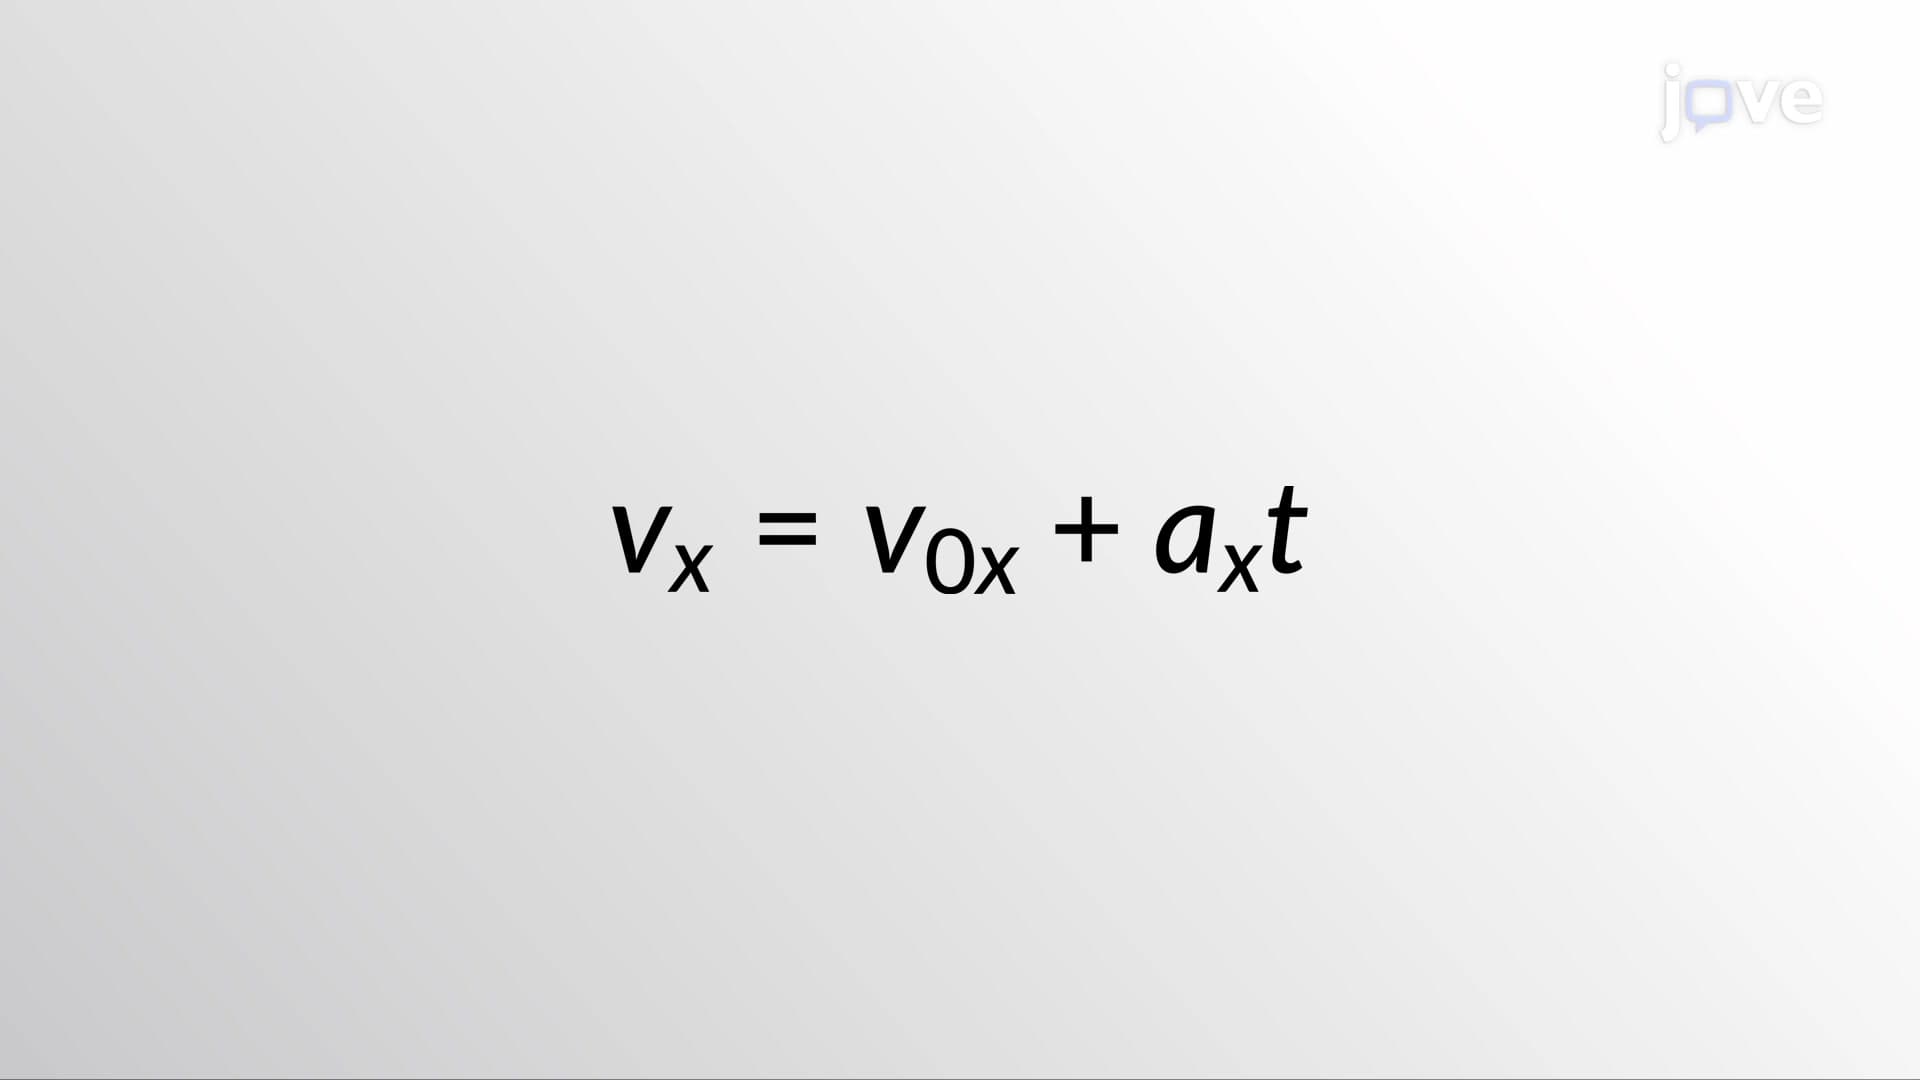 01:26
Kinematic Equations - I