A method to benchmark the balance resilience of robots
Related Experiment Video
Updated: Aug 11, 2025
A Modified Lean and Release Technique to Emphasize Response Inhibition and Action Selection in Reactive Balance
Published on: March 19, 2020
Simone Monteleone1, Francesca Negrello2, Giorgio Grioli2
1Centro di Ricerca E. Piaggio e Dipartimento di Ingegneria dell'Informazione, Università di Pisa, Pisa, Italy.

Abstract:
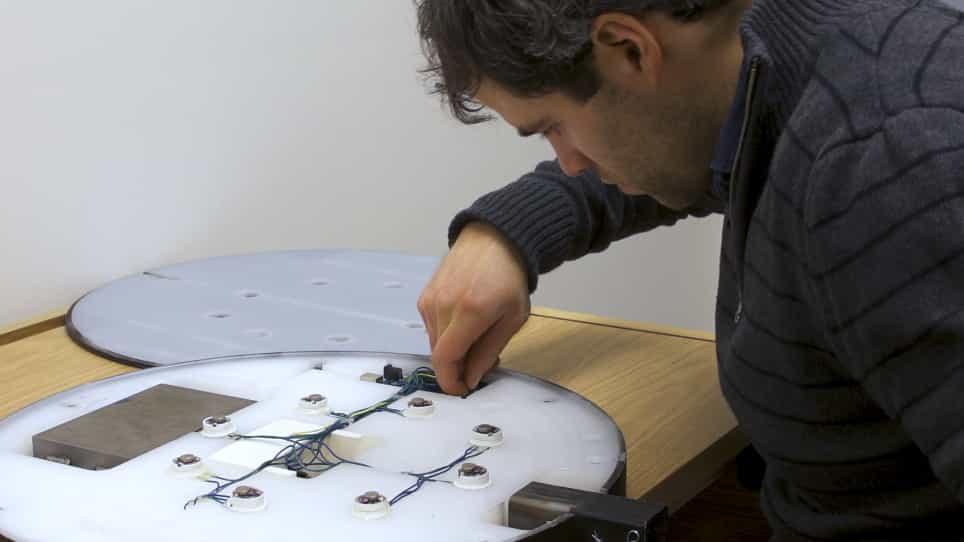
Robots that work in unstructured scenarios are often subjected to collisions with the environment or external agents. Accordingly, recently, researchers focused on designing robust and resilient systems. This work presents a framework that quantitatively assesses the balancing resilience of self-stabilizing robots subjected to external perturbations. Our proposed framework consists of a set of novel Performance Indicators (PIs), experimental protocols for the reliable and repeatable measurement of the PIs, and a novel testbed to execute the protocols. The design of the testbed, the control structure, the post-processing software, and all the documentation related to the performance indicators and protocols are provided as open-source material so that other institutions can replicate the system. As an example of the application of our method, we report a set of experimental tests on a two-wheeled humanoid robot, with an experimental campaign of more than 1100 tests. The investigation demonstrates high repeatability and efficacy in executing reliable and precise perturbations.