Observer-based event-triggered leader-following consensus of multi-agents with generalized Lipschitz nonlinear dynamics
Related Experiment Video
Updated: Aug 9, 2025
The HoneyComb Paradigm for Research on Collective Human Behavior
Published on: January 19, 2019
Iqra Zulfiqar Awan1, Fatima Tahir1, Muhammad Rehan1
1Department of Electrical Engineering, Pakistan Institute of Engineering and Applied Sciences (PIEAS), Islamabad, Pakistan.

Abstract:
This paper discusses a leader-following consensus problem for nonlinear multi-agent systems (MASs) subjected to generalized Lipschitz-type nonlinearity using output feedback. An event-triggered (ET) leader-following control scheme, based upon estimated states using observers, is proposed for efficient bandwidth utilization by application of invariant sets. Distributed observers are designed to estimate the states of the followers because actual states are not always readily available. Besides, in order to reduce unnecessary data communication among the followers, an ET strategy has been formulated which excludes Zeno behavior as well. Under this proposed scheme, sufficient conditions are formulated using Lyapunov theory. These conditions not only guarantee the asymptotic stability of estimation error, but also ensure the tracking consensus of nonlinear MASs. Further, a simple and less conservative design approach using a decoupling scheme for assuring necessity and sufficiency for the main design approach has also been explored. The decoupling scheme is similar to separation principle for linear systems. Contrary to the existing works, the nonlinear systems considered in this study cover a wide family of Lipschitz nonlinearities, including both globally and locally Lipschitz systems. Moreover, the proposed approach is more efficient in handling ET consensus. Finally, the obtained results are verified with single link robots and modified Chua's circuits.
Related Concept Videos
 01:23
Principle of Linear Impulse and Momentum for a Single Particle: Problem Solving
 01:23
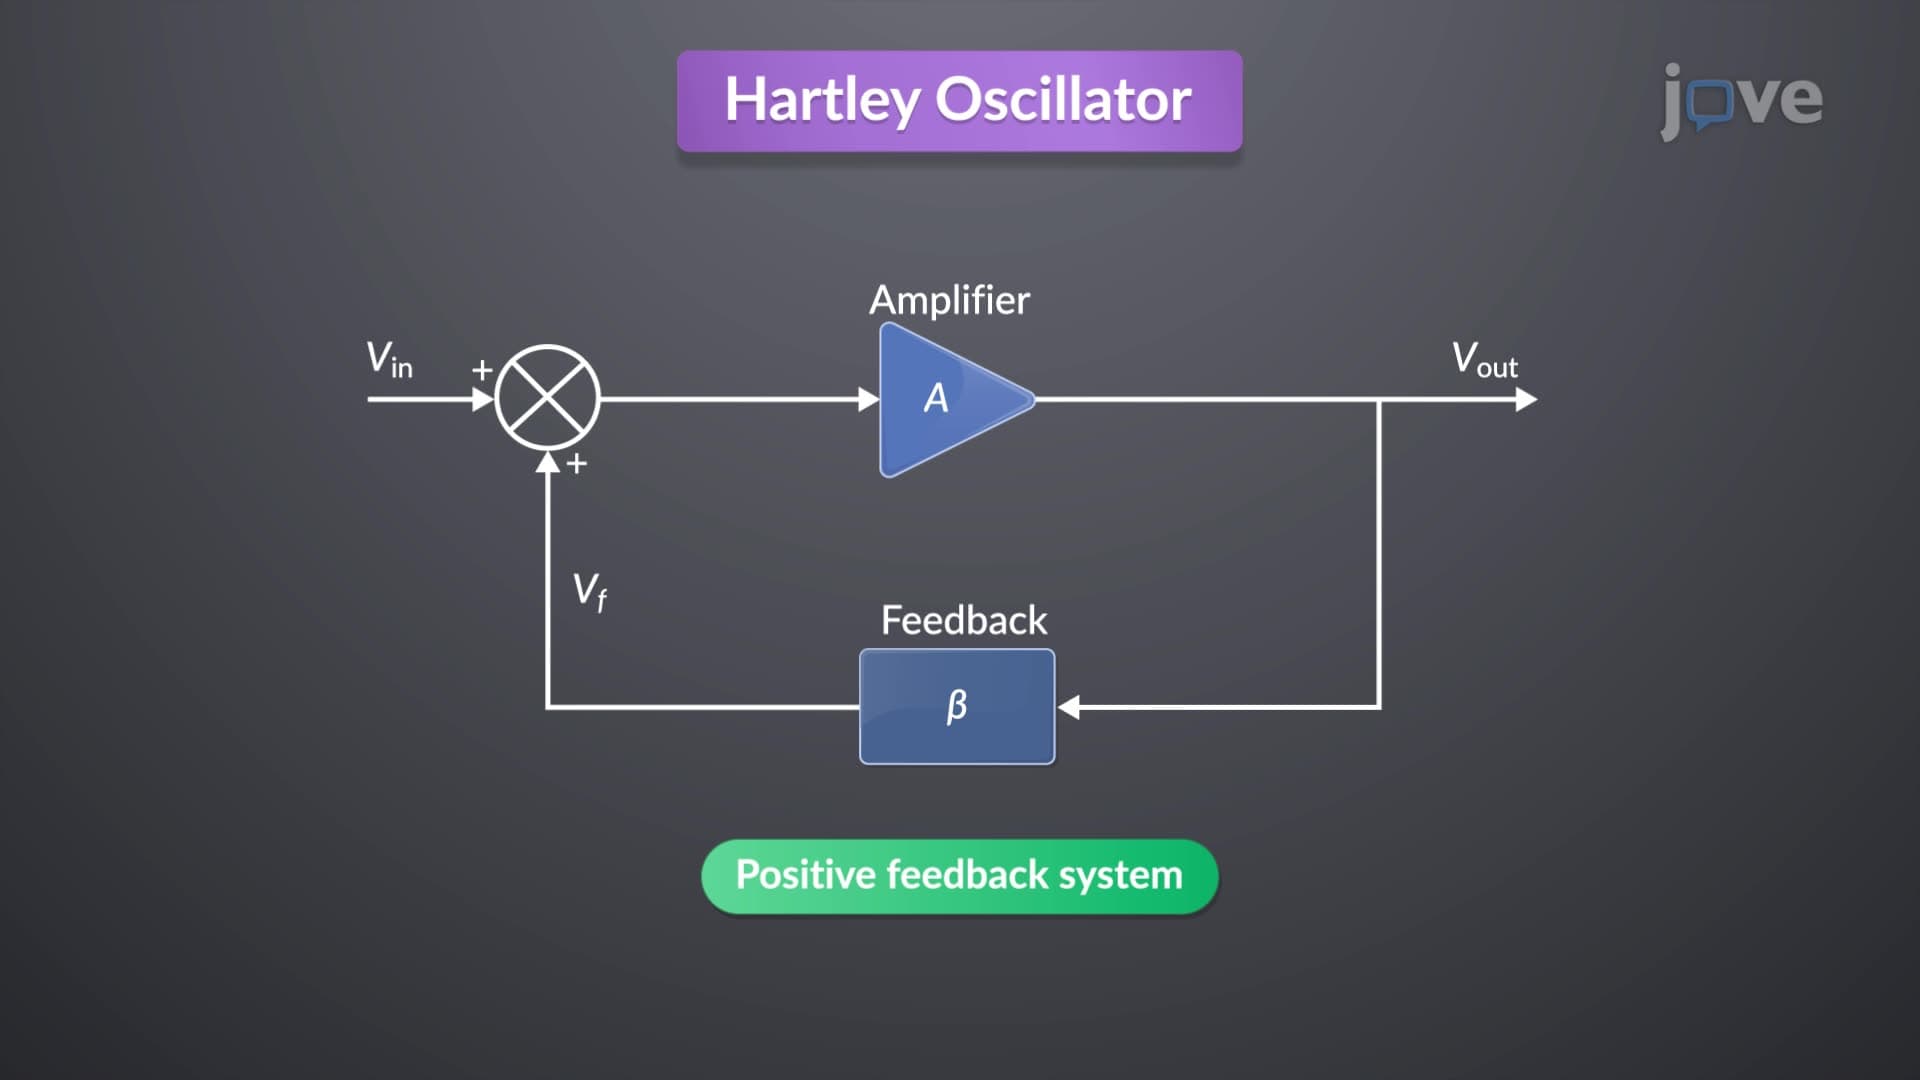
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:21
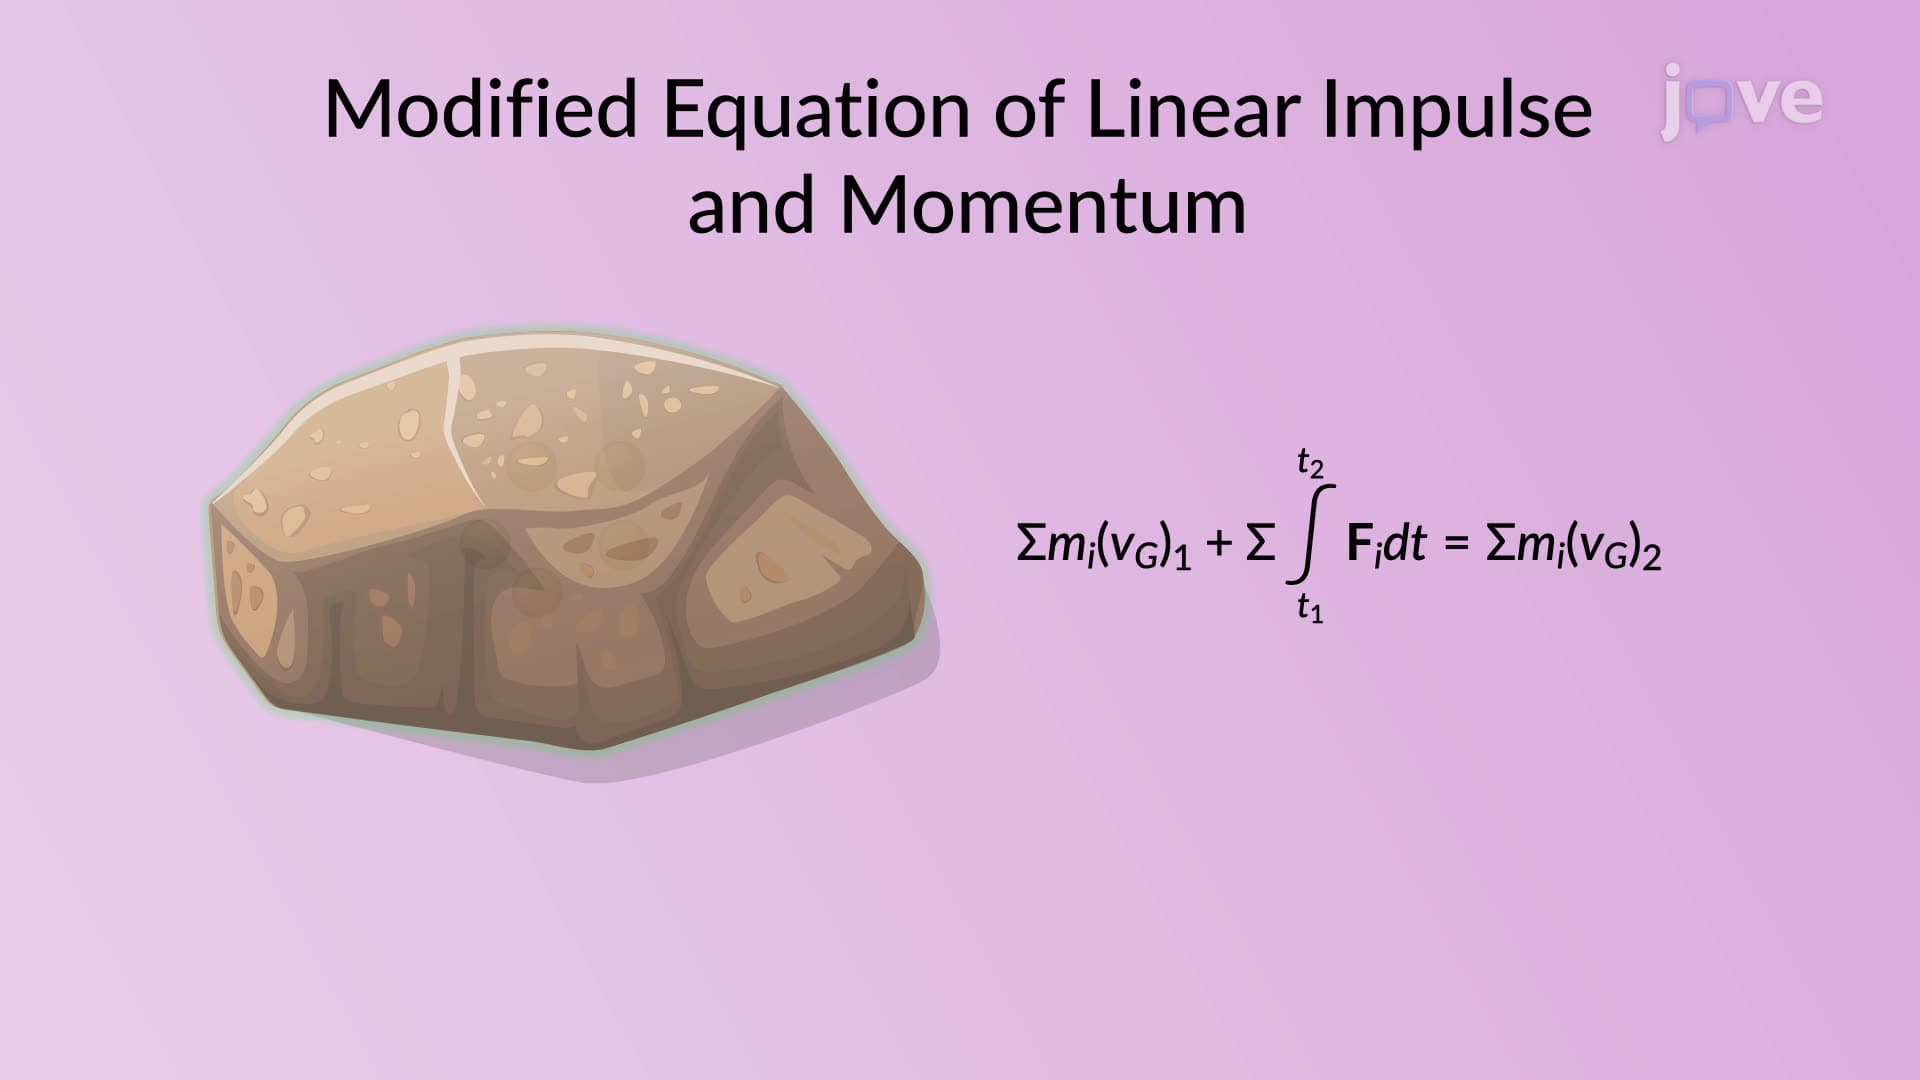
Principle of Linear Impulse and Momentum for a System of Particles
Notably, internal forces between particles, occurring in equal and opposite collinear pairs, cancel out and are not part of the equation of motion. This exclusion simplifies the...
 01:18
Second Order systems II
 01:13
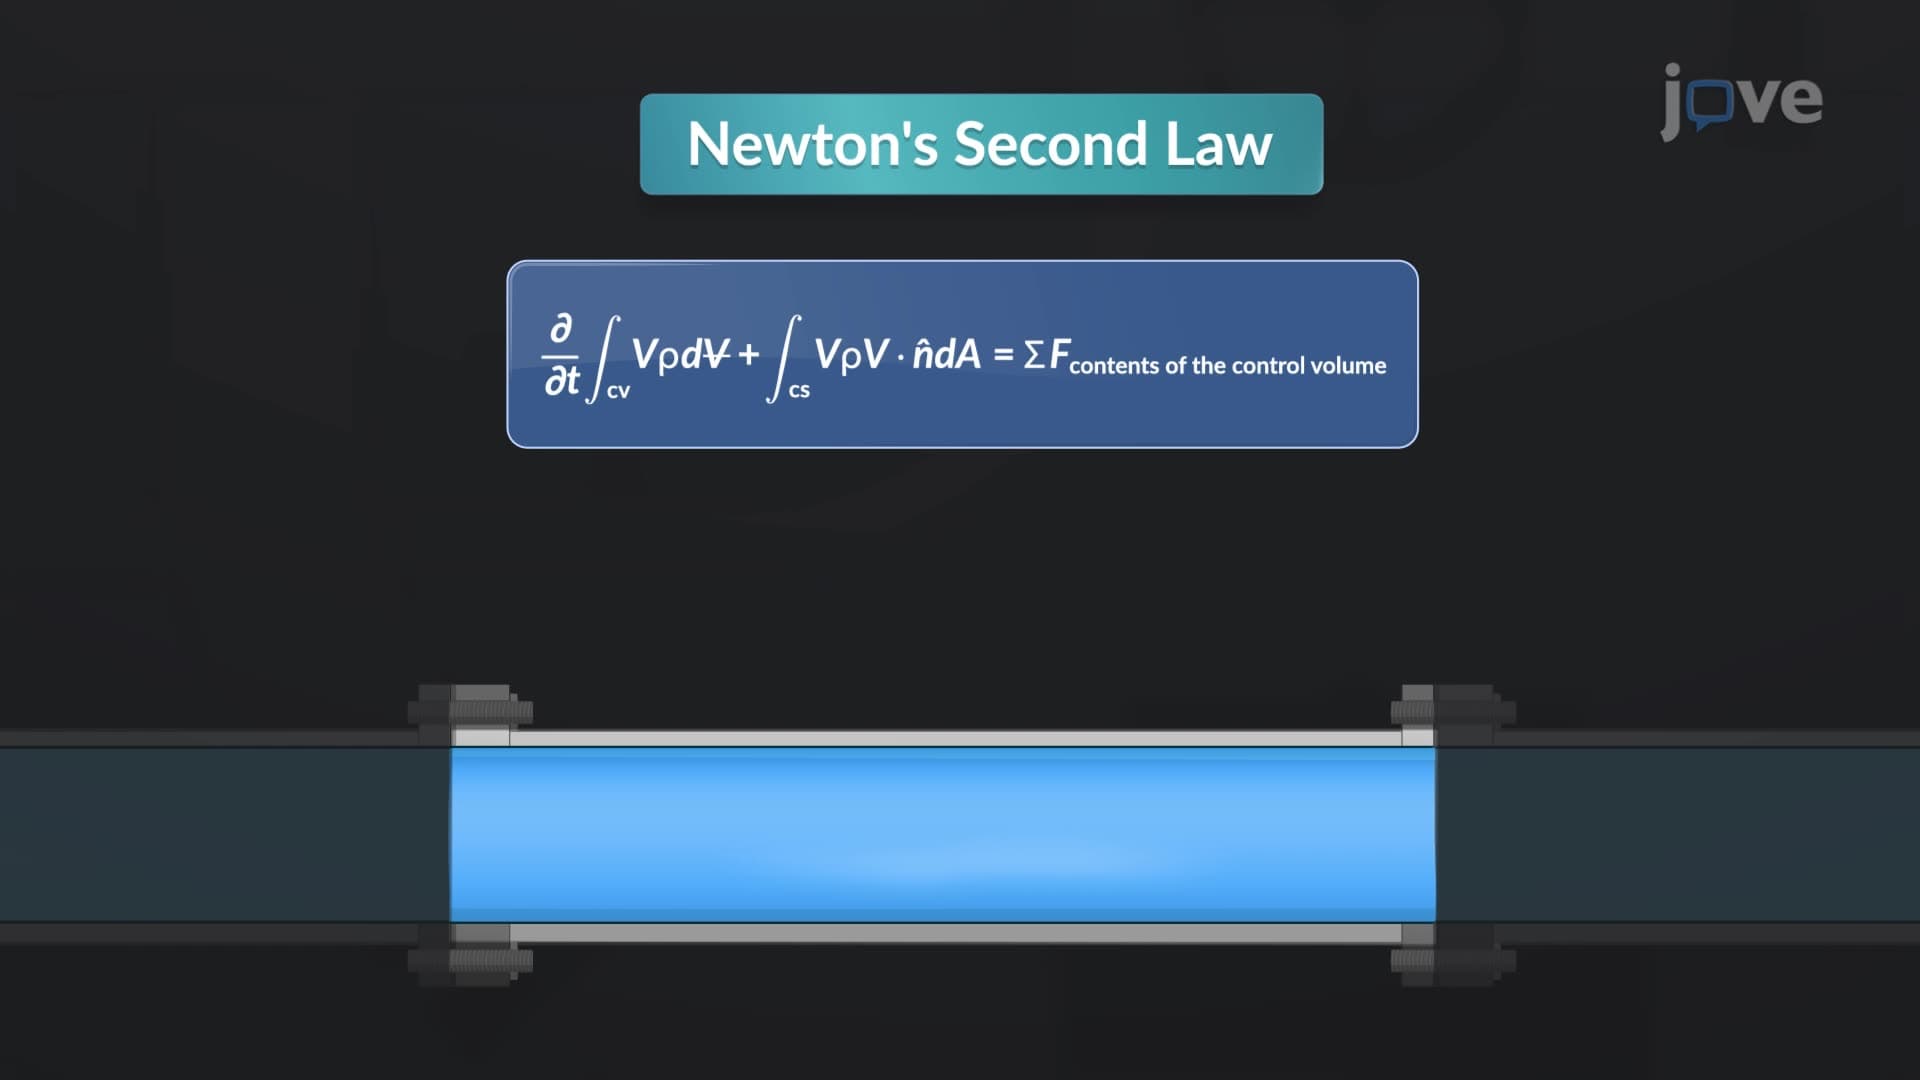
Linear Momentum in Control Volume
 01:13
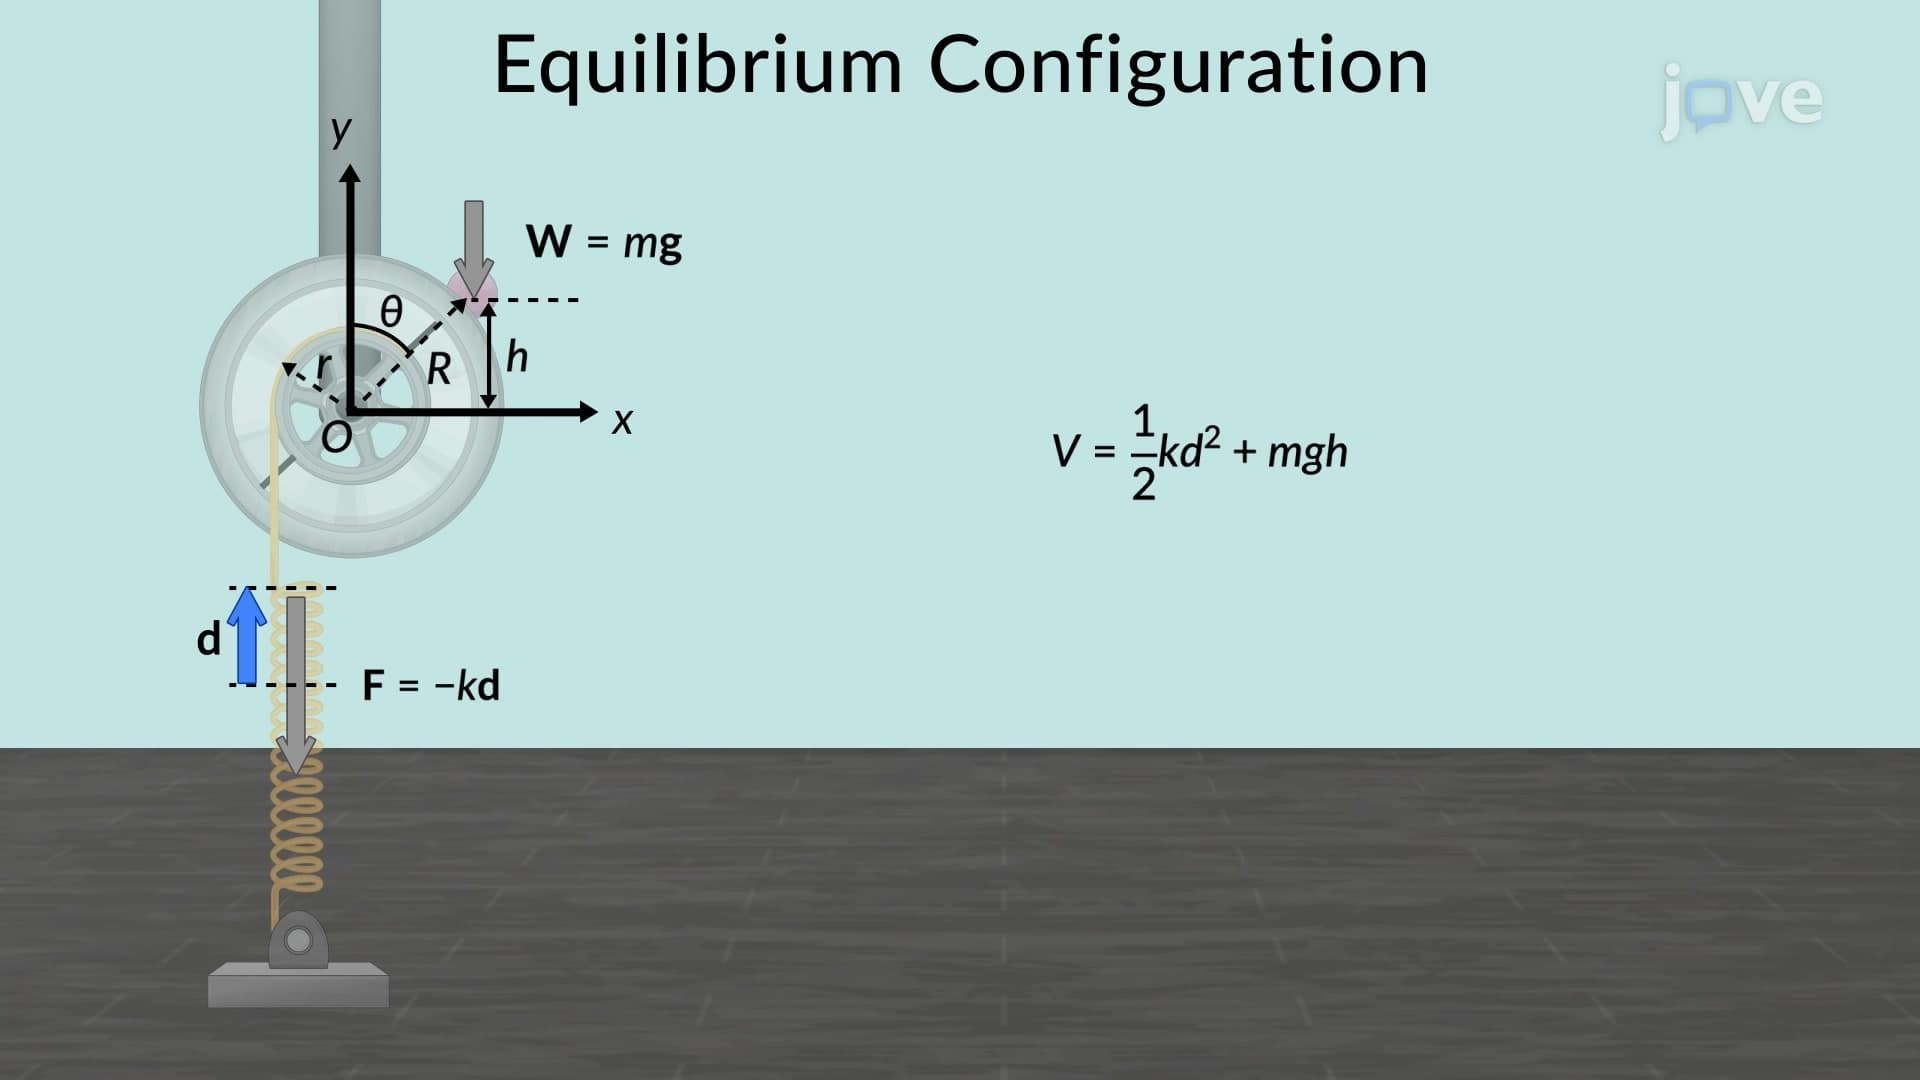
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...