Related Experiment Video
Updated: Jul 31, 2025
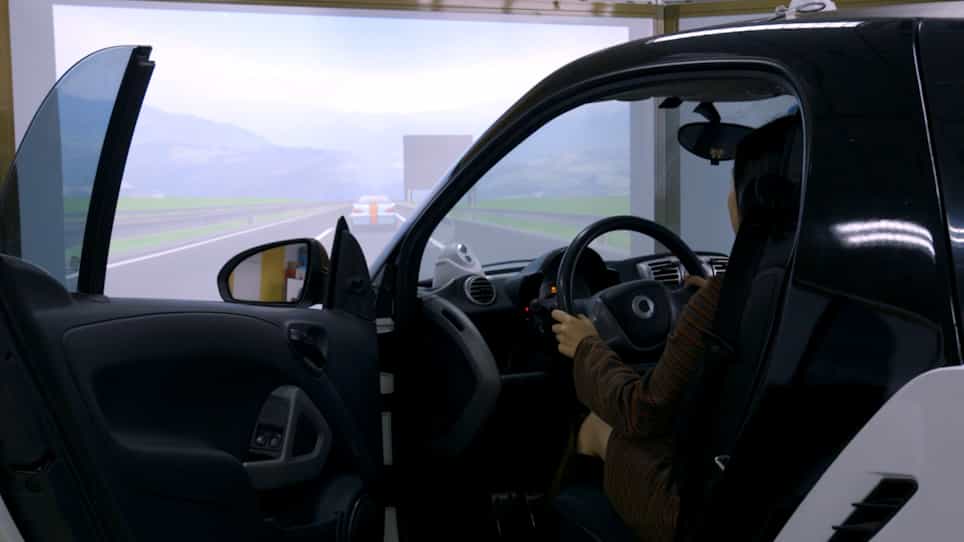
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
A proactive crash risk prediction framework for lane-changing behavior incorporating individual driving styles
Yunchao Zhang1, Yanyan Chen1, Xin Gu1
1Beijing Key Laboratory of Traffic Engineering, Beijing University of Technology, No.100, Pingleyuan, Chaoyang District, Beijing 100124, China.

Abstract:
Driving style may have an important effect on traffic safety. Proactive crash risk prediction for lane-changing behaviors incorporating individual driving styles can help drivers make safe lane-changing decisions. However, the interaction between driving styles and lane-changing risk is still not fully understood, making it difficult for advanced driver-assistance systems (ADASs) to provide personalized lane-changing risk information services. This paper proposes a personalized risk lane-changing prediction framework that considers driving style. Several driving volatility indices based on vehicle interactive features have been proposed, and a dynamic clustering method is developed to determine the best identification time window and methods of driving style. The Light Gradient Boosting Machine (LightGBM) based on Shapley additive explanation is used to predict lane-changing risk for cautious, normal, and aggressive drivers and to analyze their risk factors. The highD trajectory dataset is used to evaluate the proposed framework. The obtained results show that i) spectral clustering and a time window of 3 s can accurately identify driving styles during the lane-changing intention process; ii) the LightGBM algorithm outperforms other machine learning methods in personalized lane-changing risk prediction; iii) aggressive drivers seek more individual driving freedom than cautious and normal drivers and tend to ignore the state of the car behind them in the target lane, with a greater lane-changing risk. The research conclusion can provide basic support for the development and application of personalized lane-changing warning systems in ADASs.
Related Concept Videos
 02:24
Predicting Reaction Outcomes
 01:17
Rolling Resistance: Problem Solving
 01:16
Response Surface Methodology
The process of RSM involves several key steps:
 01:12
Relative Risk
 01:27
Drive-Reduction Theory: Push Theory of Motivation
 02:05
Self-Presentation: Self-Monitoring and Self-Handicapping