Optimal vector matching fusion method for bionic compound eye polarization compass and inertial sensor integration
Related Experiment Video
Updated: Jul 22, 2025
Automated Charting of the Visual Space of Housefly Compound Eyes
Published on: March 31, 2022
Qingfeng Dou1, Tao Du2, Yan Wang1
1The School of Automation Science and Electrical Engineering, Beihang University, Beijing 100191, China.

Abstract:
The compound eyes of insects can extract the heading by sensing multi-directional polarization information. Inspired by this, the integration with bionic eye polarization compass and low-precision MEMS inertial sensors yields a new choice for autonomous navigation in a GPS-denied environment. However, the occlusion environments, such as jungles and buildings, seriously affects the attitude estimation accuracy by destroying the polarization information. Considering the above problem, this paper proposes a reliable attitude estimation method based on vector matching measurement models for integration with bionic compound eye polarization compass and low-cost MEMS inertial sensors, including the polarization vector, solar vector, and gravity vector. To realize the matching and fusion among these vector models, the vector optimization selection algorithm is designed according to the number of visible polarization sensors in the occlusion environment. Particularly, the vector optimization selection factor is designed according to the error between the measured and theoretical polarization vectors. Furthermore, when using the solar vector estimation model, the degree of the polarization is applied to improve the calculation accuracy of the solar vector. The gravity vector measurement model is employed to enhance the autonomy of the integration. Finally, the effectiveness of the proposed method is verified by simulated and outdoor experiments under tree obscuration.
Related Concept Videos
 01:29
Vector Components in the Cartesian Coordinate System
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...
 01:16
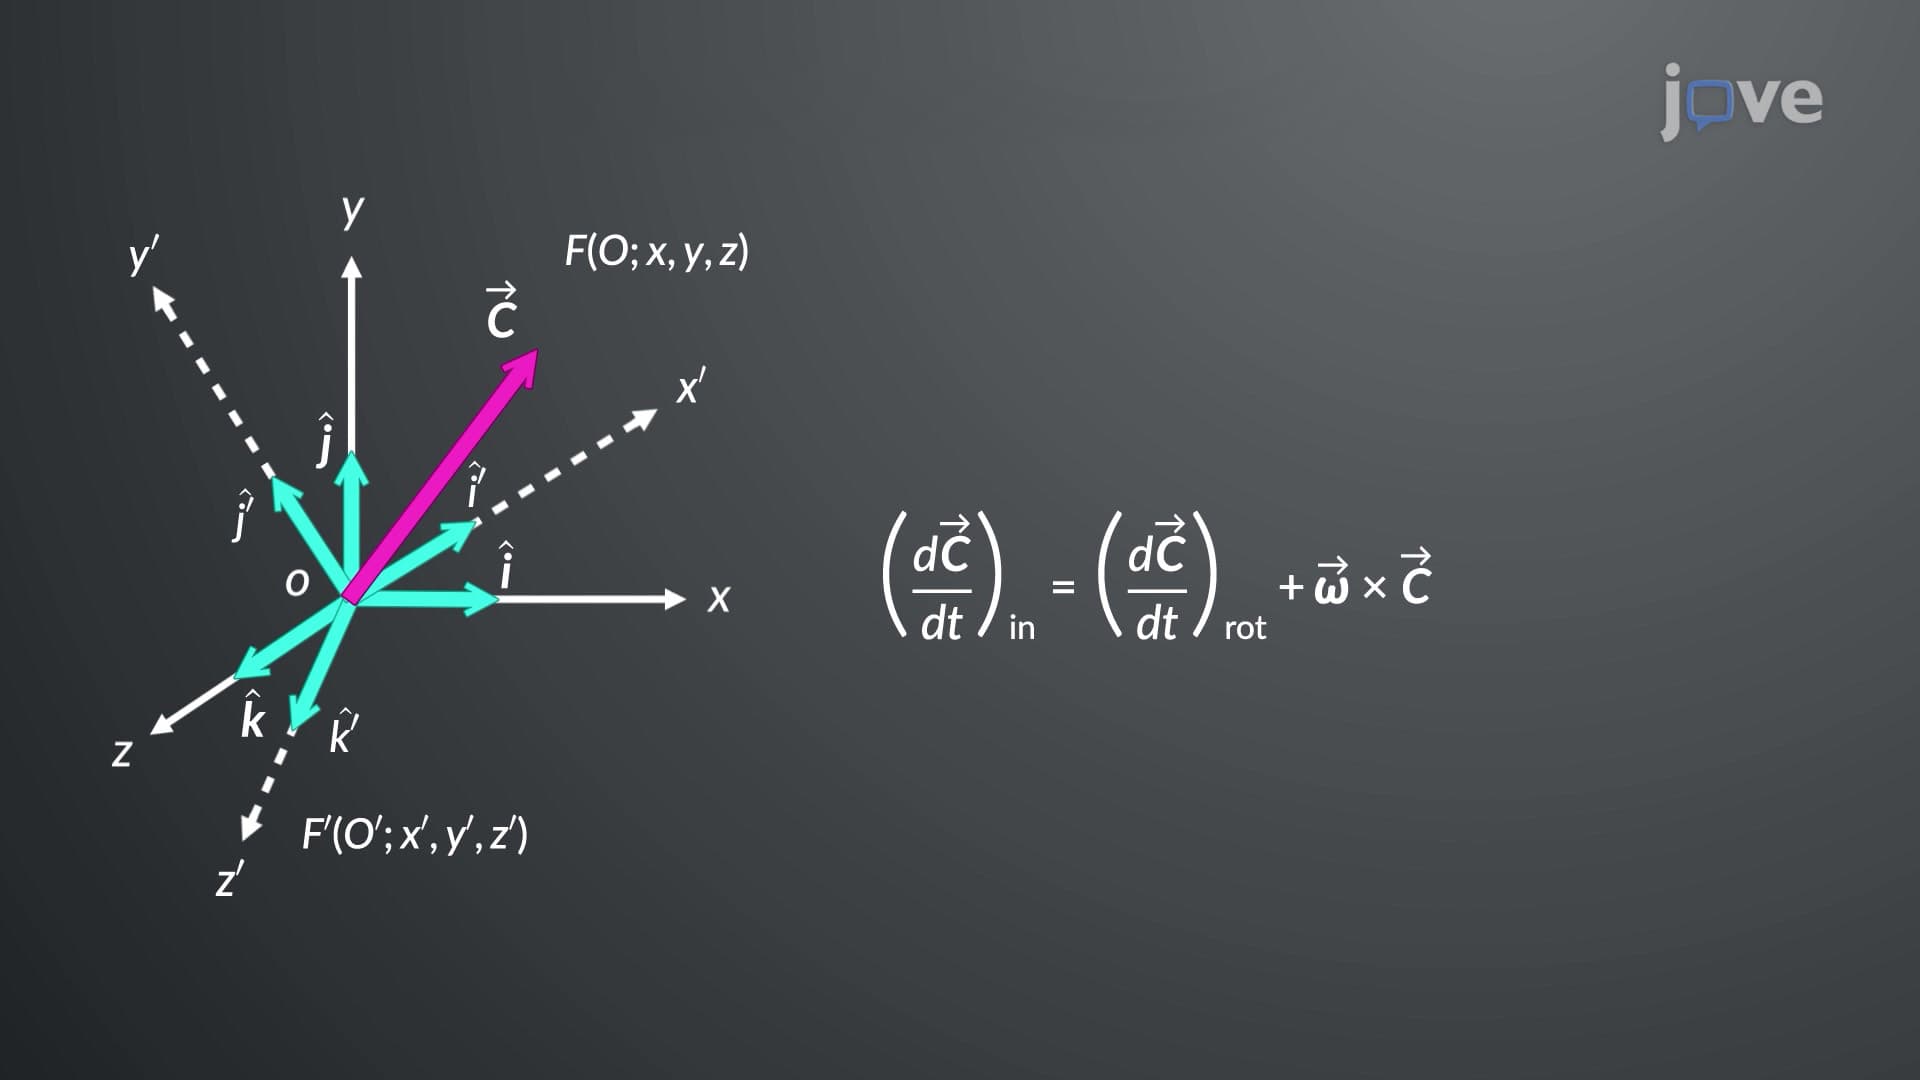
Vector Transformation in Rotating Coordinate Systems
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
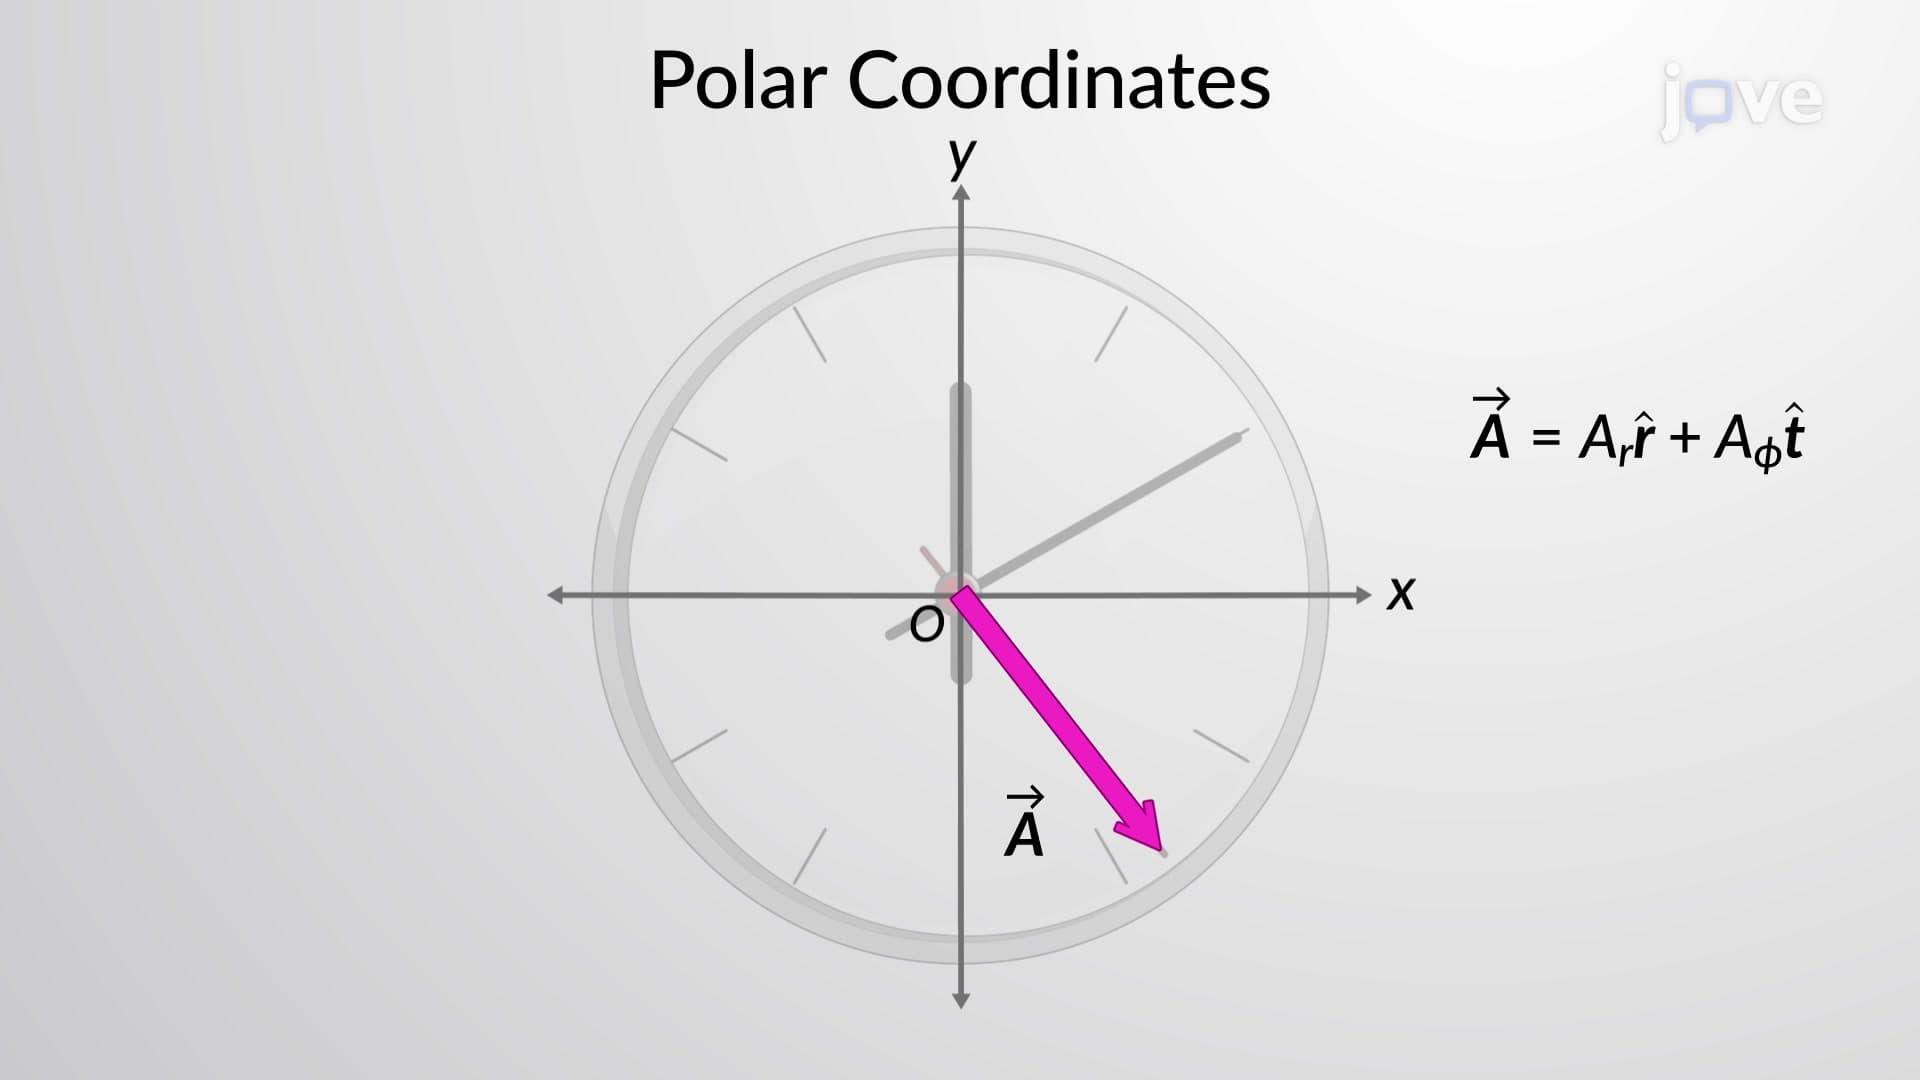
Polar and Cylindrical Coordinates
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...