Modified Active Disturbance Rejection Predictive Control: A fixed-order state-space formulation for SISO systems
Related Experiment Video
Updated: Jul 18, 2025

Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Blanca Viviana Martínez Carvajal1, Javier Sanchis Sáez1, Sergio García-Nieto Rodríguez1
1Instituto Universitario de Automática e Informática Industrial, Universitat Politècnica de València, València, 46022, Spain.

Abstract:
This paper presents a novel control strategy that provides active disturbance rejection predictive control on constrained systems with no nominal identified model. The proposed loop relaxes the modelling requirement to a fixed discrete-time state-space realisation of a first-order plus integrator plant despite the nature of the controlled process. A third-order discrete Extended State Observer (ESO) estimates the model mismatch and assumed plant states. Moreover, the constraints handling is tackled by incorporating the compensation term related to the total perturbation in the definition of the optimisation problem constraints. The proposal merges in a new way state-space Model Predictive Control (MPC) and Active Disturbance Rejection Control (ADRC) into an architecture suitable for the servo-regulatory operation of linear and non-linear systems, as shown through validation examples.
More Related Videos
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:10
Control Systems
At the heart...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
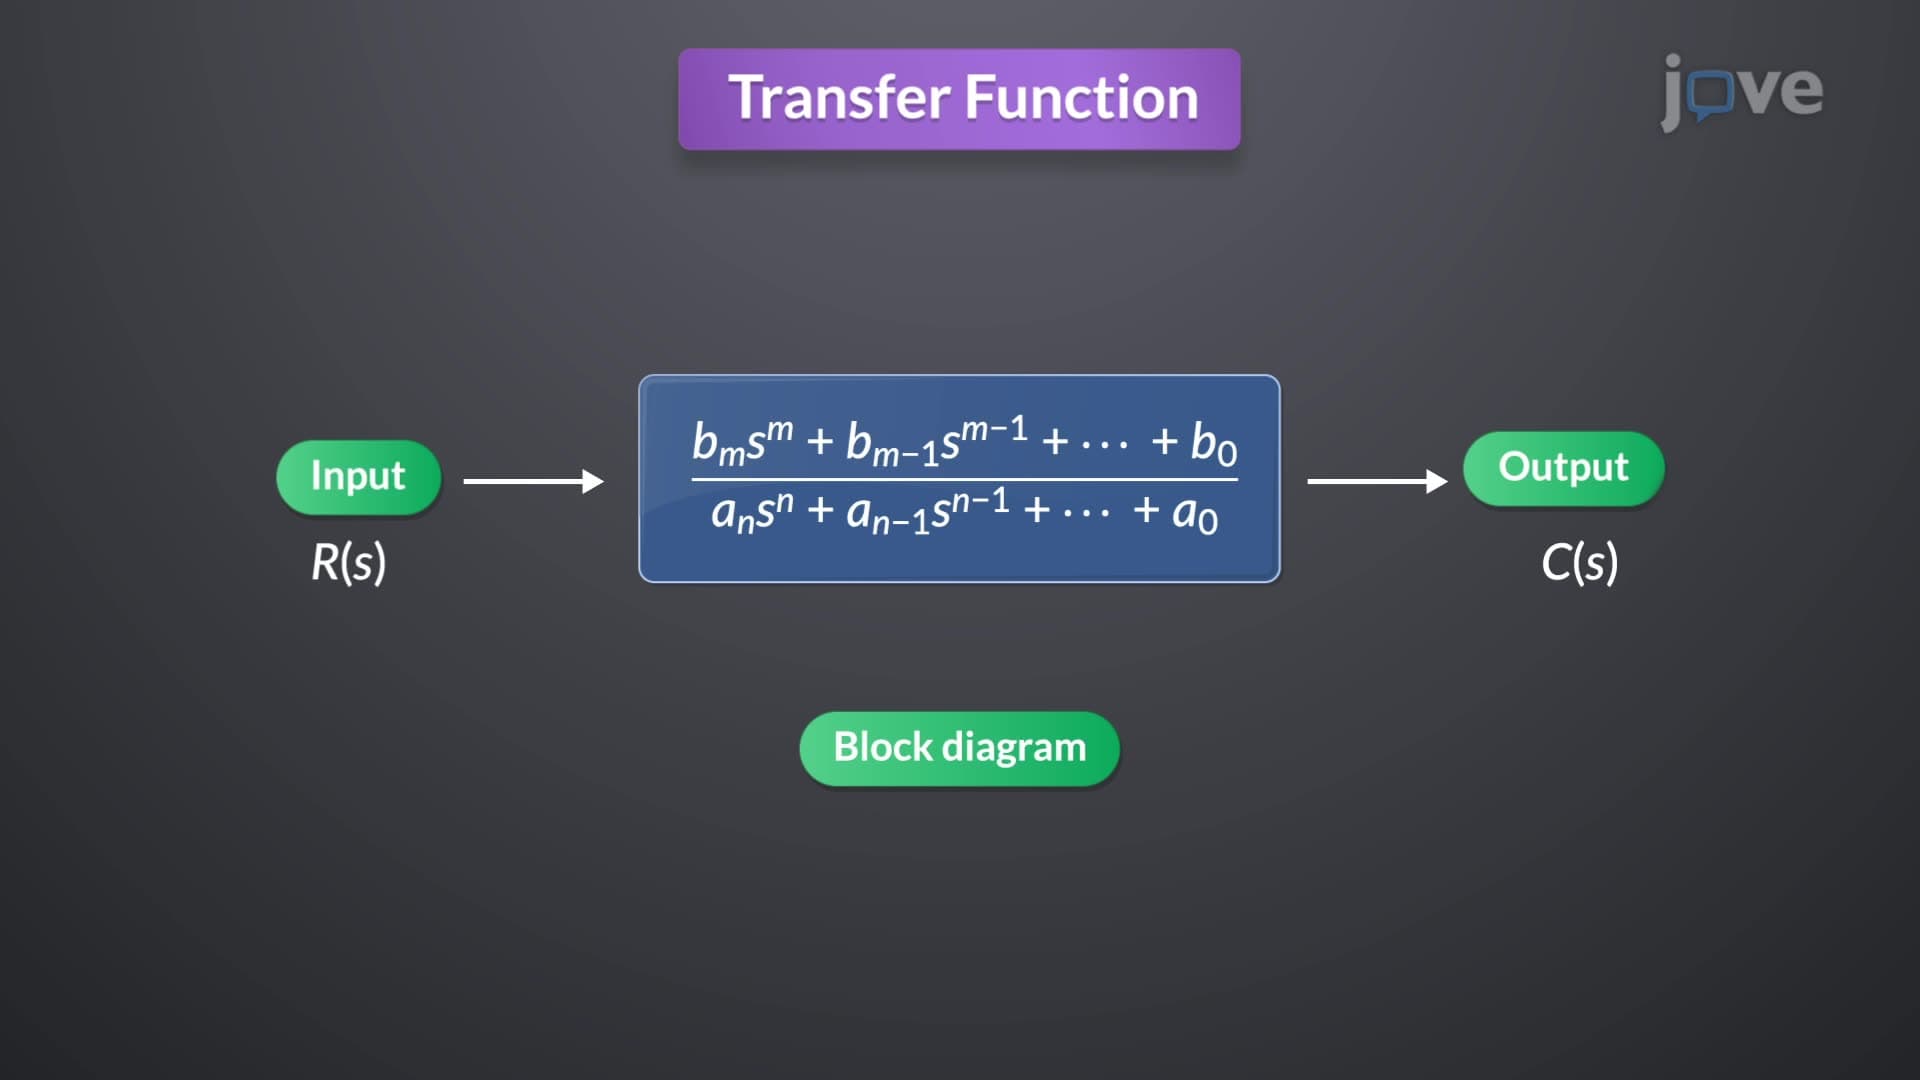
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...