Integrated thrust ripple identification and compensation for linear servo system using an MP algorithm

He Chang1, Shaowu Lu1, Shiqi Zheng2
1Engineering Research Center for Metallurgical Automation and Measurement Technology of Ministry of Education, Wuhan University of Science and Technology, Wuhan 430074, China.

Abstract:
Generally there are two methods for the thrust ripple modeling: one is to identify the eigenvalues and the model parameters of thrust ripple sequentially under rigorous operating conditions; another is to treat thrust ripple as a general and inaccurate disturbance. To get rid of the constraints and further enhance the tracking accuracy of the linear servo system, a novel integrated identification and compensation scheme using an improved matching pursuit algorithm is proposed in this paper. First, the dynamics of the linear motor is formulated, and the cause of thrust ripple is analyzed. Then, a time-frequency atomic library of thrust ripple is constructed with the consideration of the frequency characteristics of position command, and meanwhile, the two optimal atoms are obtained successively by maximizing the inner product for the thrust ripple reconstruction. Based on the above, the eigenvalues and model parameters of thrust ripple can be simultaneously identified in an online manner. Finally, the feedforward compensation component is devised by the identification results to suppress thrust ripple. In order to verify the superiority of the proposed scheme, simulations and experiments are conducted compared with the conventional methods.
More Related Videos
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
 09:04
A Modeling and Simulation Method for Preliminary Design of an Electro-Variable Displacement Pump
Published on: June 1, 2022
Related Concept Videos
 01:24
PI Controller: Design
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:13
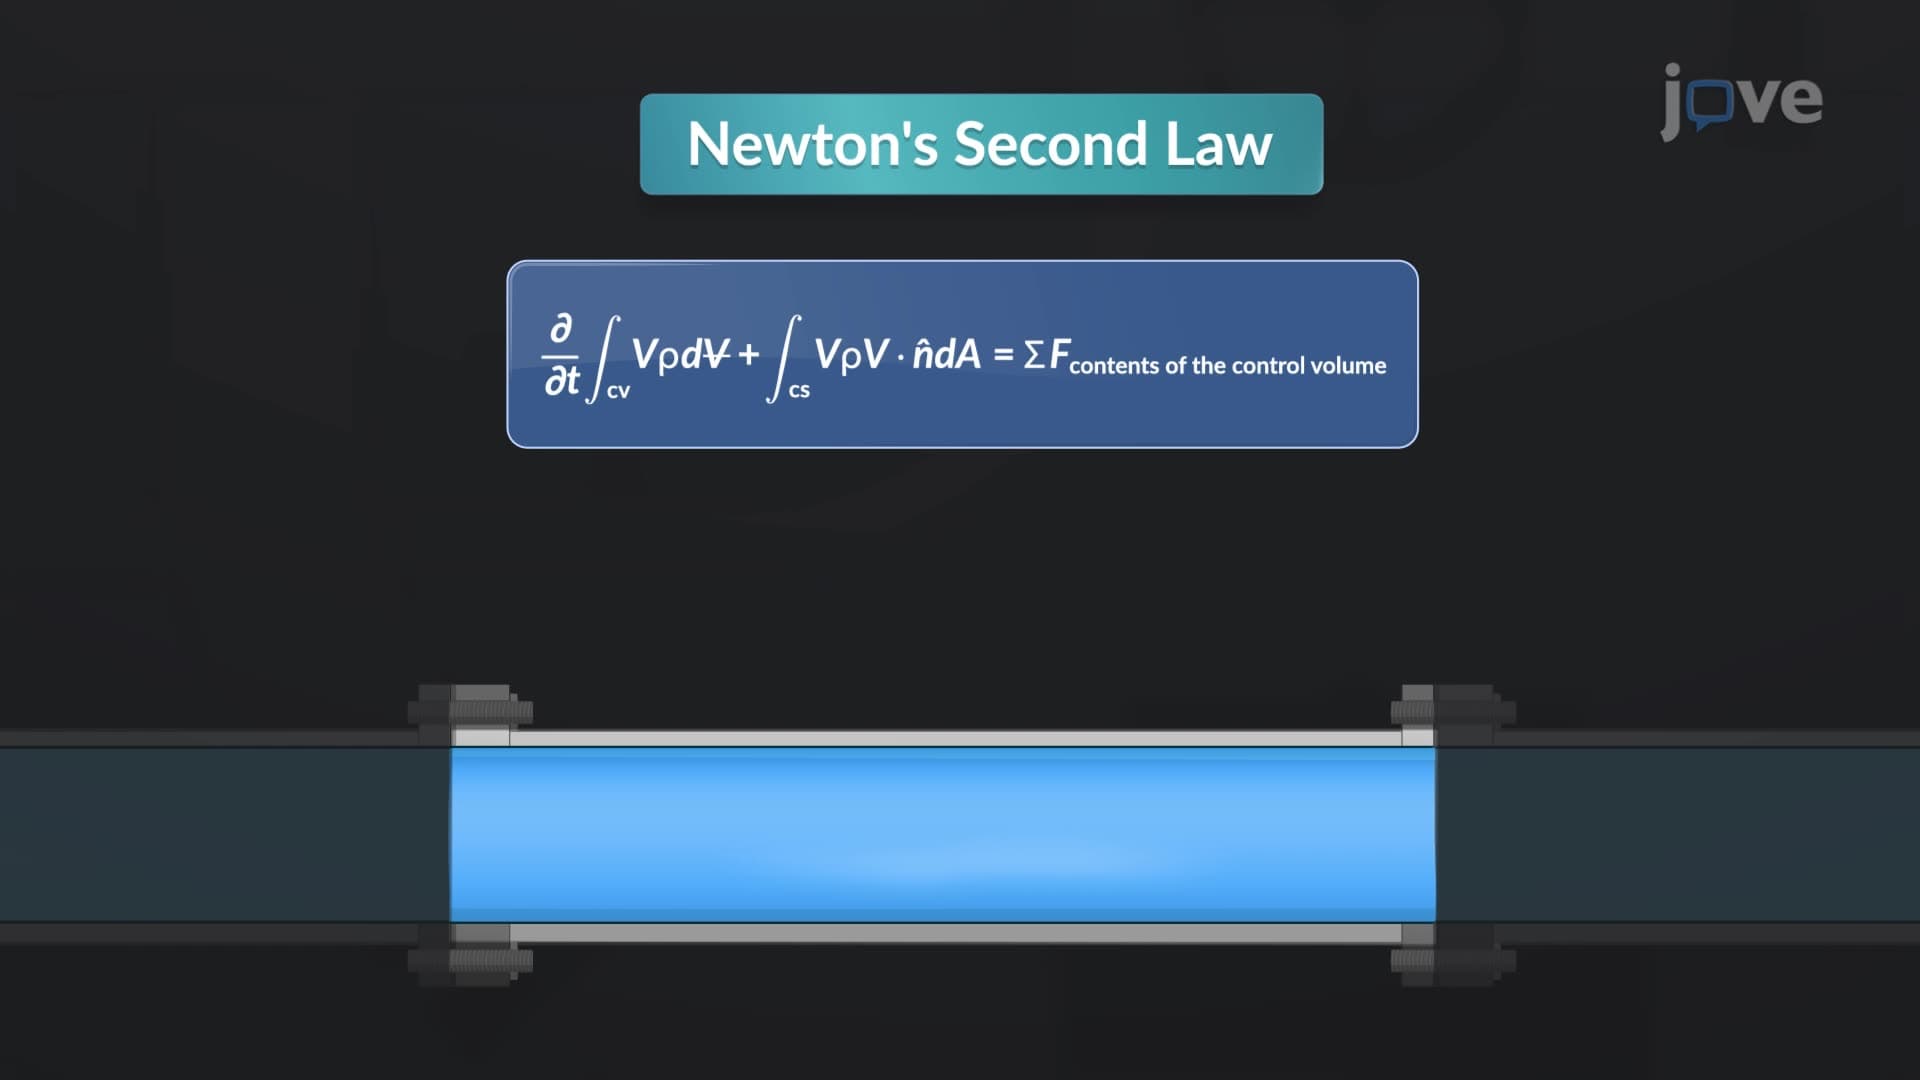
Linear Momentum in Control Volume
 01:19
PID Controller
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...