Related Experiment Video
Updated: Jul 13, 2025


Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
A Study on the Harmonic Distortion of Seismic-Grade Sigma-Delta MEMS Accelerometers Using a Multiple
Xuefeng Wang1, Penghao Zhang1, Shijin Ding1
1State Key Laboratory of ASIC and System, School of Microelectronics, Fudan University, Shanghai 200433, China.

Abstract:
Harmonic distortion is one of the dominant factors limiting the overall signal-to-noise and distortion ratio of seismic-grade sigma-delta MEMS accelerometers. This study investigates harmonic distortion based on the multiple degree-of-freedom model (MDM) established in our previous study. The main advantage of using an MDM is that the effect of finger flexibility on harmonic distortion is considered. Initially, the nonlinear relationship between the input acceleration and output signal is derived using the MDM. Then, harmonic distortion is simulated and described in terms of the nonlinear input-output relationship. It is found that finger flexibility and parasitic capacitance mismatch both decrease harmonic distortion. Finally, the experimental testing of harmonic distortion is implemented. By reducing the finger length to realize a higher stiffness and compensating for the parasitic capacitance mismatch, the total harmonic distortion decreases from -66.8 dB to -86.9 dB.
More Related Videos
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:17
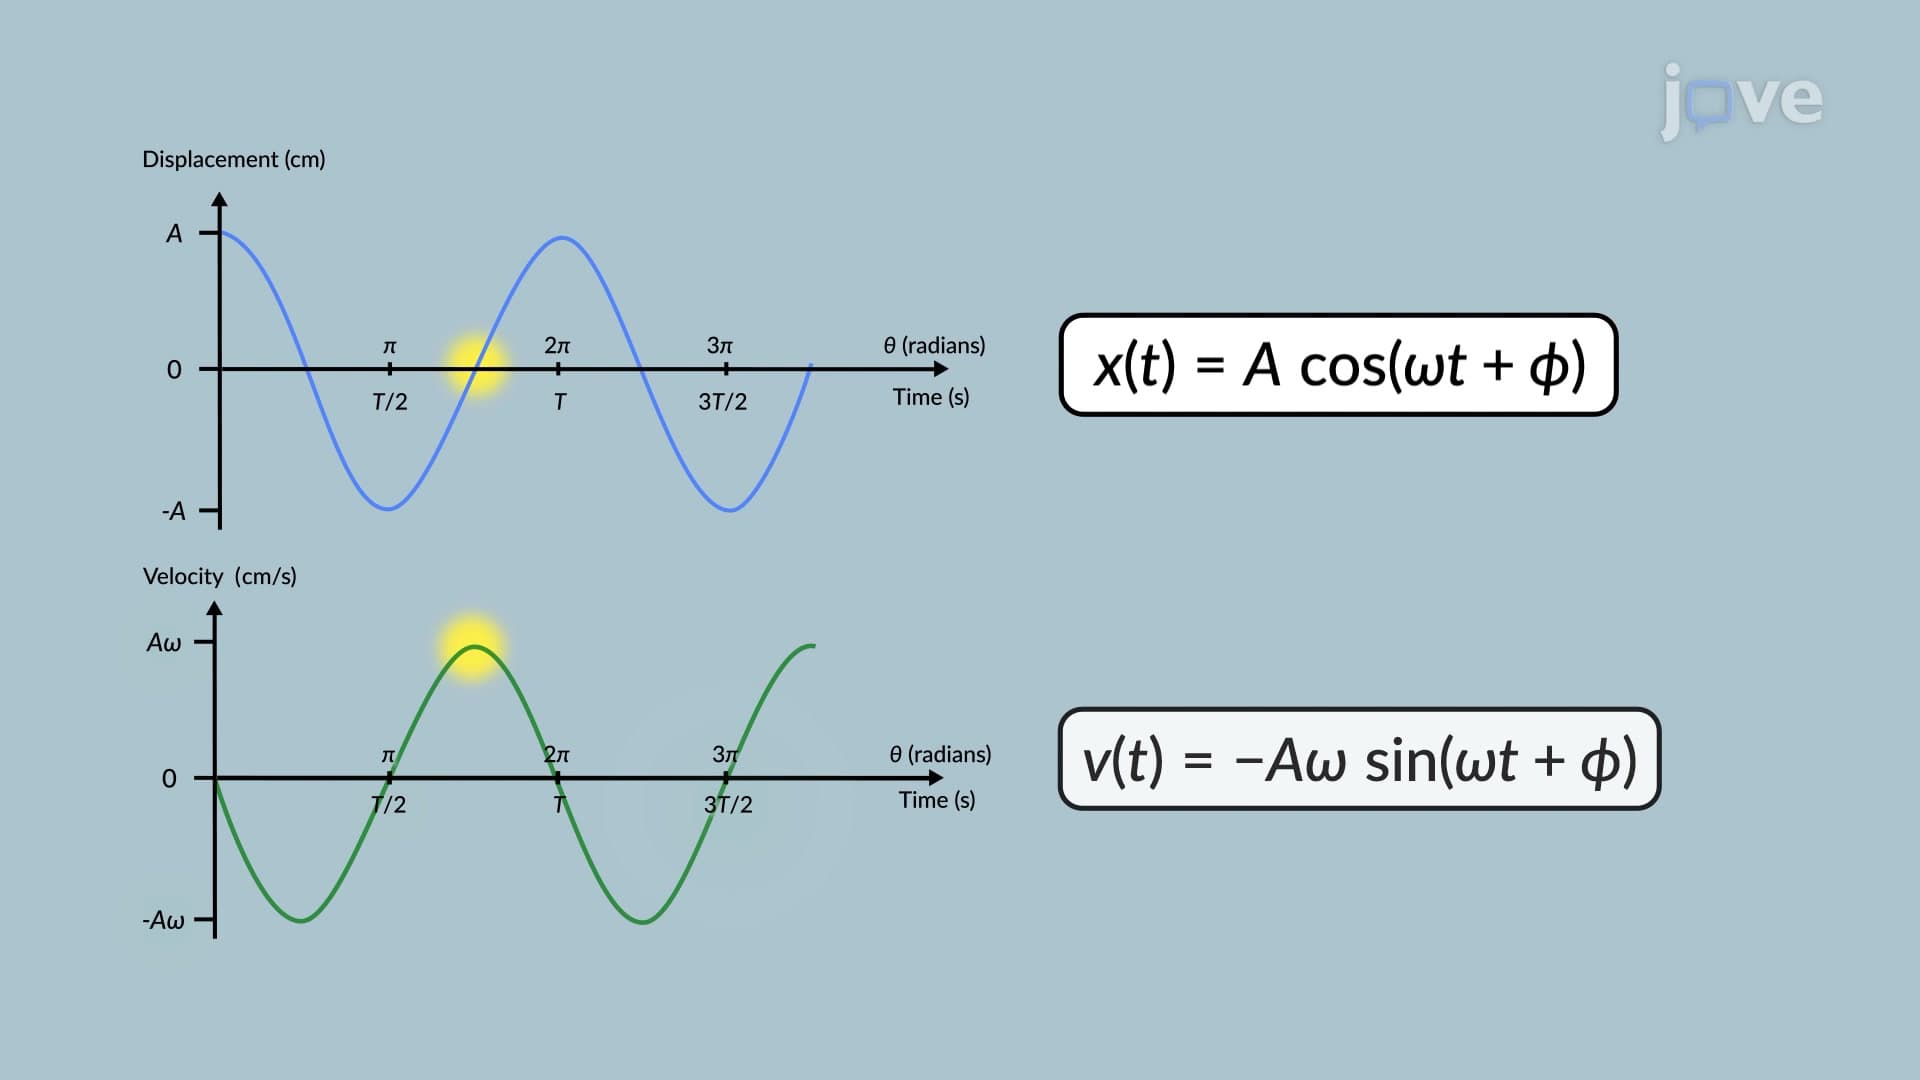
Characteristics of Simple Harmonic Motion
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...