Related Experiment Video
Updated: Jul 8, 2025
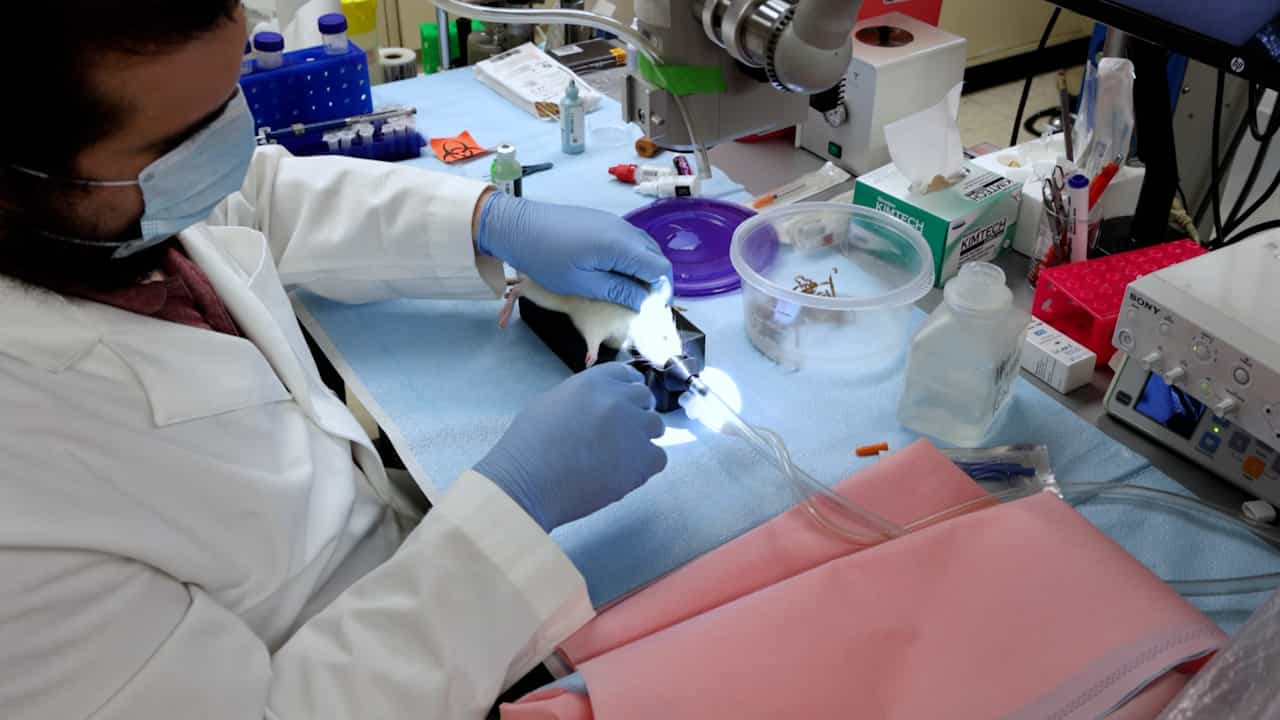

Ocular Therapeutic Delivery and Advanced Tissue Retrieval in Adult Rats
Published on: May 23, 2025
Autonomous Needle Navigation in Retinal Microsurgery: Evaluation in ex vivo Porcine Eyes
Peiyao Zhang1, Ji Woong Kim1, Peter Gehlbach2
1Department of Mechanical Engineering and the Laboratory for Computational Sensing and Robotics (LCSR), Johns Hopkins University, Baltimore, MD 21211, USA.

Abstract:
Important challenges in retinal microsurgery include prolonged operating time, inadequate force feedback, and poor depth perception due to a constrained top-down view of the surgery. The introduction of robot-assisted technology could potentially deal with such challenges and improve the surgeon's performance. Motivated by such challenges, this work develops a strategy for autonomous needle navigation in retinal microsurgery aiming to achieve precise manipulation, reduced end-to-end surgery time, and enhanced safety. This is accomplished through real-time geometry estimation and chance-constrained Model Predictive Control (MPC) resulting in high positional accuracy while keeping scleral forces within a safe level. The robotic system is validated using both open-sky and intact (with lens and partial vitreous removal) ex vivo porcine eyes. The experimental results demonstrate that the generation of safe control trajectories is robust to small motions associated with head drift. The mean navigation time and scleral force for MPC navigation experiments are 7.208 s and 11.97 mN, which can be considered efficient and well within acceptable safe limits. The resulting mean errors along lateral directions of the retina are below 0.06 mm, which is below the typical hand tremor amplitude in retinal microsurgery.
More Related Videos
 10:10
Ultrahigh Resolution Mouse Optical Coherence Tomography to Aid Intraocular Injection in Retinal Gene Therapy Research
Published on: November 2, 2018
 12:45
Development of a Refined Protocol for Trans-scleral Subretinal Transplantation of Human Retinal Pigment Epithelial Cells into Rat Eyes
Published on: August 12, 2017