Asynchronous sampled-data control for connected vehicles with heterogeneous delays
Related Experiment Video
Updated: Jul 6, 2025
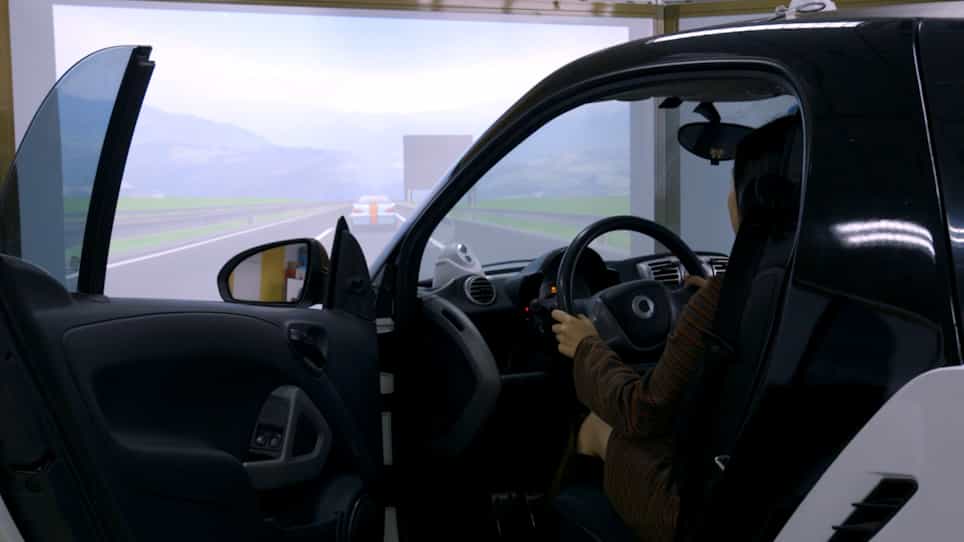
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
1School of Information and Engineering, Dalian University, Dalian, 116622, China; The Key Laboratory of Advanced Design and Intelligent Computing, Ministry of Education, Dalian University, Dalian, 116622, China.

Abstract:
This study investigates an asynchronous sampled-data control problem of vehicular platoons, with heterogeneous sampling, subjected to actuator delays. Without a synchronized clock, a completely asynchronous sampled-data controller is designed for each follower, where the state of the ith follower itself and its neighboring vehicles are sampled at their own sampling time instants. The caused closed-loop tracking error dynamics for the entire platoon considering the effect of the nonuniform sampling time intervals, heterogeneous vehicle dynamics, inter-vehicle topology and heterogeneous time delays. To simplify the stability analysis and controller design, the tracking-error dynamics of the entire platoon are decomposed into individual subsystems with reduced-order dynamics. Based on Lyapunov stability theory, the optimal conditions are explored to design an asynchronous sampled-data controller to guarantee the desired stability performance. Moreover, the exact values for the maximum allowable sampling interval and time delay are calculated for each follower using the designed feedback controller gain. The proposed asynchronous sampled-data control method is extended to a vehicular platoon using an event-based sampling scheme. Numerical examples are used to verify the effectiveness of the proposed sampled-data control method.


Related Concept Videos
 01:11
Sampling Continuous Time Signal
In the...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:22
Basic Continuous Time Signals
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...