Related Experiment Video
Updated: Jul 6, 2025


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Self-Constructing Chebyshev Fuzzy Neural Complementary Sliding Mode Control and its Application

Abstract:
In this article, a complementary sliding mode (CSM) controller using a self-constructing Chebyshev fuzzy recurrent neural network (SCCFRNN) is proposed for harmonic suppression control of an active power filter (APF). The SCCFRNN whose structure can be automatically learned through the designed structure self-learning algorithm is introduced to approximate the unknown nonlinear term in the APF dynamic model, so as to improve modeling accuracy and reduce the burden of CSM control (CSMC). The SCCFRNN combines the advantages of a fuzzy neural network (FNN), recurrent neural network (RNN), and Chebyshev neural network (CNN), and all parameters can be adjusted according to the designed adaptive laws. Eventually, through detailed simulation, hardware experiments, and fair comparison, the feasibility and superiority of the proposed control algorithm were verified.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:21
Transfer Function in Control Systems
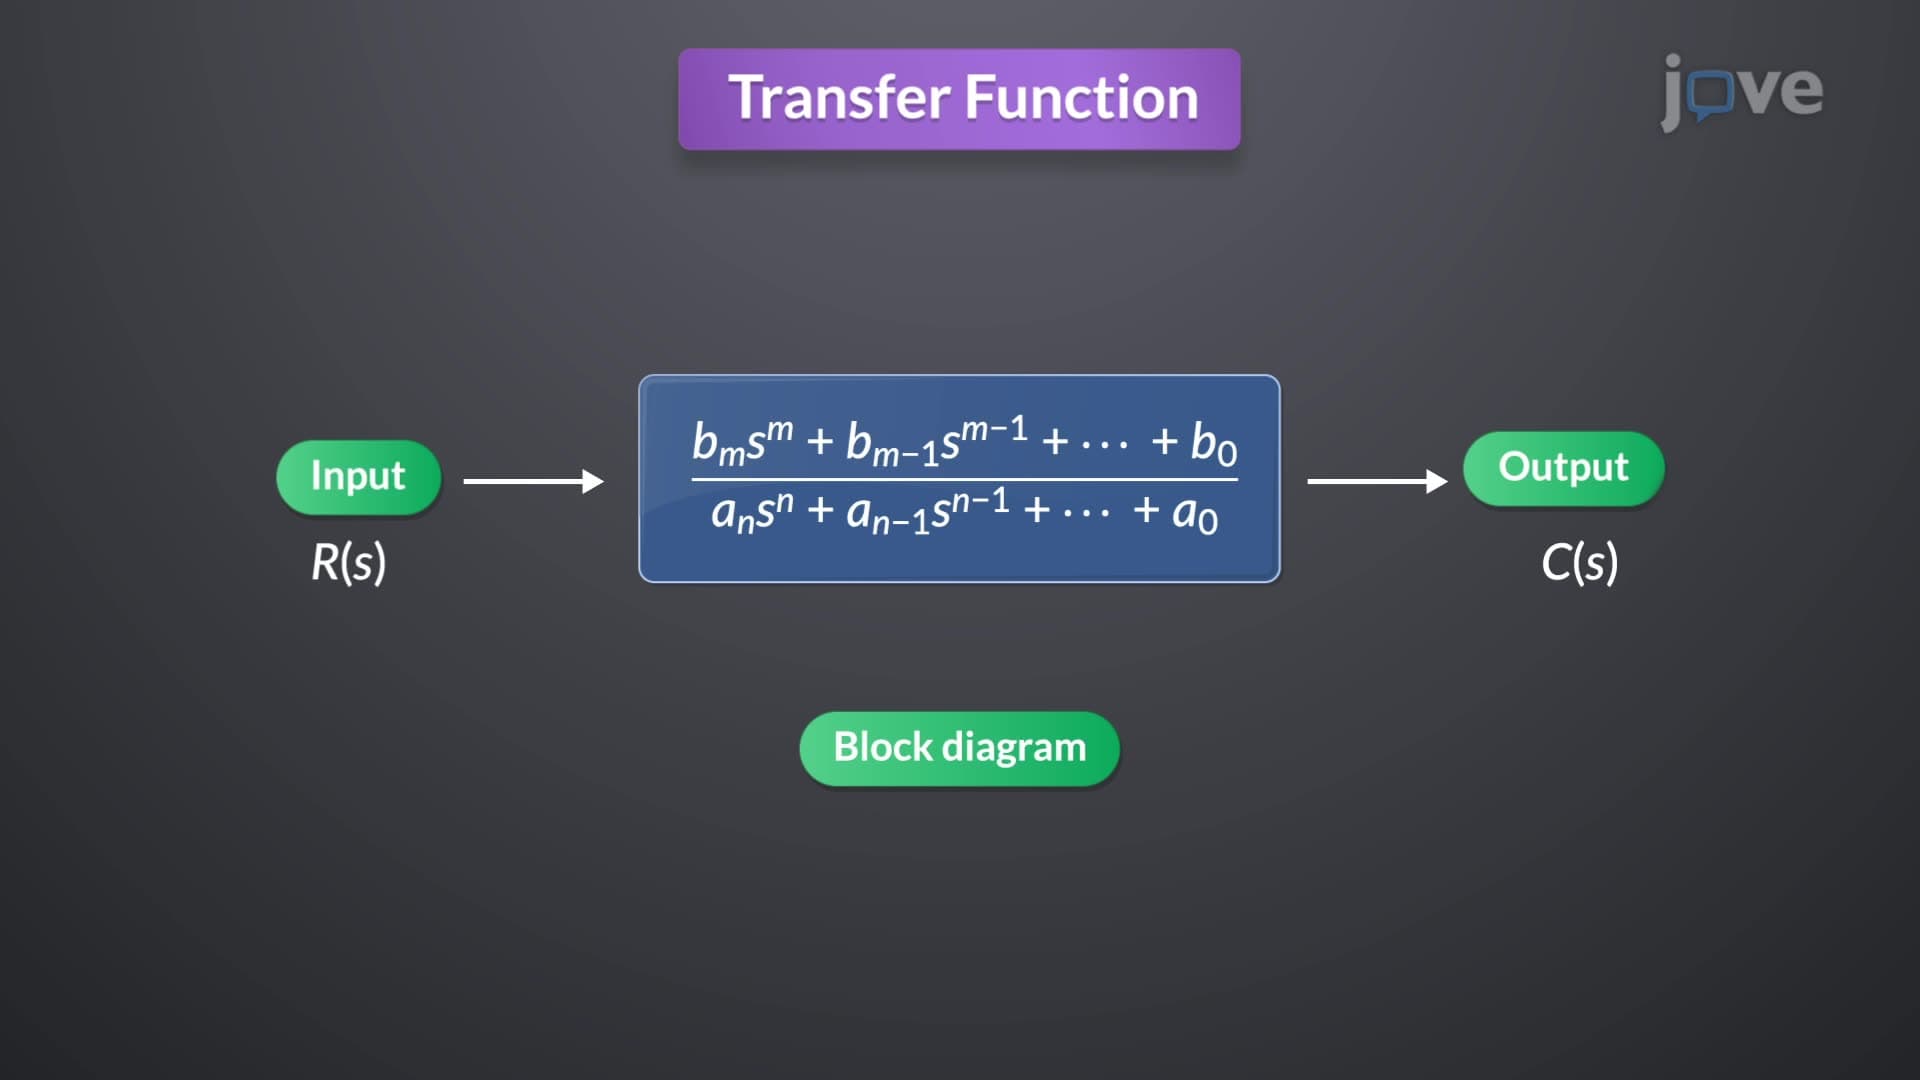
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:10
Control Systems
At the heart...