Related Experiment Video
Updated: May 6, 2026

Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
Published on: January 15, 2016
Optimization strategies to obtain smooth gait transitions through biologically plausible central pattern generators
V Baruzzi1, M Lodi1, M Storace1
1Department of Electrical, Electronics and Telecommunication Engineering and Naval Architecture, University of Genoa, 16145 Genoa, Italy.

Abstract:
Central pattern generators are small networks that contribute to generating animal locomotion. The models used to study gait generation and gait transition mechanisms often require biologically accurate neuron and synapse models, with high dimensionality and complex dynamics. Tuning the parameters of these models to elicit network dynamics compatible with gait features is not a trivial task, due to the impossibility of inferring a priori the effects of each parameter on the nonlinear system's emergent dynamics. In this paper we explore the use of global optimization strategies for parameter optimization in multigait central pattern generator (CPG) models with complex cell dynamics and minimal topology. We first consider an existing quadruped CPG model as a test bed for the objective function formulation, then proceed to optimize the parameters of a newly proposed multigait, interlimb hexapod CPG model. We successfully obtain hexapod gaits and prompt gait transitions by varying only control currents, while all CPG parameters, once optimized, are kept fixed. This mechanism of gait transitions is compatible with short-term synaptic plasticity.
More Related Videos
Related Concept Videos
 01:11
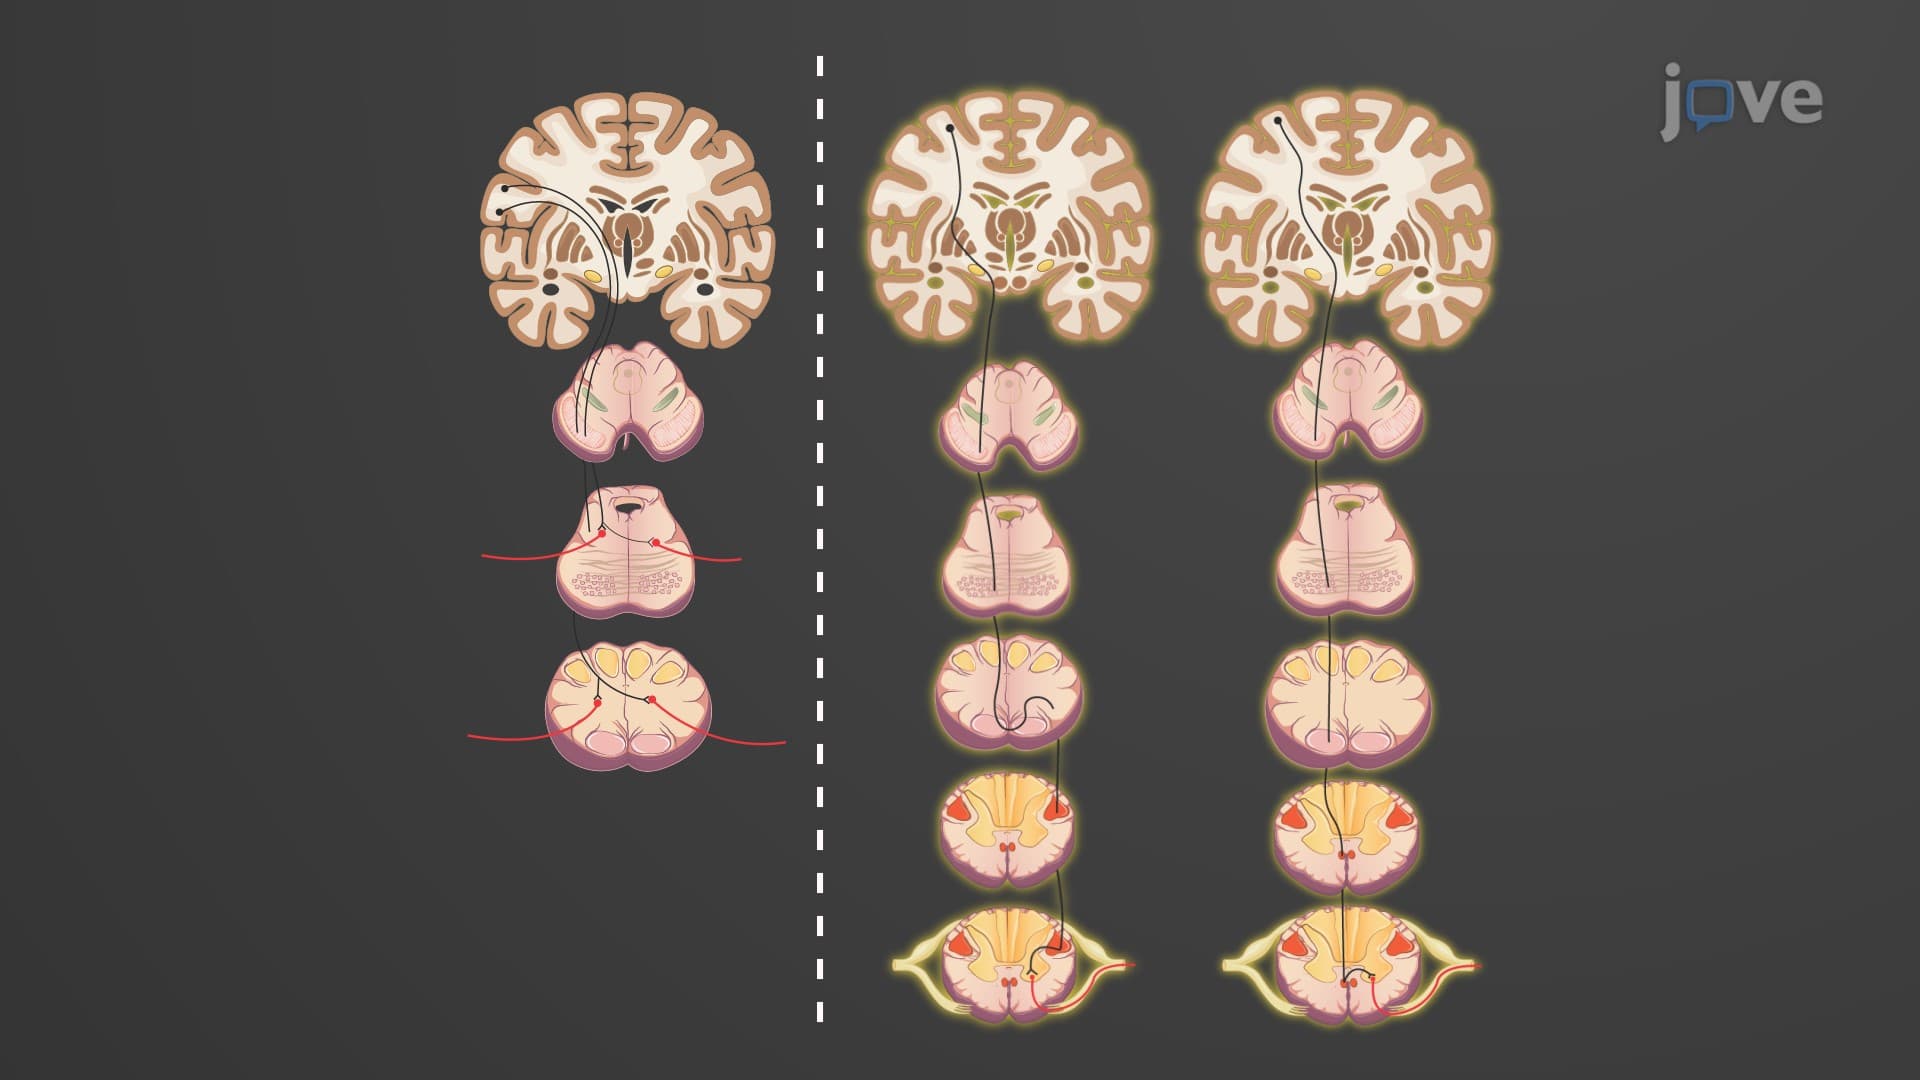
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...