Related Experiment Video
Updated: Jun 14, 2026
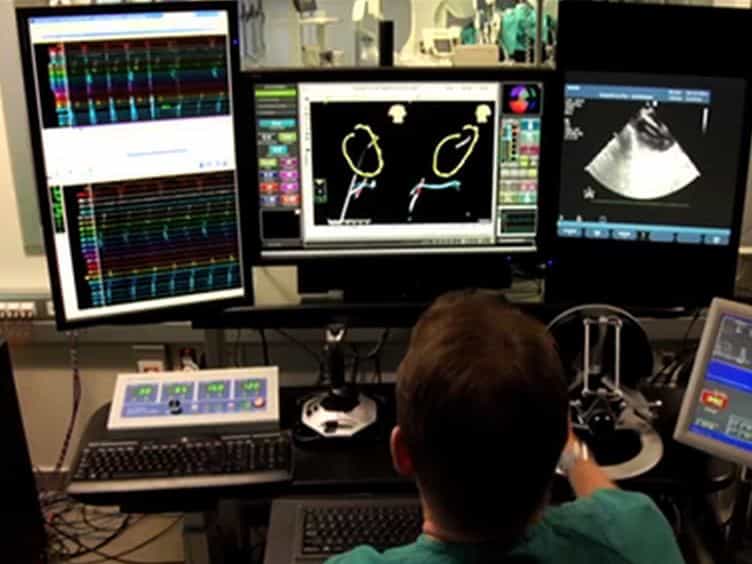

Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
Magnetic soft microfiberbots for robotic embolization
Xurui Liu1,2, Liu Wang3,4, Yuanzhuo Xiang2
1School of Integrated Circuits, Huazhong University of Science and Technology, Wuhan 430074, China.

Abstract:
Cerebral aneurysms and brain tumors are leading life-threatening diseases worldwide. By deliberately occluding the target lesion to reduce the blood supply, embolization has been widely used clinically to treat cerebral aneurysms and brain tumors. Conventional embolization is usually performed by threading a catheter through blood vessels to the target lesion, which is often limited by the poor steerability of the catheter in complex neurovascular networks, especially in submillimeter regions. Here, we propose magnetic soft microfiberbots with high steerability, reliable maneuverability, and multimodal shape reconfigurability to perform robotic embolization in submillimeter regions via a remote, untethered, and magnetically controllable manner. Magnetic soft microfiberbots were fabricated by thermal drawing magnetic soft composite into microfibers, followed by magnetizing and molding procedures to endow a helical magnetic polarity. By controlling magnetic fields, magnetic soft microfiberbots exhibit reversible elongated/aggregated shape morphing and helical propulsion in flow conditions, allowing for controllable navigation through complex vasculature and robotic embolization in submillimeter regions. We performed in vitro embolization of aneurysm and tumor in neurovascular phantoms and in vivo embolization of a rabbit femoral artery model under real-time fluoroscopy. These studies demonstrate the potential clinical value of our work, paving the way for a robotic embolization scheme in robotic settings.