Related Experiment Video
Updated: Jun 7, 2026
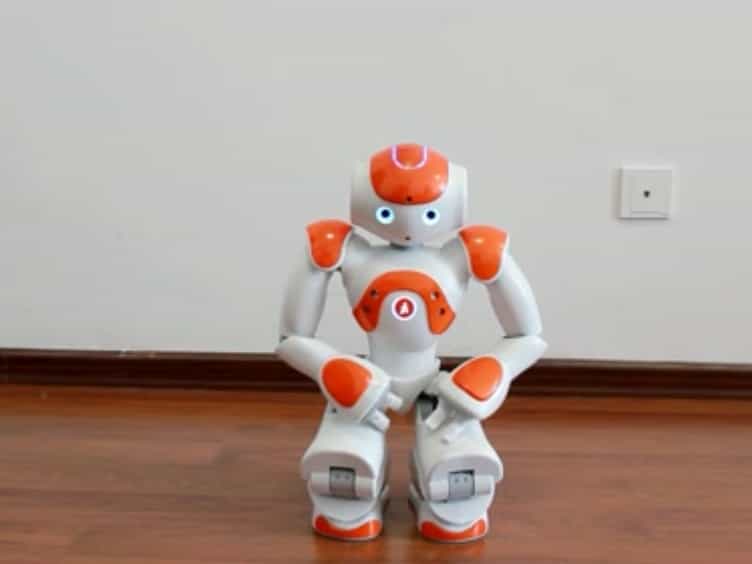
SSVEP-based Experimental Procedure for Brain-Robot Interaction with Humanoid Robots
Published on: November 24, 2015
Human-robot planar co-manipulation of extended objects: data-driven models and control from human-human dyads
Erich Mielke1, Eric Townsend1, David Wingate1
1Robotics and Dynamics Laboratory, Brigham Young University, Mechanical Engineering, Provo, UT, United States.

Abstract:
Human teams are able to easily perform collaborative manipulation tasks. However, simultaneously manipulating a large extended object for a robot and human is a difficult task due to the inherent ambiguity in the desired motion. Our approach in this paper is to leverage data from human-human dyad experiments to determine motion intent for a physical human-robot co-manipulation task. We do this by showing that the human-human dyad data exhibits distinct torque triggers for a lateral movement. As an alternative intent estimation method, we also develop a deep neural network based on motion data from human-human trials to predict future trajectories based on past object motion. We then show how force and motion data can be used to determine robot control in a human-robot dyad. Finally, we compare human-human dyad performance to the performance of two controllers that we developed for human-robot co-manipulation. We evaluate these controllers in three-degree-of-freedom planar motion where determining if the task involves rotation or translation is ambiguous.


Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...