Corr-Track: Category-Level 6D Pose Tracking with Soft-Correspondence Matrix Estimation
Related Experiment Video
Updated: Jul 1, 2025
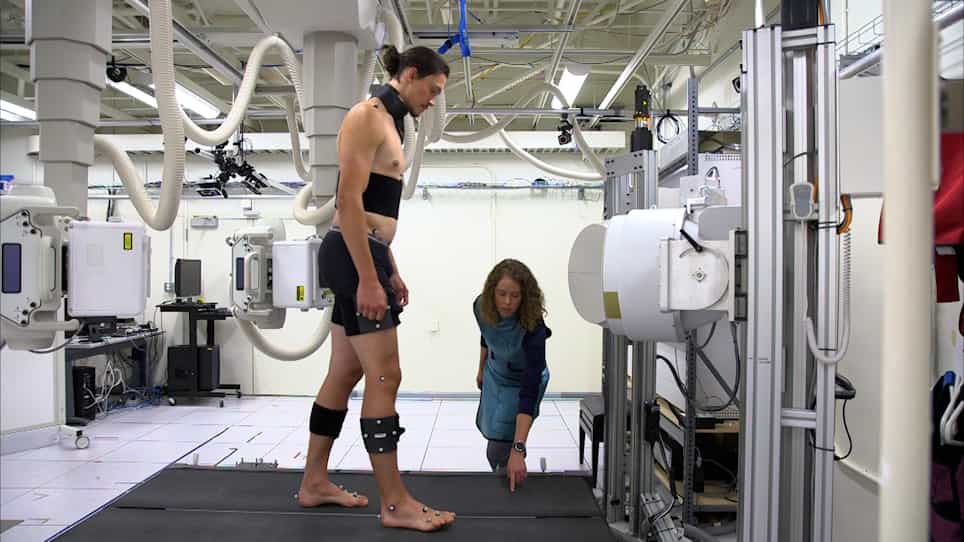
In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021

Abstract:
Category-level pose tracking methods can continuously track the pose of objects without requiring any prior knowledge of the specific shape of the tracked instance. This makes them advantageous in augmented reality and virtual reality applications. The key challenge is how to train neural networks to accurately predict the poses of objects they have never seen before and exhibit strong generalization performance. We propose a novel category-level 6D pose tracking method Corr-Track, which is capable of accurately tracking objects belonging to the same category from depth video streams. Our approach utilizes direct soft correspondence constraints to train a neural network, which estimates bidirectional soft correspondences between sparsely sampled point clouds of objects in two frames. We first introduce a soft correspondence matrix for pose tracking tasks and establish effective constraints through direct spatial point-to-point correspondence representations in the sparse point cloud correspondence matrix. We propose the "point cloud expansion" strategy to address the "point cloud shrinkage" problem resulting from soft correspondences. This strategy ensures that the corresponding point cloud accurately reproduces the shape of the target point cloud, leading to precise pose tracking results. We evaluated our approach on the NOCS-REAL275 and Wild6D dataset and observed superior performance compared to previous methods. Additionally, we conducted cross-category experiments that further demonstrated its generalization capability.

Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:10
Relative Motion Analysis - Acceleration