Related Experiment Video
Updated: Jun 29, 2025


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Exceeding traditional curvature limits of concentric tube robots through redundancy resolution
Patrick L Anderson1, Richard J Hendrick1, Margaret F Rox1
1Vanderbilt University, Department of Mechanical Engineering.

Abstract:
Understanding elastic instability has been a recent focus of concentric tube robot research. Modeling advances have enabled prediction of when instabilities will occur and produced metrics for the stability of the robot during use. In this paper, we show how these metrics can be used to resolve redundancy to avoid elastic instability, opening the door for the practical use of higher curvature designs than have previously been possible. We demonstrate the effectiveness of the approach using a three-tube robot that is stabilized by redundancy resolution when following trajectories that would otherwise result in elastic instabilities. We also show that it is stabilized when teleoperated in ways that otherwise produce elastic instabilities. Lastly, we show that the redundancy resolution framework presented here can be applied to other control objectives useful for surgical robots, such as maximizing or minimizing compliance in desired directions.


Related Concept Videos
 01:20
Plastic Deformation in Circular Shafts
 01:10
Deformation in a Circular Shaft
 01:16
Torsion of Noncircular Members
 01:13
Maximum Deflection
The maximum deflection occurs at a specific point, known as point O, where the tangent to the deflection curve is horizontal. To find point O, the slope of the tangent at any...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:18
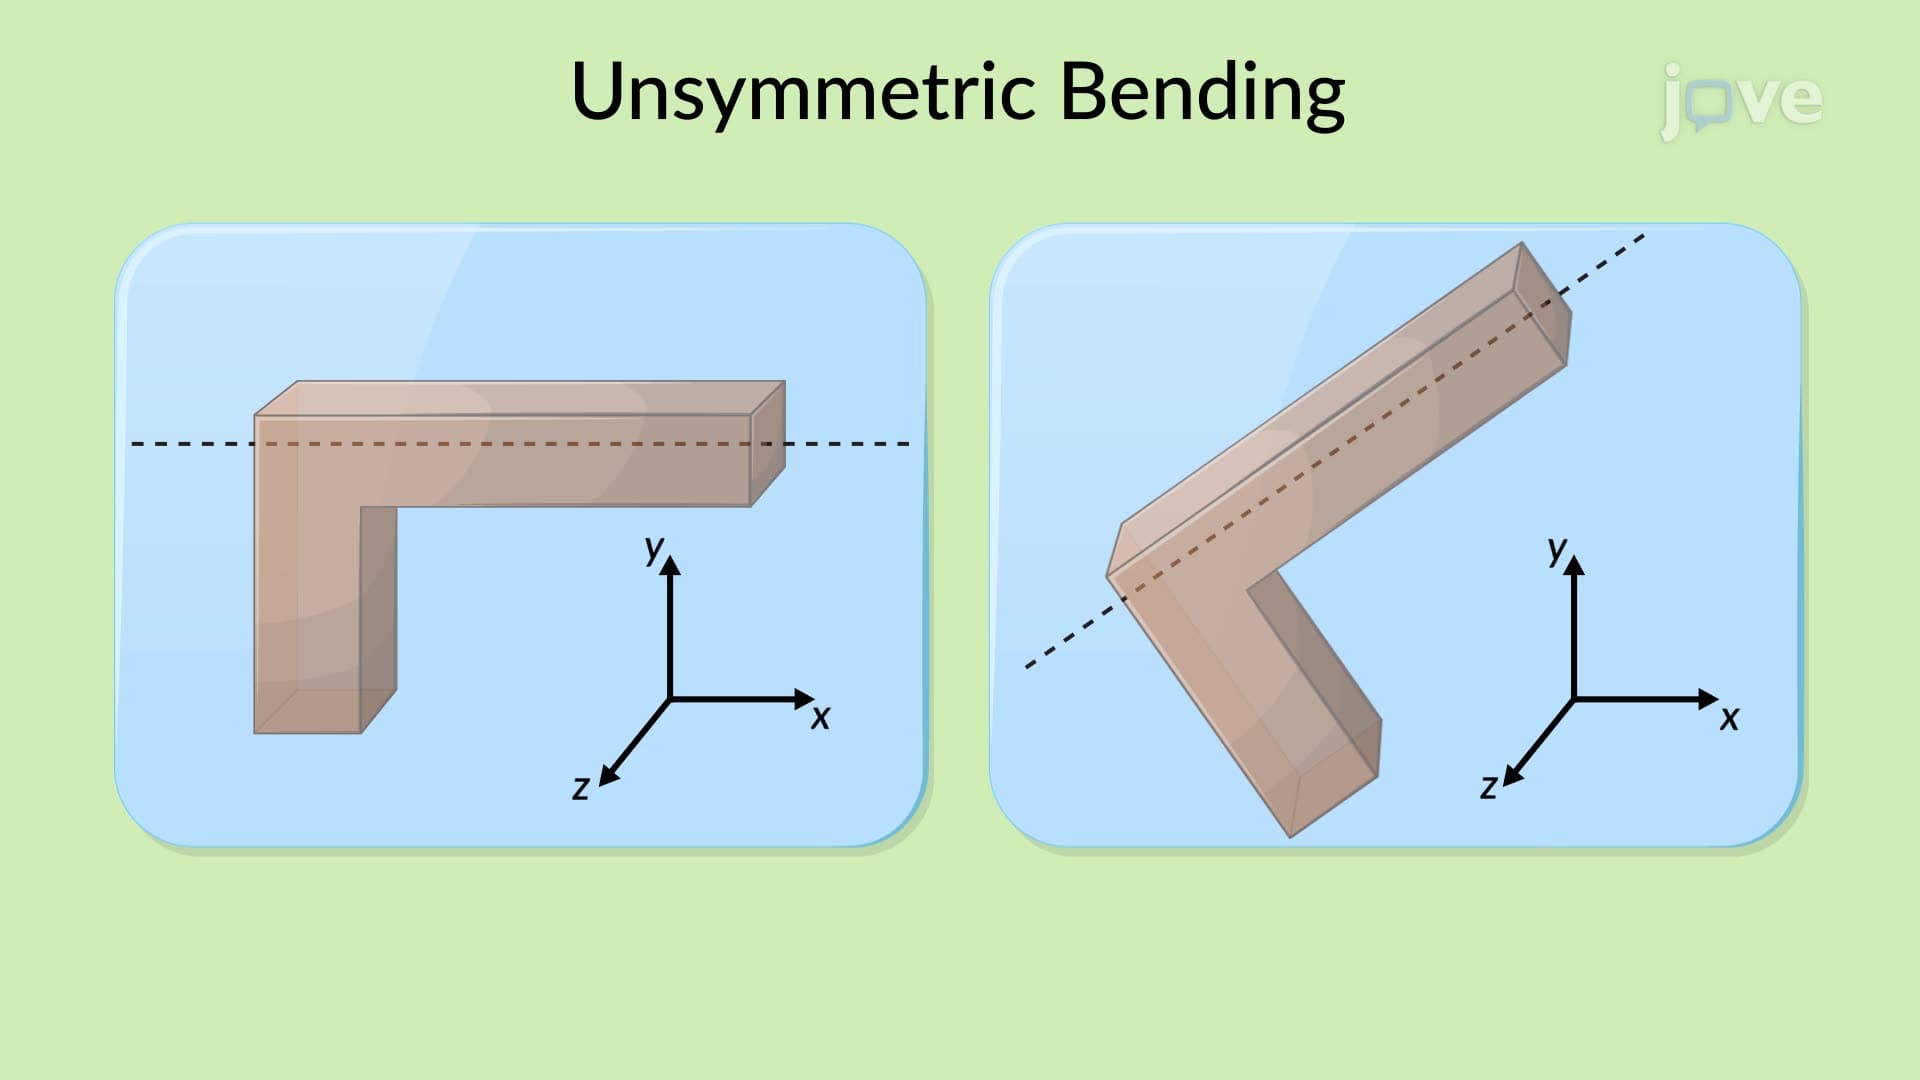
Unsymmetric Bending