Related Experiment Video
Updated: Jun 27, 2025


An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Continuous Bump Attractor Networks Require Explicit Error Coding for Gain Recalibration
Gorkem Secer1,2, James J Knierim2,3,4, Noah J Cowan1,5
1Laboratory for Computational Sensing and Robotics, Johns Hopkins University, Baltimore, MD 21218, USA.

Abstract:
Representations of continuous variables are crucial to create internal models of the external world. A prevailing model of how the brain maintains these representations is given by continuous bump attractor networks (CBANs) in a broad range of brain functions across different areas, such as spatial navigation in hippocampal/entorhinal circuits and working memory in prefrontal cortex. Through recurrent connections, a CBAN maintains a persistent activity bump, whose peak location can vary along a neural space, corresponding to different values of a continuous variable. To track the value of a continuous variable changing over time, a CBAN updates the location of its activity bump based on inputs that encode the changes in the continuous variable (e.g., movement velocity in the case of spatial navigation)-a process akin to mathematical integration. This integration process is not perfect and accumulates error over time. For error correction, CBANs can use additional inputs providing ground-truth information about the continuous variable's correct value (e.g., visual landmarks for spatial navigation). These inputs enable the network dynamics to automatically correct any representation error. Recent experimental work on hippocampal place cells has shown that, beyond correcting errors, ground-truth inputs also fine-tune the gain of the integration process, a crucial factor that links the change in the continuous variable to the updating of the activity bump's location. However, existing CBAN models lack this plasticity, offering no insights into the neural mechanisms and representations involved in the recalibration of the integration gain. In this paper, we explore this gap by using a ring attractor network, a specific type of CBAN, to model the experimental conditions that demonstrated gain recalibration in hippocampal place cells. Our analysis reveals the necessary conditions for neural mechanisms behind gain recalibration within a CBAN. Unlike error correction, which occurs through network dynamics based on ground-truth inputs, gain recalibration requires an additional neural signal that explicitly encodes the error in the network's representation via a rate code. Finally, we propose a modified ring attractor network as an example CBAN model that verifies our theoretical findings. Combining an error-rate code with Hebbian synaptic plasticity, this model achieves recalibration of integration gain in a CBAN, ensuring accurate representation for continuous variables.
More Related Videos
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Related Concept Videos
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:28
Load-frequency control
 01:24
PI Controller: Design
 01:19
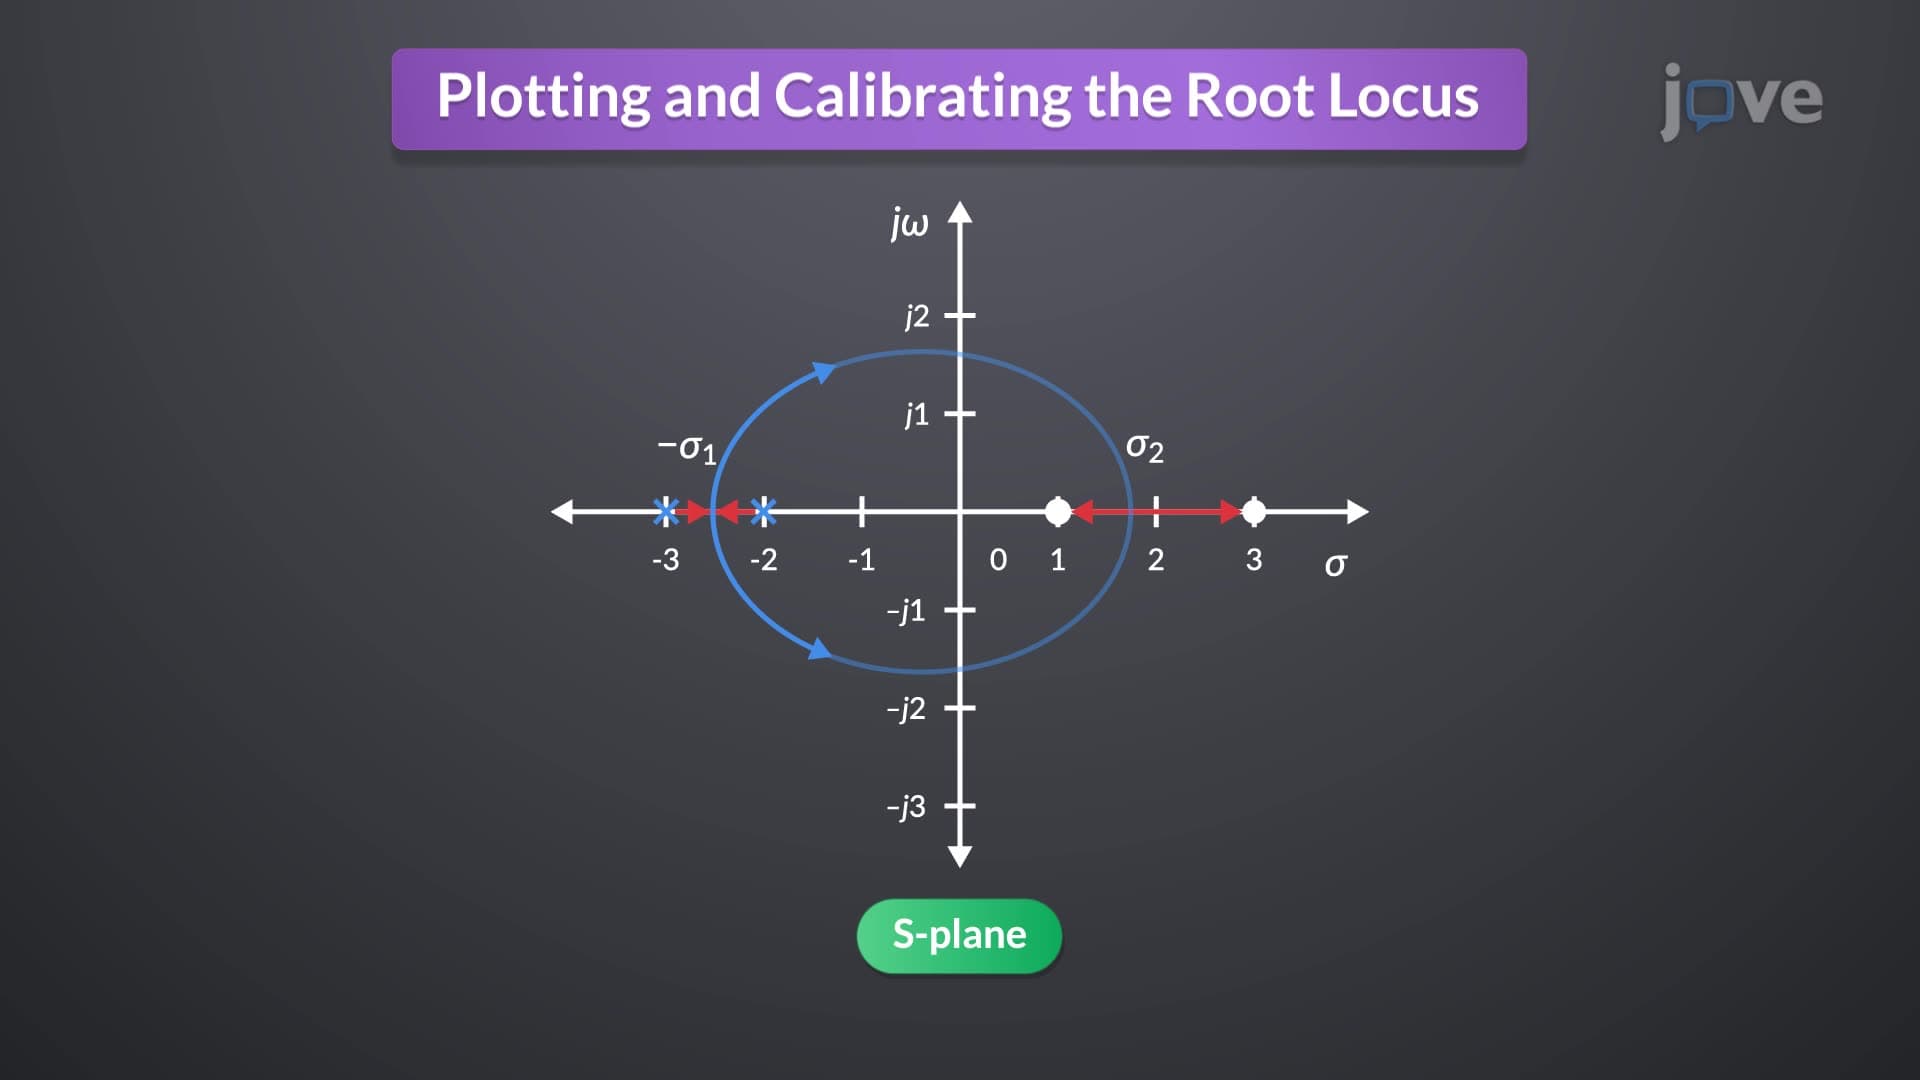
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...