Related Experiment Video
Updated: Jun 26, 2025
Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
RBF neural network disturbance observer-based backstepping boundary vibration control for Euler-Bernoulli beam model
Jiaqi Zhong1, Jing Zhang1, Xiaolei Chen1
1School of Automation, Chongqing University of Posts and Telecommunications, Chongqing 400065, China.

Abstract:
The main objective of this paper is to address the issue of vibration control for a class of Euler-Bernoulli beam systems that are subject to external disturbances and input saturation. The proposed controller differs from other backstepping methods in that it employs a radial basis function (RBF) neural network to accurately estimate boundary disturbances and incorporates the hyperbolic tangent function to ensure input constraints. The nonlinear partial differential equation (PDE) model is initially derived based on Hamilton's principle to capture the dominant dynamic characteristics of the flexible beam. In the framework of the Lyapunov direct approach, an adaptive RBF neural network-based law is subsequently designed to estimate the state-related boundary disturbances. The backstepping approach is then developed to propose sufficient conditions for ensuring the stability and convergence of closed-loop systems subject to input saturation. Finally, the effectiveness and superiority of the proposed methodology are further demonstrated by comparing the simulation results of constrained backstepping controllers.
More Related Videos
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:17
Beams with Unsymmetric Loadings
The first moment-area theorem determines the slope at any point on the beam. This theorem indicates that the change in slope between two points on a beam...
 01:15
Beams with Symmetric Loadings
The M/EI...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I
 01:15
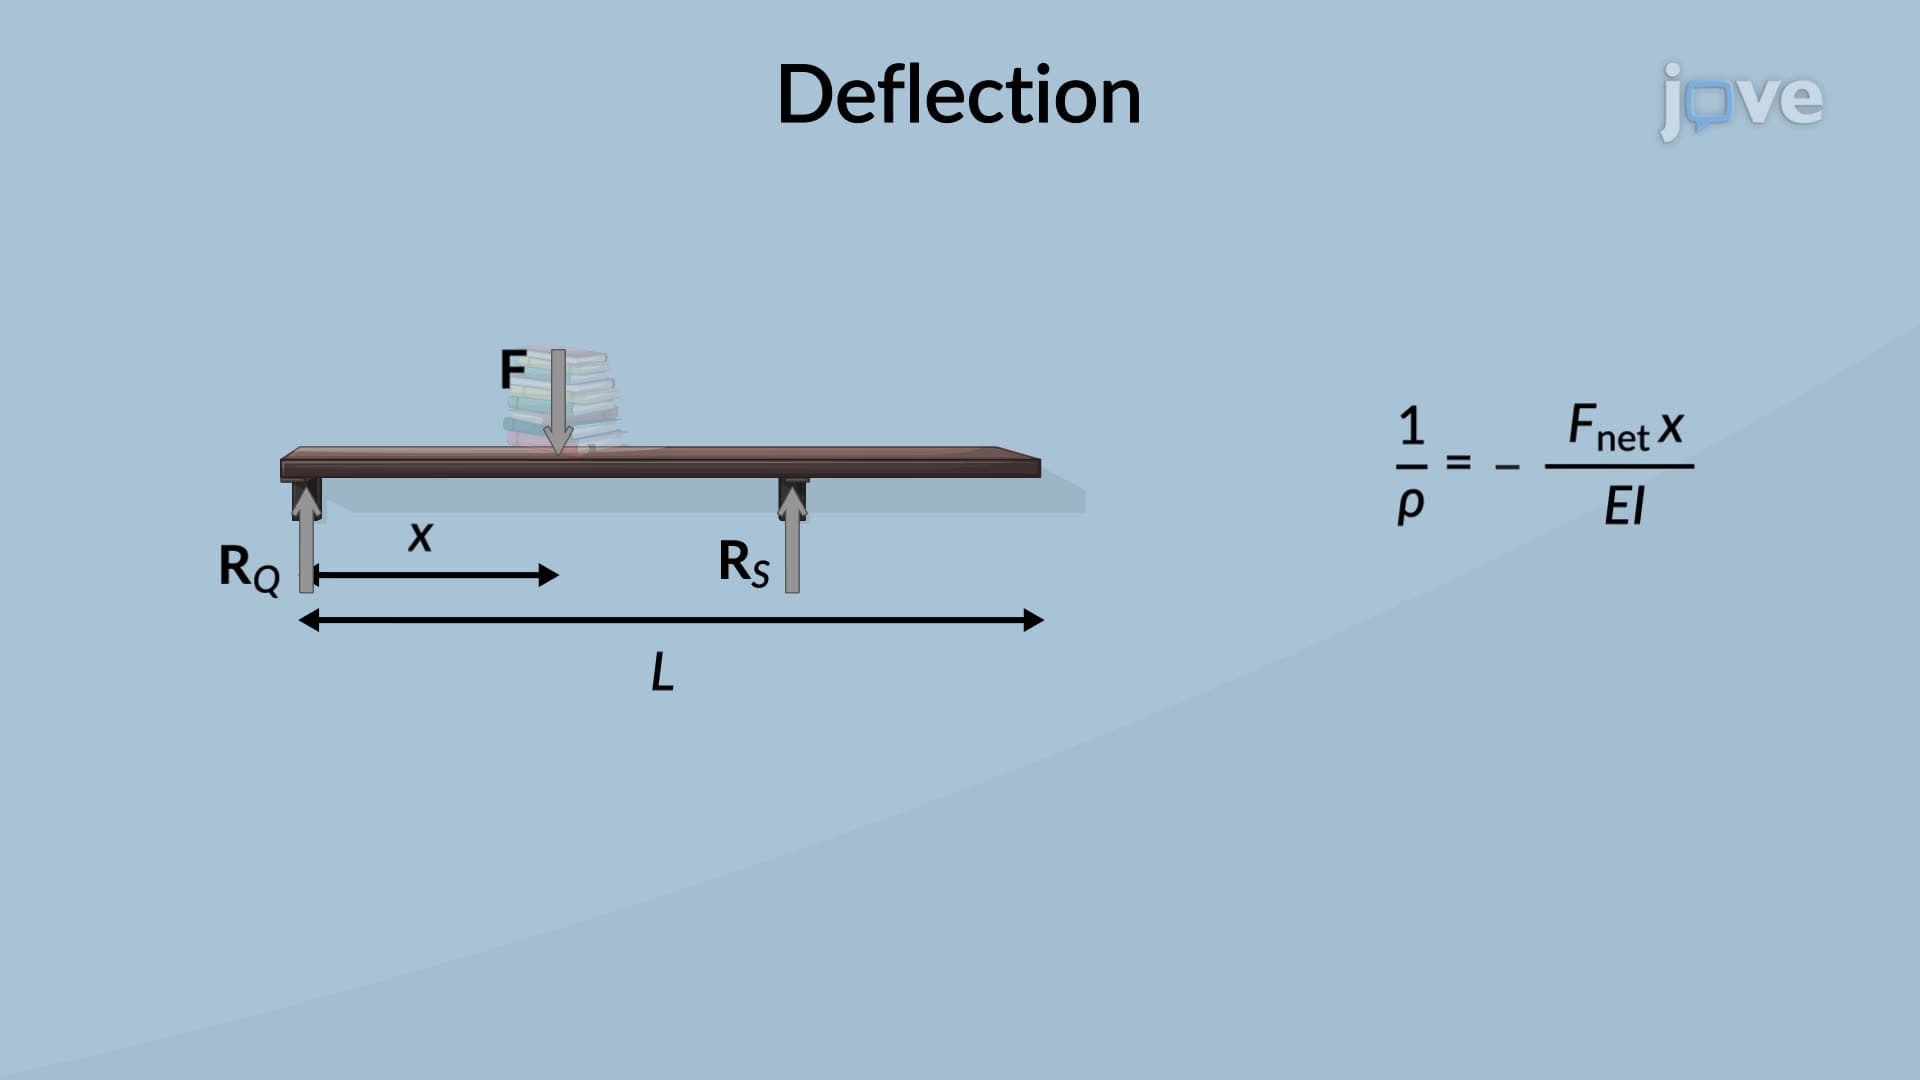
Deformation of a Beam under Transverse Loading
The insights from the bending moment diagram extend to...
 01:14
Shearing Stresses in a Beam: Problem Solving