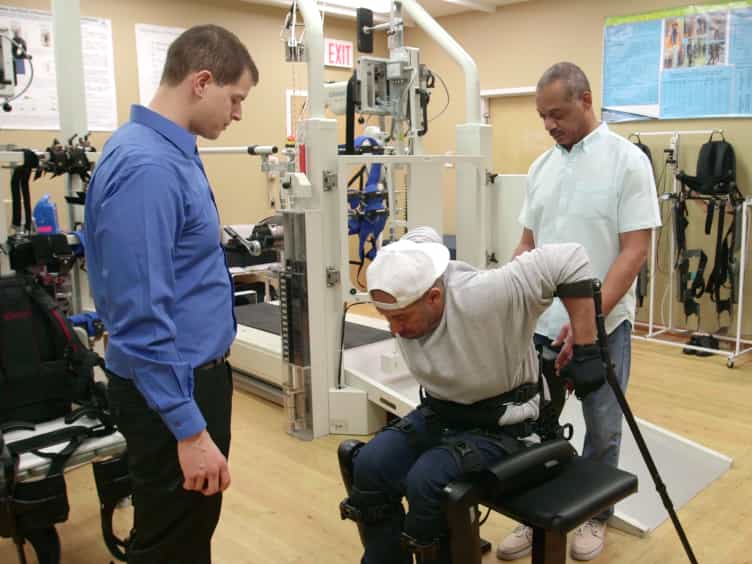
Related Experiment Video
Updated: Jun 24, 2025
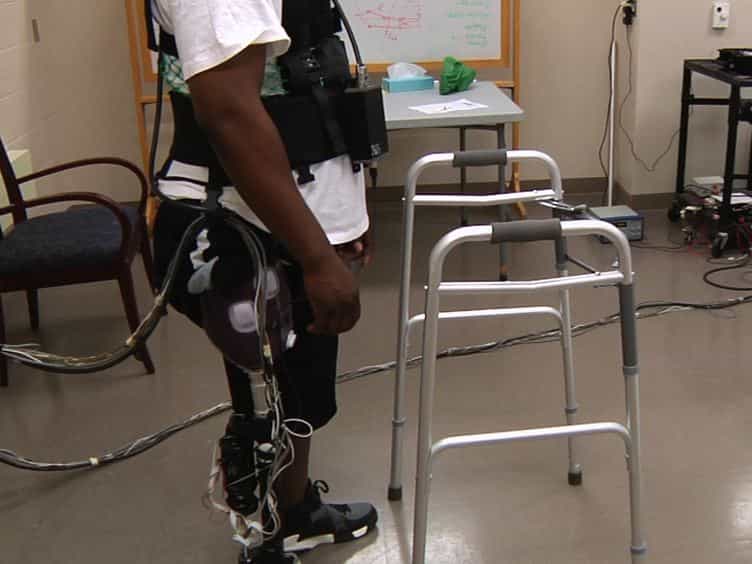
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Adaptive neural fault-tolerant prescribed performance control of a rehabilitation exoskeleton for lower limb passive
Yong Yang1, Deqing Huang2, Lei Ma2
1School of Electrical Engineering and Electronic Information, Xihua University, Chengdu, 610039, China.

Abstract:
This article studies the passive tracking problem of a wearable exoskeleton for lower limb rehabilitation therapy in the face of unmodeled dynamics, interactive friction, disturbance, prescribed performance constraints, and actuator faults. Adaptive neural networks and a smooth performance function are incorporated to establish a novel fault-tolerant tracking scheme, which can not only compensate for the nonlinear uncertainties and disturbance, but also handle the actuator fault with guaranteed tracking performance. A state feedback controller is presented by using the full state information and an output feedback controller is developed when the angular velocity is unavailable. The differential explosion issue of the backstepping technique is resolved by constructing a first-order filter and the unmeasurable velocity is estimated by a nonlinear observer. Semiglobal uniform boundedness stabilities of the exoskeleton system are proved via the Lyapunov direct method. The tracking performances of the designed control approaches are tested by comparative simulations.